
Aerodynamic Vector Autorotation Demo
Loading the math board and drawing, please wait…
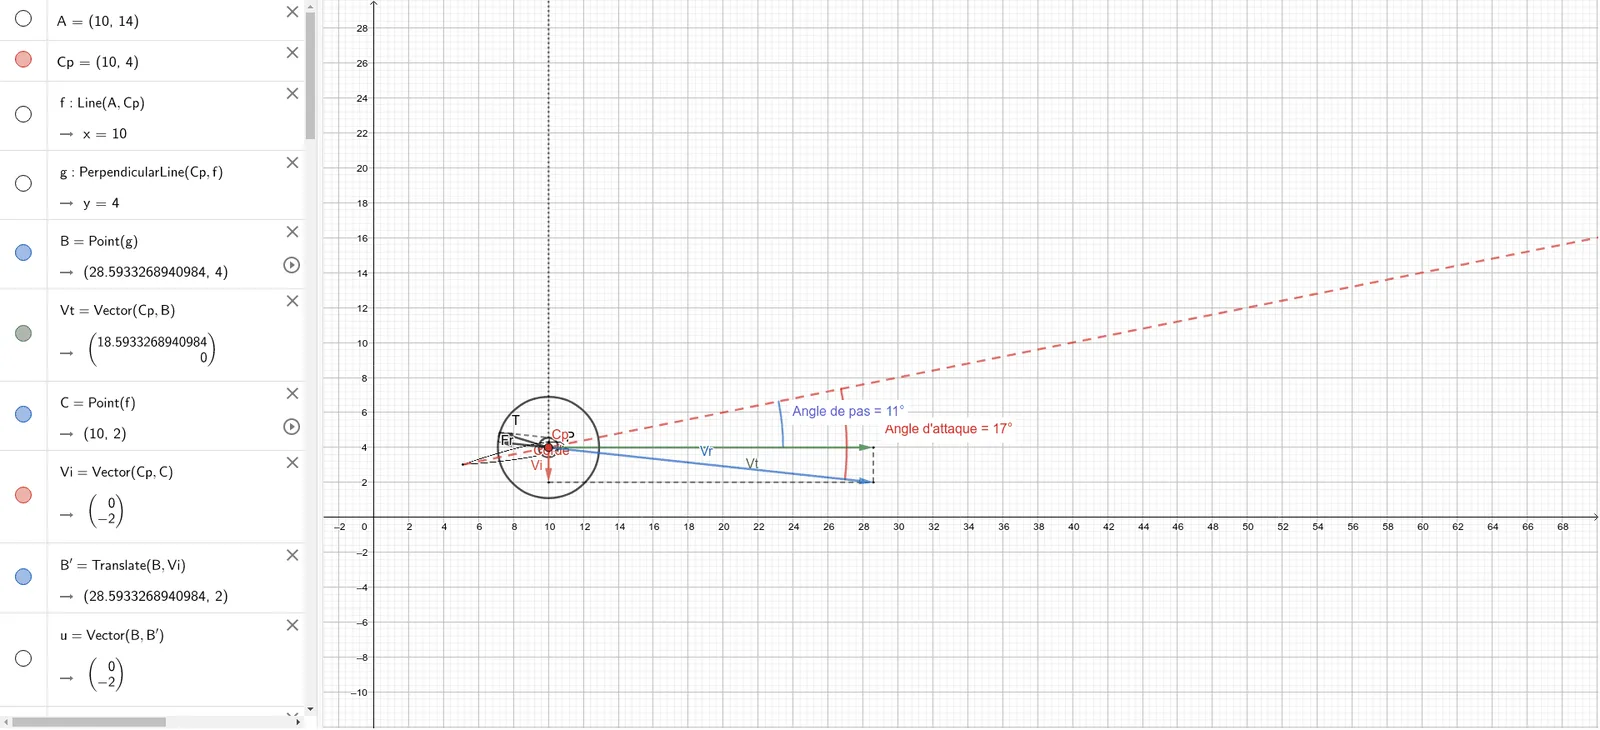
This example demonstrates the autorotation phenomenon of aerodynamic vectors under specific conditions, showcasing dynamic equilibrium. Key math concepts include vector operations, symmetry, equilateral triangle construction, coordinate geometry, and geometric transformations. Construction highlights from the summary involve commands like Line, Vector, Translate, and Circle. Suitable for high school students and researchers focusing on aerodynamics and geometric integration.
GeoGebra Commands & Parameters
Line(A, Cp) → fOrthogonalLine(Cp, f) → gPoint(g) → BVector(Cp, B) → VtPoint(f) → CVector(Cp, C) → ViTranslate(B, Vi) → B'Vector(B, B') → uSegment(C, B') → hSegment(B', B) → iVector(Cp, B') → VrPoint(Circle[Cp, 5]) → PasSegment(Cp, Pas) → jRay(Pas, Cp) → CordeOrthogonalLine(Pas, Corde) → kPoint(Corde) → DOrthogonalLine(D, Corde) → lPoint(k) → ELine(E, Corde) → mIntersect(l, m) → FPoint(Vr) → IPoint(Corde) → JCircleArc(Cp, I, J) → cPoint(Vt) → KPoint(Corde) → LCircleArc(Cp, K, L) → dLength(c) → aPointIn(c) → PointcLength(d) → bPointIn(d) → PointdAngle(K, Cp, L) → αAngle(I, Cp, J) → βLine(Cp, Vr) → nDistance(Cp, n) → distanceCpnOrthogonalLine(Cp, n) → qPoint(f) → OOrthogonalLine(Cp, n) → tCircle(Cp, ((CircleArc[Cp, I, J] * CircleArc[Cp, I, J]) * (Length[Vr] - Length[Vt]))) → eIntersect(e, n, 1) → GOrthogonalLine(G, n) → pVector(Cp, G) → TCircle(Cp, (CircleArc[Cp, I, J] * (Length[Vr] - Length[Vt]))) → rOrthogonalLine(Cp, n) → sIntersect(r, s, 2) → HVector(Cp, H) → POrthogonalLine(H, p) → g_1Intersect(p, g_1) → MVector(Cp, M) → FrSegment(M, H) → h_1Segment(M, G) → i_1Ray(Cp, A) → f_1