
3D Conic Sections: Dandelin Spheres
Loading the math board and drawing, please wait…
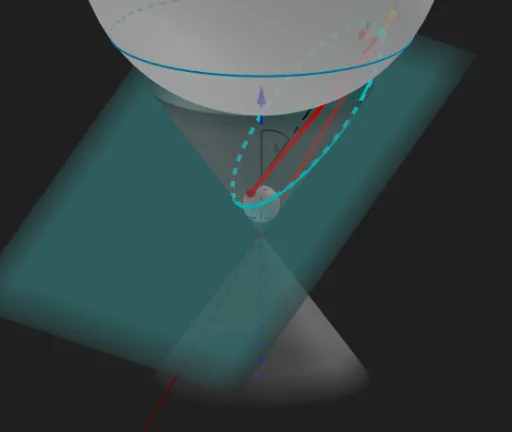
① This GeoGebra example demonstrates conic sections (ellipse, parabola, hyperbola) as intersections of a plane with an infinite cone, using Dandelin spheres to reveal their focal properties. ② Core mathematical concepts include the geometric definition of conics, foci and directrices, tangent spheres and planes, and spatial relationships such as intersection, symmetry, and angle bisectors. ③ Construction highlights: the InfiniteCone command creates the cone, IntersectPath computes the section curve, Sphere constructs the Dandelin spheres, and a rich set of commands (Point, Line, Plane, Mirror, Ray, Angle, AngularBisector, OrthogonalLine, Circle, Segment, PointIn, OrthogonalPlane, If) build auxiliary elements like vertices V1, V2, sphere centers O1, O2, foci F_1, F_2, and various helper points, lines, and planes. ④ Suitable for high school or early college courses in solid geometry and analytic geometry, as well as for mathematical demonstrations illustrating the unified geometric nature of conic sections.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → APoint(zAxis) → BLine(C, yAxis) → aPlane(D, a) → bMirror(C, D) → C'Ray(D, C') → cAngle(c, zAxis) → δInfiniteCone(A, B, aa) → dIntersectPath(b, xz) → intIntersectPath(xz, d) → gIntersect(int, g) → V2, V1Line(A, V1) → c_1Line(A, V2) → c_2Line(A, B) → vertPoint(c_2) → KIntersectPath(b, d) → rAngularBisector(c_1, int) → f, iIntersect(vert, f) → O2Intersect(vert, i) → O1OrthogonalLine(O2, c_1, xz) → jOrthogonalLine(O1, c_1, xz) → kIntersect(c_1, j) → GIntersect(c_1, k) → HCircle(O2, G, xz) → pCircle(O1, H, xz) → qIntersect(int, q) → F_1, JIntersect(int, p) → F_2, MSphere(O1, F_1) → lSphere(O2, F_2) → mCircle(zAxis, H) → tan2Circle(zAxis, G) → tan1Point(r) → QLine(Q, A) → genIntersect(gen, tan1) → E,Intersect(gen, tan2) → F,Segment(Q, F_2) → eSegment(Q, F) → nSegment(Q, F_1) → sSegment(Q, E) → tCircle(vert, Q) → d_1Plane(tan2) → oIntersectPath(o, b) → dirOrthogonalLine(Q, dir, b) → a_1Intersect(dir, a_1) → IOrthogonalLine(Q, a_1, b) → b_1Intersect(b_1, int) → LIntersect(dir, r) → N,Intersect(int, r) → O, PIntersect(dir, int) → RSegment(Q, I) → e_1Segment(L, R) → f_1Intersect(b_1, r) → S, TPointIn(b) → WOrthogonalPlane(R, dir) → uIntersectPath(u, d) → g_1Intersect(g_1, tan2) → U, V, ,Intersect(g_1, d_1) → Z, A_1, ,Segment(Z, U) → h_1If(bb < aa, text3, If[bb > aa, text1, text2]) → angleAngle(Q, I, R, b) → αPoint(dir) → B_1Angle(F_1, R, B_1, b) → β