
四边形的旋转对称性 by youngcar
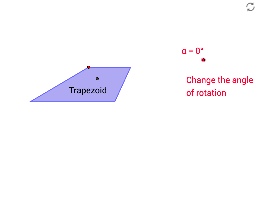
几何画板及绘图内容加载中,请稍等……
①本范例演示了四边形(特别是梯形)的旋转对称性现象;②涉及的核心数学概念包括对称性、旋转、几何作图;③作图要点——从下方『构造摘要』提炼用到了Segment(线段)、OrthogonalLine(垂线)、Point(点)、Intersect(交点)、Circle(圆)、Line(直线)、Rotate(旋转)、Polygon(多边形)、Mirror(镜像)等GeoGebra命令/对象;④适合初中及以上学生学习几何变换和对称性知识,也可用于数学教学演示。
GeoGebra 命令及参数
Segment(A, B) → aOrthogonalLine(A, a) → bOrthogonalLine(B, a) → cPoint(b) → COrthogonalLine(C, b) → dIntersect(c, d) → DSegment(C, B) → eSegment(D, A) → fIntersect(e, f) → ESegment(K, L) → lCircle(K, L) → pPoint(p) → MSegment(K, M) → mLine(M, l) → nLine(L, m) → qIntersect(n, q) → NSegment(M, L) → rSegment(N, K) → sIntersect(r, s) → ORotate(C, (-α), E) → C'Rotate(D, (-α), E) → D'Rotate(B, (-α), E) → B'Rotate(A, (-α), E) → A'Rotate(M, (-α), O) → M'Rotate(N, (-α), O) → N'Rotate(L, (-α), O) → L'Rotate(K, (-α), O) → K'Segment(P, Q) → tSegment(P, R) → e_1Line(Q, e_1) → g_1Line(R, t) → h_1Intersect(g_1, h_1) → SSegment(R, Q) → i_1Segment(S, P) → j_1Intersect(i_1, j_1) → TRotate(P, (-α), T) → P'Rotate(R, (-α), T) → R'Rotate(S, (-α), T) → S'Rotate(Q, (-α), T) → Q'Segment(U, V) → t_1Segment(U, W) → a_2Line(W, t_1) → b_2Point(b_2) → ZSegment(Z, V) → c_2Polygon(U, V, Z, W) → poly5, u, v, z, wSegment(W, V) → d_2Segment(Z, U) → e_2Intersect(d_2, e_2) → A_1Rotate(U, (-α), A_1) → U'Rotate(V, (-α), A_1) → V'Rotate(Z, (-α), A_1) → Z'Rotate(W, (-α), A_1) → W'Polygon(U', V', Z', W') → poly5', u', v', z', w'Line(B_1, C_1) → f_2Mirror(D_1, f_2) → E_1Segment(D_1, E_1) → g_2Intersect(f_2, g_2) → F_1Rotate(D_1, (-α), F_1) → G_1Rotate(B_1, (-α), F_1) → H_1Rotate(E_1, (-α), F_1) → I_1Rotate(C_1, (-α), F_1) → J_1Intersect(z', w') → HIntersect(a_2, z) → I