
球与圆锥的截交与参数度量演示
几何画板及绘图内容加载中,请稍等……
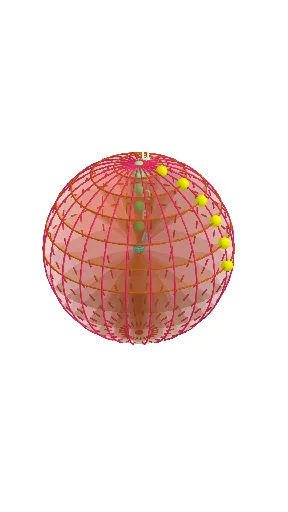
本范例展示球体与圆锥在三维空间中的相交过程,以及由截交得到的几何关系与距离度量。核心数学概念包括:立体几何中的球/圆锥模型、圆与截面关系、三维几何相交(Intersect)与截交路径(IntersectPath)、以及度量量的计算(Distance)。作图时通过构造球体与圆锥的空间实体,并用直线、平面等几何对象参与相交;再借助 Rotate 与 Mirror 等变换来生成对称/旋转后的结构,从而形成可视化的截面曲线与关键点。命令层面主要用到:Intersect(求相交点/对象)、Point(关键点标注)、Sphere(球体)、Cone(圆锥)、Line(直线)、Plane(平面)、Rotate(旋转变换)、Mirror(镜像变换)、IntersectPath(得到相交路径/截交曲线)、Segment(线段)、Circle(圆)、Distance(距离度量)、Text(标注信息)。对象方面包含大量用于标识点、截面与距离量的构造变量(如 A、B、C、P、distanceAP 等)。适合中学高年级到大学初阶的立体几何、几何作图与三维建模教学与探究。
GeoGebra 命令及参数
Intersect(zAxis, yAxis) → APoint(zAxis) → BSphere(A, B) → aIntersect(xAxis, a, 2) → CLine(A, C) → fPoint(yAxis) → DLine(A, D) → gRotate(f, (-(15°)), g) → f'Rotate(f', (-(15°)), g) → f''Rotate(f'', (-(15°)), g) → f'''Rotate(f''', (-(15°)), g) → hRotate(h, (-(15°)), g) → h'Plane(A, C, D) → pIntersectPath(p, a) → cPoint(f) → EIntersect(f', a) → F, GIntersect(f'', a) → H, IIntersect(f''', a) → J, KIntersect(h, a) → L, MIntersect(h', a) → N, OLine(A, B) → iSegment(C, E) → jRotate(G, 90°, i) → G'Rotate(G, 180°, i) → G'_1Circle(G, G', G'_1) → dCircle(i, I) → eCircle(i, K) → kCircle(i, O) → qCircle(i, M) → rLine(G, j) → lIntersect(l, i) → PDistance(A, P) → distanceAPCone(d, (-distanceAP)) → b, b_2, b_3Line(I, j) → mIntersect(m, i) → QDistance(A, Q) → distanceAQCone(e, (-distanceAQ)) → n, s, oIntersect(i, k) → R,Line(K, j) → tIntersect(t, i) → SDistance(A, S) → distanceASCone(k, (-distanceAS)) → u, c_1, vLine(M, j) → f_1Intersect(f_1, i) → TDistance(A, T) → distanceATCone(r, (-distanceAT)) → w, d_1, a_1Line(O, j) → g_1Intersect(g_1, i) → UDistance(A, U) → distanceAUCone(q, (-distanceAU)) → b_1, e_1, h_1Circle(i, E) → k_1Circle(O, K, C) → p_1Rotate(p_1, 15°, i) → q_1Rotate(p_1, 30°, i) → r_1Rotate(p_1, 45°, i) → s_1Rotate(p_1, 60°, i) → t_1Rotate(p_1, 75°, i) → c_2Rotate(p_1, 90°, i) → d_2Mirror(b_3, xOyPlane) → i_1Mirror(v, xOyPlane) → v'Intersect(g, c) → V, WPlane(A, W, C) → p_2Mirror(h_1, p_2) → j_1Mirror(a_1, p_2) → l_1Mirror(o, p_2) → o'Rotate(p_1, (-(15°)), i) → e_2Rotate(p_1, (-(30°)), i) → f_2Rotate(p_1, (-(45°)), i) → g_2Rotate(p_1, (-(60°)), i) → h_2Rotate(p_1, (-(75°)), i) → k_2
AI 绘图提示语参考
请绘制一个三维空间中的球体与圆锥相交的图形。图形中包含一个球体和一个圆锥,它们相交产生可见的相交曲线。通过辅助线和平面计算相交路径,并使用旋转操作生成对称或旋转的配置。测量从构造点到相交点的距离,用于验证几何关系。图形中还包含圆、线段和距离标注,以展示球体、圆锥和其截面之间的几何关系。
以上提示语为根据原始绘图命令整理而来,仅供参考。