
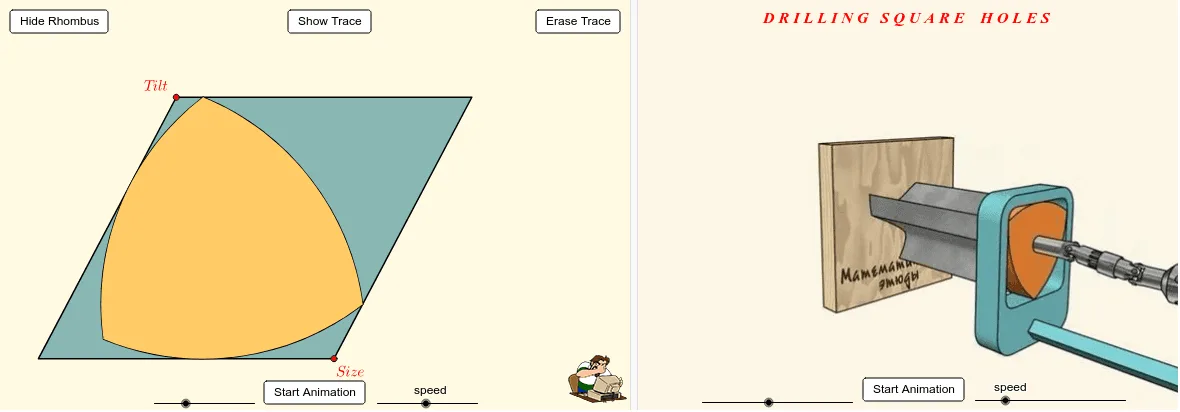
Reuleaux三角形在菱形内的滚动
几何画板及绘图内容加载中,请稍等……
此演示展示Reuleaux三角形在菱形内的滚动运动与轨迹。核心涉及曲线几何、常宽三角形性质、圆弧构造与相对运动。作图要点包括使用Ray、Point、Rotate、Mirror、Circle、Intersect、Translate等GeoGebra命令,通过角度旋转、对称镜像、圆弧交点等构造三角形轨迹。适合高中几何、微积分极限过渡或参数方程单元的探究与可视化。
GeoGebra 命令及参数
Ray(A, A') → aa'Point(aa') → BRotate(B, (-betta), B) → B'Mirror(B, A) → BBCircle(BB, A) → bbaCircle(A, B) → abIntersect(ab, bba, 2) → DRotate(D, (-betta), B) → D'Rotate(B, delta, D) → KCircle(K, K2) → kk2Translate(D', Vector[B, K]) → D''Translate(B', Vector[B, K]) → B''Ray(B'', D'') → bd''Intersect(kk2, bd'') → K1,Angle(K1, K, K2) → kIntersect(ab, bba, 1) → CDistance(C, D) → cdVector(K, M) → kmTranslate(D, km) → D1Rotate(D1, k, M) → D2Translate(C, km) → C1Rotate(C1, k, M) → C2Translate(B, km) → B1Rotate(B1, k, M) → B2Translate(A, km) → A1Rotate(A1, k, M) → A2Ray(M, M') → mm'Point(mm') → NRotate(N, π / 10, M) → N'Rotate(N, π / 2, M) → Q'CircleArc(M, N', Q') → nq'Point(nq') → QOrthogonalLine(N, Line[M, Q]) → nIntersect(Line[M, Q], n) → LDistance(N, L) → nlDilate(D2, c, M) → D3Dilate(C2, c, M) → C3Translate(C3, Vector[N, L]) → C4Dilate(B2, c, M) → B3Line(D3, B3) → d3b3Line(C4, d3b3) → c4Dilate(A2, c, M) → A3Line(A3, C3) → a3c3Ray(B, D) → bdRay(B', D') → bd'Translate(N, Vector[M, Q]) → PPolyLine(M, N, P, Q, M) → mLine(B3, A3) → b3a3Circle(C3, B3) → c3b3Line(C3, D3) → c3d3Translate(B3, Vector[N, L]) → B4Line(B4, b3a3) → b4Intersect(c3d3, b4) → RAffineRatio(D3, C3, R) → dcrDilate(B4, dcr1, D3) → B5AffineRatio(C3, D3, R) → cdrDilate(B5, cdr1, C3) → B6Translate(B6, Vector[N, L]) → B7Line(B6, B7) → b6b7Intersect(a3c3, d3b3) → TRay(C3, A3) → c3a3Intersect(c3b3, c3a3) → U,Intersect(a3c3, c4) → SAffineRatio(T, U, S) → tusDilate(C4, tus1, U) → C5OrthogonalLine(C5, d3b3) → c5Intersect(d3b3, c5) → VAffineRatio(D3, B3, V) → dbvDilate(C5, dbv1, D3) → C6OrthogonalLine(C6, b6b7) → c6Intersect(b6b7, c6) → EAffineRatio(B6, B7, E) → beDilate(C6, be1, B6) → C7Intersect(Line[M, Q], b6b7) → FTranslate(A3, Vector[C7, F]) → A4Line(A4, Line[M, Q]) → a4Line(A3, Line[M, N]) → a3Intersect(a3, a4) → GTranslate(C3, Vector[A3, G]) → V2Translate(B3, Vector[A3, G]) → V1Translate(D3, Vector[A3, G]) → V3CircleArc(V1, V3, V2) → v132CircleArc(V2, V1, V3) → v213CircleArc(V3, V2, V1) → v321Distance(M, N) → dLine(I, xAxis) → iPoint(i) → JPolygon({M, N, P, Q}) → m1CircleSector(V1, V3, V2) → v1CircleSector(V2, V1, V3) → v2CircleSector(V3, V2, V1) → v3