
Volume Calculation
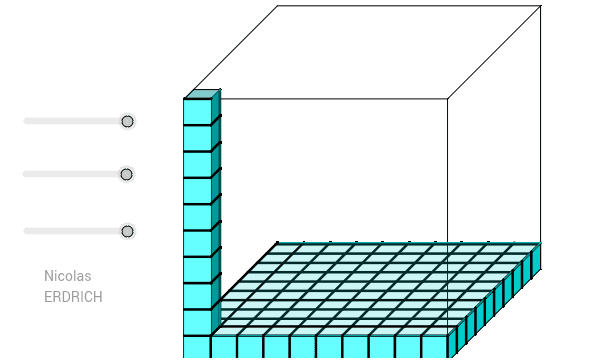
Loading the math board and drawing, please wait…
This example demonstrates how to calculate the volumes of different shapes through geometric construction. It involves core mathematical concepts such as geometry, trigonometric functions, and probability & statistics. Using GeoGebra commands like Line, Circle, Intersect, etc., it constructs shapes such as rectangles, circles, and polygons, and calculates volumes through transformations like rotation and translation. Suitable for high school mathematics education and learning.
GeoGebra Commands & Parameters
Line(A, xAxis) → aOrthogonalLine(A, a) → q_4Circle(A, 2) → rIntersect(r, q_4, 2) → EIntersect(r, a, 2) → BOrthogonalLine(E, q_4) → sOrthogonalLine(B, a) → tIntersect(s, t) → FRotate(F, 45*°, E) → S'Angle(F, E, S') → αSegment(E, S') → i_1Segment(E, F) → j_1Midpoint(j_1) → TCircle(E, T) → k_1Intersect(k_1, i_1, 1) → HSegment(E, H) → p_1Line(H, j_1) → q_1Line(F, p_1) → r_1Intersect(q_1, r_1) → VSegment(A, E) → s_1Segment(F, B) → t_1Line(B, r_1) → a_2Line(V, s_1) → b_2Intersect(a_2, b_2) → WPolygon(A, B, F, E) → poly1, p_2, r_2, s_2, q_2Polygon(B, W, V, F) → poly2, r_3, w, v, s_3Polygon(E, F, V, H) → poly3, q_3, s_4, v_1, uTranslate(A, B - A) → A'Translate(E, B - A) → E'Sequence(Sequence[Polygon[Translate[A, Vector[k * Vector[A, B] + l * Vector[A, E]]], Translate[B, Vector[k * Vector[A, B] + l * Vector[A, E]]], Translate[F, Vector[k * Vector[A, B] + l * Vector[A, E]]], Translate[E, Vector[k * Vector[A, B] + l * Vector[E, A]]]], k, 0, o], l, 0, 0) → ligneSequence(Sequence[Polygon[Translate[E, Vector[l * Vector[A, B] + m * Vector[E, H]]], Translate[F, Vector[l * Vector[A, B] + m * Vector[E, H]]], Translate[V, Vector[l * Vector[A, B] + m * Vector[E, H]]], Translate[H, Vector[l * Vector[A, B] + m * Vector[E, H]]]], l, 0, o], m, 0, q) → liste3Sequence(Polygon[Translate[B, k * (W - B) + o * (B - A)], Translate[W, k * (W - B) + o * (B - A)], Translate[V, k * (W - B) + o * (B - A)], Translate[F, k * (W - B) + o * (B - A)]], k, 0, q) → ligne2Sequence(Sequence[Polygon[Translate[A, Vector[k * Vector[B, A] - l * Vector[E, A]]], Translate[B, Vector[k * Vector[B, A] - l * Vector[E, A]]], Translate[F, Vector[k * Vector[B, A] - l * Vector[E, A]]], Translate[E, Vector[k * Vector[B, A] - l * Vector[E, A]]]], k, 0, 0], l, 0, p) → listeSequence(Sequence[Polygon[Translate[B, Vector[-l * Vector[E, A] + m * Vector[E, H]]], Translate[W, Vector[-l * Vector[E, A] + m * Vector[E, H]]], Translate[V, Vector[-l * Vector[E, A] + m * Vector[E, H]]], Translate[F, Vector[-l * Vector[E, A] + m * Vector[E, H]]]], l, 0, p], m, 0, 0) → liste2Translate(E, p * (E - A)) → E'_1Translate(F, p * (E - A)) → F'Translate(V, p * (E - A)) → V'Translate(H, p * (E - A)) → H'Polygon(E'_1, F', V', H') → Haut, e'_1, f', v', h'Translate(A, (o + 1) * (B - A)) → Sommet1Translate(A, (p + 1) * (E - A)) → Sommet2OrthogonalLine(E'_1, s_1) → bOrthogonalLine(Sommet1, p_2) → cIntersect(b, c) → Sommet3Translate(A, (q + 1) * (H - E)) → Sommet4OrthogonalLine(Sommet4, p_2) → dSegment(A, Sommet4) → eSegment(A, E'_1) → fLine(E'_1, e) → gIntersect(d, g) → CLine(Sommet3, g) → hLine(C, b) → iIntersect(h, i) → DLine(D, d) → jLine(Sommet1, h) → kIntersect(j, k) → GSegment(E'_1, Sommet3) → lSegment(Sommet3, Sommet1) → mSegment(Sommet3, D) → nSegment(D, G) → a_1Segment(D, C) → b_1Segment(C, E'_1) → c_1Segment(F', B) → d_1Segment(V', V) → e_1Segment(H', V') → f_1Segment(A, Sommet1) → g_1Point(g_1) → ISegment(I, G) → h_1Segment(F, E) → l_1Segment(F, B) → m_1Line(E, g_1) → n_1Intersect(n_1, m) → JSegment(F, J) → c_2Segment(F', V') → d_2Segment(B, W) → e_2Line(J, h_1) → f_2Intersect(a_1, f_2) → KPoint(h_1) → LSegment(L, K) → g_2Segment(J, K) → h_2Line(H, h_1) → i_2Line(K, l) → j_2Intersect(i_2, j_2) → MSegment(M, K) → k_2Intersect(i_2, e_1) → NSegment(N, M) → l_2Intersect(r_1, j_2) → OSegment(F, O) → m_2Sequence(Segment[Translate[F, -k * (A - B)], Translate[O, -k * (A - B)]], k, 0, o) → seg4Line(N, b_1) → n_2Intersect(n_2, h_2) → PSegment(N, P) → t_2Line(V, t_2) → a_3Intersect(a_3, h_2) → QLine(S', a_3) → b_3Intersect(b_3, h_2) → RSegment(V, Q) → c_3Polygon(F, V, N, M, K, J) → poly4, f_3, v_2, n_3, m_3, k_3, j_3Polygon(V, F, F', V') → poly5, v_3, f_4, f'_1, v'_1Segment(N, M) → d_3Segment(M, K) → e_3Sequence(Segment[Translate[F, -k * (A - E)], Translate[E, -k * (A - E)]], k, 0, p) → seg_1Sequence(Segment[Translate[F, k * (B - A)], Translate[B, k * (B - A)]], k, 0, o) → seg_2Sequence(Segment[Translate[F, -l * (E - H) + o * (B - A)], Translate[B, -l * (E - H) + o * (B - A)]], l, 1, q) → seg10Sequence(Segment[Translate[N, l * (H - E)], Translate[P, l * (H - E)]], l, -2, q - 3) → seg5Sequence(Segment[Translate[B, -k * (B - F)], Translate[W, -k * (B - F)]], k, 1, p) → seg_3