
Velocity and Acceleration Vector Decomposition on a Parametric Curve
Loading the math board and drawing, please wait…
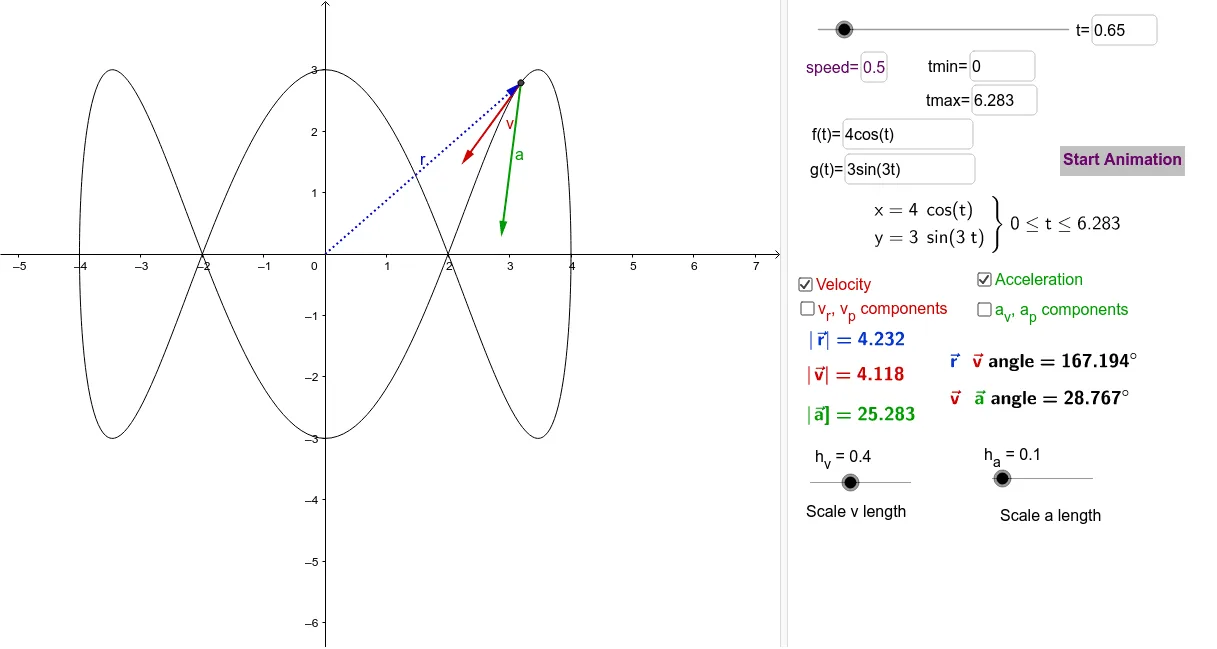
This example demonstrates how to decompose the velocity and acceleration vectors into components parallel and perpendicular to the position vector along a parametric curve. Core mathematical concepts include parametric equations, derivatives, vector decomposition, and the geometric interpretation of velocity and acceleration. Construction highlights: using GeoGebra commands such as Derivative to compute first and second derivatives, CurveCartesian to define the parametric curve, If and Textfield for conditional display and input, and sliders (tmax, tmin) to adjust the parameter range. Key objects include f, g and their derivatives, the velocity vector v, acceleration vector a, position vector r, and constructed parallel components v_r, v_p and perpendicular components a_v, a_p, with ScaleVelocity and ScaleAcceleration to adjust vector lengths for clarity. Suitable for advanced high school or university courses in calculus and vector analysis, providing an intuitive understanding of tangential and normal acceleration decomposition in curvilinear motion.
GeoGebra Commands & Parameters
Derivative(g) → g'Derivative(g') → g''Derivative(f) → f'Derivative(f') → f''CurveCartesian(f(t), g(t), t, tmin, tmax) → cCurveCartesian(f'(t), g'(t), t, tmin, tmax) → cdotCurveCartesian(f''(t), g''(t), t, tmin, tmax) → cddotTextfield(tmin) → TminTextfield(tmax) → TmaxTextfield(f) → FofTTextfield(g) → GofTIf(togA ≟ 1, "Stop Animation", "Start Animation") → AnimateTextfield(speed) → SPDTextfield(t) → tEq
AI Drawing Prompt Reference
On a parametric curve, draw the velocity and acceleration vectors at a point, and decompose them into components parallel and perpendicular to the position vector. Show the trajectory of the position vector, the velocity and acceleration vectors, and their decomposed components. Use sliders to adjust the parameter range and display parameter values and function expressions in text fields. Animate the changes in velocity and acceleration vectors and their decomposition into tangential and normal components.
The prompt above was compiled from the original drawing commands and is for reference only.