
Soccer Ball Construction
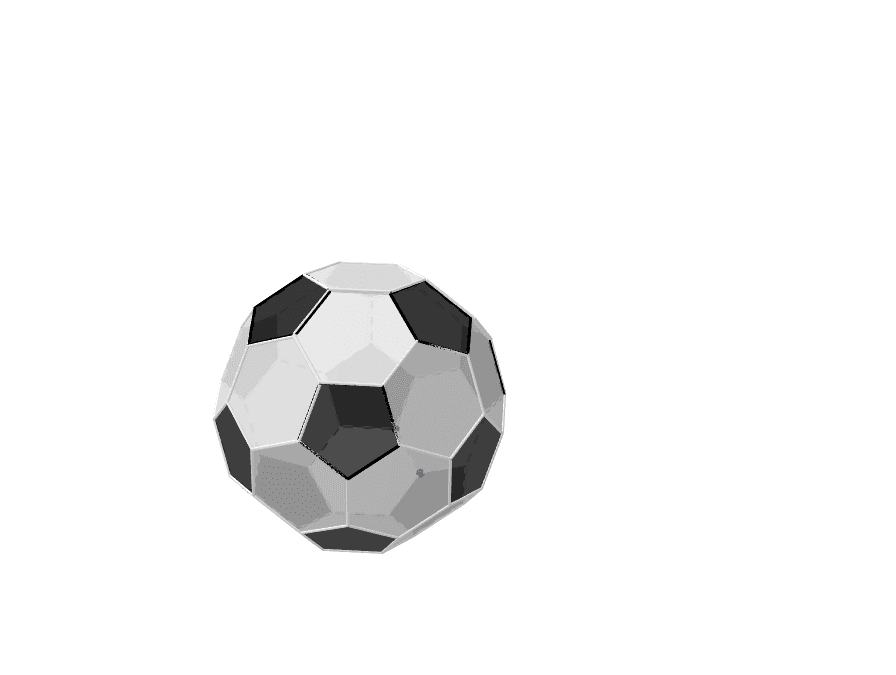
Loading the math board and drawing, please wait…
This example demonstrates how to construct a soccer ball's geometric model by rotating polygons. Key math concepts include polygons, rotation, solid geometry, and spherical geometry. Construction highlights involve using GeoGebra commands like Polygon, Rotate, and Plane to rotate a regular pentagon, creating an approximation of a spherical surface. Suitable for high school solid geometry instruction and geometric construction practice, helping students understand the relationship between polyhedra and spheres.
GeoGebra Commands & Parameters
Polygon(A, B, 6) → poligon1, a, F, b, c, d, e, f, C, D, ERotate(poligon1, 138*°, e) → poligon1'Rotate(E, -120*°, F, poligon1') → E'Rotate(F, -120*°, E', poligon1') → F'Rotate(E', -120*°, F', poligon1') → E''Rotate(F', -120*°, E'', poligon1') → F''Plane(E', F, A) → gPolygon(E', F, 5, g) → poligon2, h, i, j, k, l, G, H, IPlane(I, E', F') → mPolygon(I, E', 6, m) → poligon3, n, M, p, q, r, s, t, J, K, LPlane(H, I, M) → oPolygon(H, I, 6, o) → poligon4, a_1, Q, b_1, c_1, d_1, e_1, f_1, N, O, PPlane(Q, H, G) → uPolygon(Q, H, 6, u) → poligon5, g_1, U, h_1, i_1, j_1, k_1, l_1, R, S, TPlane(C, B, T) → vPolygon(B, T, 5, v) → poligon6, m_1, n_1, p_1, q_1, r_1, V, W, ZPlane(L, N, O) → wPolygon(L, N, 5, w) → poligon7, s_1, t_1, a_2, b_2, c_2, A_1, B_1, C_1Plane(F'', E, D) → o_1Polygon(F'', E, 5, o_1) → poligon8, d_2, e_2, f_2, g_2, h_2, D_1, E_1, F_1Plane(E_1, D, C) → u_1Polygon(E_1, D, 6, u_1) → poligon9, i_2, J_1, j_2, k_2, l_2, m_2, n_2, G_1, H_1, I_1Plane(F_1, E_1, J_1) → v_1Polygon(F_1, E_1, 6, v_1) → poligon10, p_2, N_1, q_2, r_2, s_2, t_2, a_3, K_1, L_1, M_1Plane(K, F', E'') → w_1Polygon(K, F', 5, w_1) → poligon11, b_3, c_3, d_3, e_3, f_3, O_1, P_1, Q_1Plane(P_1, O_1, F'') → o_2Polygon(P_1, O_1, 6, o_2) → poligon12, g_3, U_1, h_3, i_3, j_3, k_3, l_3, R_1, S_1, T_1Plane(I_1, H_1, V) → u_2Polygon(I_1, H_1, 6, u_2) → poligon13, m_3, A_2, n_3, p_3, q_3, r_3, s_3, V_1, W_1, Z_1Plane(L_1, J_1, I_1) → v_2Polygon(L_1, J_1, 5, v_2) → poligon14, t_3, a_4, b_4, c_4, d_4, B_2, C_2, D_2Plane(W_1, V, T) → w_2Polygon(W_1, V, 6, w_2) → poligon15, e_4, H_2, f_4, g_4, h_4, i_4, j_4, E_2, F_2, G_2Plane(G_2, U, Q) → o_3Polygon(G_2, U, 5, o_3) → poligon16, k_4, l_4, m_4, n_4, p_4, I_2, J_2, K_2Plane(Q_1, P_1, U_1) → u_3Polygon(Q_1, P_1, 6, u_3) → poligon17, q_4, O_2, r_4, s_4, t_4, a_5, b_5, L_2, M_2, N_2Plane(M_1, L_1, D_2) → v_3Polygon(M_1, L_1, 6, v_3) → poligon18, c_5, S_2, d_5, e_5, f_5, g_5, h_5, P_2, Q_2, R_2Plane(L_2, N_1, M_1) → w_3Plane(L_2, N_1, M_1) → o_4Polygon(L_2, N_1, 5, o_4) → poligon19, i_5, j_5, k_5, l_5, m_5, T_2, U_2, V_2Plane(Z_1, W_1, H_2) → u_4Polygon(Z_1, W_1, 5, u_4) → poligon20, n_5, p_5, q_5, r_5, s_5, W_2, Z_2, A_3Plane(W_2, G_2, K_2) → v_4Polygon(W_2, G_2, 6, v_4) → poligon21, t_5, E_3, a_6, b_6, c_6, d_6, e_6, B_3, C_3, D_3Plane(B_3, P, O) → w_4Plane(L, K, Q_1) → o_5Polygon(L, K, 6, o_5) → poligon22, f_6, I_3, g_6, h_6, i_6, j_6, k_6, F_3, G_3, H_3Plane(P_2, C_2, Z_1) → u_5Polygon(P_2, C_2, 6, u_5) → poligon23, l_6, M_3, m_6, n_6, p_6, q_6, r_6, J_3, K_3, L_3Plane(H_3, G_3, N_2) → v_5Polygon(H_3, G_3, 5, v_5) → poligon24, s_6, t_6, a_7, b_7, c_7, N_3, O_3, P_3Plane(H_3, C_1, B_1) → w_5Polygon(H_3, C_1, 6, w_5) → poligon25, d_7, T_3, e_7, f_7, g_7, h_7, i_7, Q_3, R_3, S_3Plane(U_2, V_2, N_2) → o_6Polygon(U_2, V_2, 6, o_6) → poligon26, j_7, Z_3, k_7, l_7, m_7, n_7, p_7, U_3, V_3, W_3Plane(L_3, M_3, R_2) → u_6Plane(L_3, M_3, W_3) → v_6Polygon(L_3, M_3, 5, v_6) → poligon27, q_7, r_7, s_7, t_7, a_8, A_4, B_4, C_4Plane(R_3, Q_3, A_1) → w_6Polygon(R_3, Q_3, 6, w_6) → poligon28, b_8, G_4, c_8, d_8, e_8, f_8, g_8, D_4, E_4, F_4Plane(P_3, S_3, C_4) → o_7Polygon(P_3, S_3, 6, o_7) → poligon29, h_8, K_4, i_8, j_8, k_8, l_8, m_8, H_4, I_4, J_4Plane(H_4, S_3, R_3) → u_7Polygon(H_4, S_3, 5, u_7) → poligon30, n_8, p_8, q_8, r_8, s_8, L_4, M_4, N_4Plane(E_3, A_3, L_3) → v_7Polygon(E_3, A_3, 6, v_7) → poligon31, t_8, R_4, a_9, b_9, c_9, d_9, e_9, O_4, P_4, Q_4