
Rotating Circles at Different Speeds
Loading the math board and drawing, please wait…
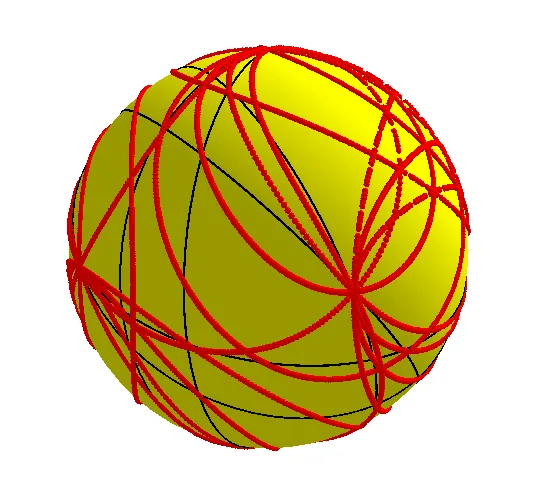
This example demonstrates the trajectories and dynamic effects formed when two circles rotate at different speeds. It involves core mathematical concepts such as circle, rotation, parametric equations, and trigonometry. Key GeoGebra commands and objects used in the construction include Intersect, Sphere, Circle, and Rotate, as summarized. It is suitable for high school and above students studying parametric equations, locus, and dynamic geometry, or for demonstrating rotational motion in physics.
GeoGebra Commands & Parameters
Intersect(xAxis, zAxis) → ASphere(A, 1) → aIntersect(zAxis, a) → B, CIntersect(yAxis, a) → D, EIntersect(xAxis, a) → F, GCircle(G, C, F) → cCircle(D, G, F) → dCircle(C, D, B) → eRotate(c, t, zAxis) → c'Rotate(c, (2 * t), zAxis) → c'_1Rotate(d, t, xAxis) → d'Rotate(d, (2 * t), xAxis) → d'_1Rotate(e, (-t), yAxis) → e'Rotate(e, (-((2 * t))), yAxis) → e'_1Intersect(c', c'_1) → H, I, ,Intersect(c', d') → P, Q, ,Intersect(c', d'_1) → R, S, ,Intersect(c', e') → V, W, ,Intersect(c', e'_1) → Z, A_1, ,Intersect(c'_1, d') → B_1, C_1, ,Intersect(c'_1, d'_1) → D_1, E_1, ,Intersect(c'_1, e') → H_1, I_1, ,Intersect(c'_1, e'_1) → J_1, K_1, ,Intersect(d', e') → R_2, S_2, ,Intersect(d', e'_1) → T_2, U_2, ,Intersect(d'_1, e') → V_2, W_2, ,Intersect(d'_1, e'_1) → Z_2, A_3, ,
AI Drawing Prompt Reference
Draw a unit sphere centered at the origin in 3D space. On the sphere, place three great circles, each lying near a coordinate plane. Rotate two of these circles around the vertical axis at different speeds, rotate another two around a horizontal axis at different speeds, and rotate the last one around another horizontal axis in the opposite direction. As these circles rotate, they intersect each other, generating a dynamic set of intersection points that trace complex paths. The result is a symmetric, animated geometric pattern showing circular motion and trigonometric relationships.
The prompt above was compiled from the original drawing commands and is for reference only.