
Pythagorean Theorem Direct Proof
Loading the math board and drawing, please wait…
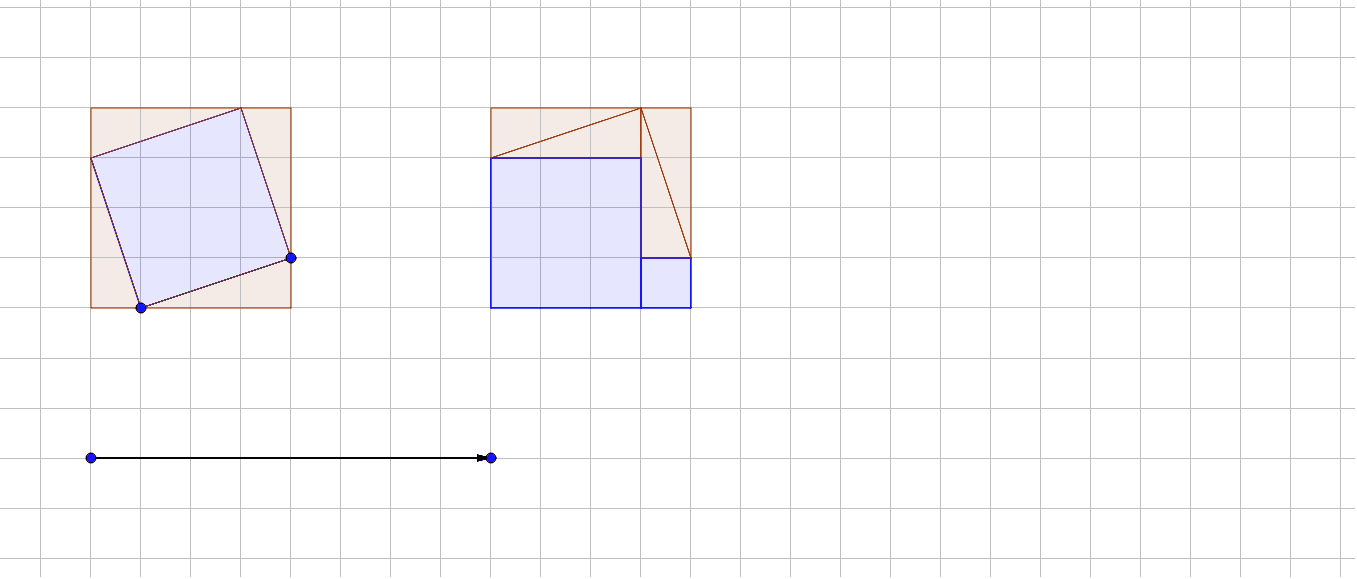
This example demonstrates a geometric proof of the Pythagorean Theorem through rotation and geometric transformations, illustrating the relationship between the sides of a right triangle. Core concepts include the Pythagorean Theorem, rotation, geometric transformations, and trigonometry. It uses commands like Segment, Polygon, Line, Intersect, Vector, Translate, Midpoint, Rotate in GeoGebra. Suitable for high school mathematics teaching and understanding geometric proofs.
GeoGebra Commands & Parameters
Segment(A, B) → aPolygon(A, B, 4) → poly1, b, c, d, e, C, DLine(D, yAxis) → fLine(B, f) → gLine(A, xAxis) → hLine(C, h) → iIntersect(g, h) → EPolygon(A, B, E) → poly2, e_1, a_1, b_1Intersect(g, i) → FPolygon(B, C, F) → poly3, f_1, b_2, c_1Intersect(f, i) → GPolygon(C, D, G) → poly4, g_1, c_2, d_1Intersect(f, h) → HPolygon(D, A, H) → poly5, h_1, d_2, a_2Segment(I, J) → jVector(I, J) → uTranslate(G, u) → G'Vector(I, J) → vTranslate(H, v) → H'Vector(I, J) → wTranslate(F, w) → F'Vector(I, J) → kTranslate(E, k) → E'Vector(I, J) → lTranslate(C, l) → C'Translate(D, l) → D'Translate(G, l) → G'_1Polygon(C', D', G'_1) → poly4', g'_1, c', d'Vector(I, J) → mTranslate(B, m) → B'Translate(C, m) → C'_1Translate(F, m) → F'_1Polygon(B', C'_1, F'_1) → poly3', f'_1, b', c'_1Midpoint(D', C') → KMidpoint(C', B') → LRotate(C', 180°, K) → C''Rotate(D', 180°, K) → D''Rotate(G'_1, 180°, K) → MPolygon(C'', D'', M) → poly4'', m_1, c'', d''Rotate(B', 180°, L) → B''Rotate(C'_1, 180°, L) → NRotate(F'_1, 180°, L) → OPolygon(B'', N, O) → poly3'', o, b'', nRotate(D', 90°, M) → D''_1Polygon(H', D''_1, 4) → poly6, p, q, r, s, P, QPolygon(D''_1, E', 4) → poly7, t, i_1, j_1, k_1, R, S