
Pythagorean Theorem Demonstration by Mark Beckwith
Loading the math board and drawing, please wait…
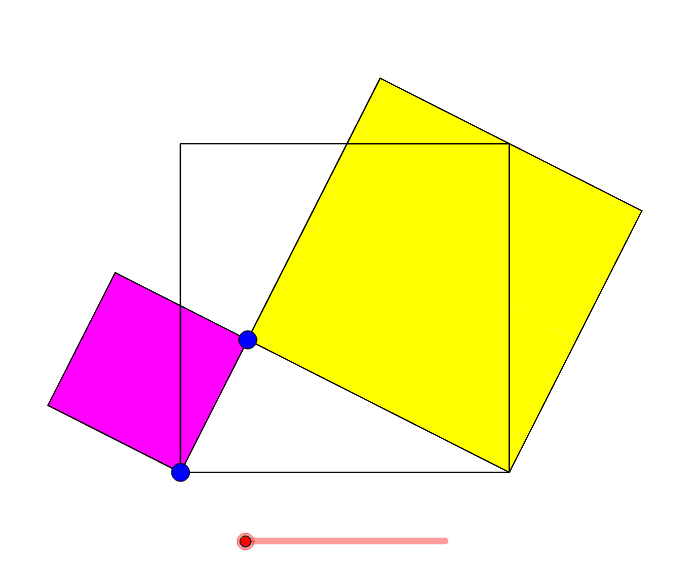
This example visually demonstrates the Pythagorean theorem by dragging points and using a slider, illustrating the relationship between the sides of a right triangle. Core mathematical concepts include the Pythagorean theorem, right triangles, and distance calculations. It utilizes GeoGebra commands/objects such as Point, Intersect, CircleArc, Polygon, If, Rotate, Dilate, Vector, Translate, and Midpoint. Suitable for middle school students and above to learn and understand the proof and applications of the Pythagorean theorem.
GeoGebra Commands & Parameters
Point(xAxis) → AIntersect(xAxis, yAxis) → BCircleArc(B, D, A) → cPoint(c) → EPolygon(A, E, 4) → poly1, a, b, d, e, F, GPolygon(E, C, 4) → poly2, f, g, h, i, H, IPolygon(A, C, 4) → poly3, j, k, l, m, J, KIntersect(b, m) → LIntersect(i, l) → MPolygon(A, G, F, L) → poly4, a_1, g_1, f_1, l_1Polygon(M, I, J) → poly5, j_1, m_1, i_1Polygon(J, C, H) → poly6, h_1, j_2, c_1Polygon(A, E, L) → poly7, l_2, a_2, e_1Polygon(E, M, J, C) → poly8, e_2, m_2, j_3, c_2If(n < 1, n, 1) → r1Rotate(A, (-(((r1 * 90))°)), A) → A'Rotate(G, (-(((r1 * 90))°)), A) → G'Rotate(F, (-(((r1 * 90))°)), A) → F'Rotate(L, (-(((r1 * 90))°)), A) → L'Polygon(A', G', F', L') → poly4', a', g', f', l'Dilate(J, If[1 ≤ n < 2, 2 - n, If[n ≥ 2, 0, 1]], C) → J'Vector(J, J') → uTranslate(M, u) → M'Translate(I, u) → I'Translate(J, u) → J'_1Polygon(M', I', J'_1) → poly5', j'_1, m', i'Midpoint(A, J) → NVector(A, L) → vTranslate(C, v) → C'Vector(A, E) → wTranslate(C, w) → C'_1Polygon(C, C', C'_1) → poly9, c'_1, c_3, c'Polygon(C', J, H, C'_1) → poly10, c'_2, j_4, h_2, c'_3Dilate(J, If[2 ≤ n < 3, 3 - n, If[n ≥ 3, 0, 1]], K) → J'_2Vector(J, J'_2) → pTranslate(C', p) → C''Translate(J, p) → J'_3Translate(H, p) → H'Translate(C'_1, p) → OPolygon(C'', J'_3, H', O) → poly10', c'', j'_3, h', oIf(3 ≤ n ≤ 4, n - 3, 0) → r2Rotate(C, (-(((r2 * 90))°)), J) → C'_2Rotate(C', (-(((r2 * 90))°)), J) → C''_1Rotate(C'_1, (-(((r2 * 90))°)), J) → PPolygon(C'_2, C''_1, P) → poly9', p_1, c'_4, c''_1