
Proof Without Words: Quadratic Equation Demonstration
Loading the math board and drawing, please wait…
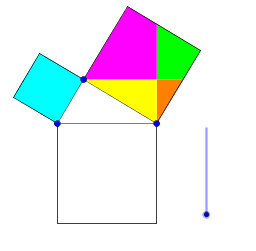
This example visually demonstrates the relationship between quadratic equations and geometric figures through dynamic geometry. Key math concepts include quadratic equations, means inequality, natural numbers, and matrix operations. GeoGebra commands like Point, Mirror, Semicircle, Intersect, CircleArc, Polygon, OrthogonalLine, Dilate, Vector, and Translate are used to construct the geometric representation. Suitable for high school and above students to understand abstract mathematical concepts intuitively.
GeoGebra Commands & Parameters
Point(xAxis) → APoint(yAxis) → BMirror(A, B) → A'Semicircle(A, A') → cIntersect(c, yAxis, 1) → CCircleArc(B, C, A) → dPoint(d) → DPolygon(A, D, 4) → poly1, a, b, e, f, E, FPolygon(D, A', 4) → poly2, g, h, i, j, G, HPolygon(A', A, 4) → poly3, k, l, m, n, I, JOrthogonalLine(A', k) → pOrthogonalLine(D, p) → qIntersect(p, q) → KIntersect(p, i) → LIntersect(q, h) → MPolygon(D, K, L, H) → poly4, d_1, k_1, l_1, h_1Polygon(K, L, G, M) → poly5, k_2, l_2, g_1, m_1Polygon(A', K, M) → poly6, m_2, a', k_3Polygon(A', K, D) → poly7, d_2, a'_1, k_4Dilate(K, 1 - o, J) → K'Dilate(K, 1 - o, A') → K'_1Dilate(K, 1 - o, I) → K'_2Dilate(K, 1 - o, A) → K'_3Vector(K, K'_1) → uVector(K, K') → vVector(K, K'_2) → wVector(K, K'_3) → rTranslate(K, w) → K'_4Translate(L, w) → L'Translate(G, w) → G'Translate(M, w) → M'Polygon(K'_4, L', G', M') → poly5', k'_4, l', g', m'Translate(D, v) → D'Translate(K, v) → K'_5Translate(L, v) → L'_1Translate(H, v) → H'Polygon(D', K'_5, L'_1, H') → poly4', d', k'_5, l'_1, h'Translate(A', r) → A''Translate(K, r) → K'_6Translate(M, r) → M'_1Polygon(A'', K'_6, M'_1) → poly6', m'_1, a'', k'_6Translate(A', u) → A''_1Translate(K, u) → K'_7Translate(D, u) → D'_1Polygon(A''_1, K'_7, D'_1) → poly7', d'_1, a''_1, k'_7Dilate(E, 1 - o, D'_1) → E'Vector(E, E') → sPolygon(F, E, D, A) → poly8, f_1, e_1, d_3, a_1Translate(F, s) → F'Translate(E, s) → E'_1Translate(D, s) → D'_2Translate(A, s) → A'_1Polygon(F', E'_1, D'_2, A'_1) → poly8', f', e'_1, d'_2, a'_2