
Polar Coordinates Boat Game by Woogon Chung (2)
Loading the math board and drawing, please wait…
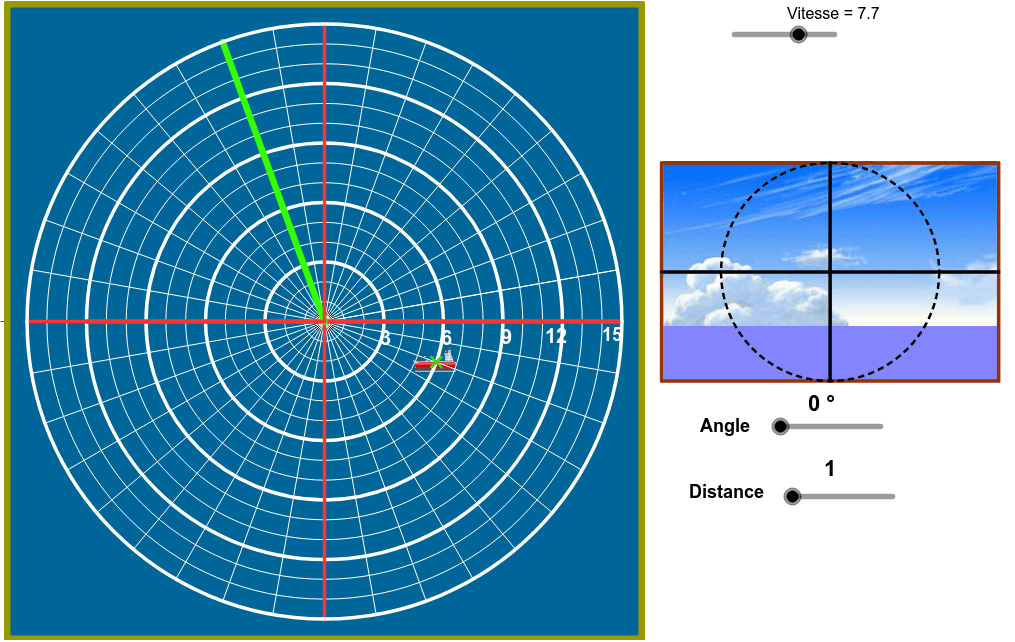
This example uses polar coordinates to find the position of a boat. Key mathematical concepts include polar coordinates, angle calculation, and conditional probability. Using GeoGebra commands such as Random, Circle, Ray, etc., it dynamically demonstrates points and lines in the polar coordinate system. Suitable for high school mathematics education, particularly in coordinate geometry and probability & statistics.
GeoGebra Commands & Parameters
Random(4.0, 15.0) → rrCircle(A, (1.5 * v - 1.0) * rr) → c'Ray(A, (0.0, 0.0)) → aOrthogonalLine(A, a) → bIntersect(c', b) → B, CIntersect(c', a) → D, TCircumcircleArc(B, D, C) → dMidpoint(C, D) → EMidpoint(B, D) → F_2Ray(A', E) → eRay(A', F_2) → fIntersect(d, e) → G,Intersect(d, f) → H,CircumcircleArc(G, D, H) → gCircle(I, 1.0) → hSequence(Text[If[s < 10.0, " ", ""] + (s), (21.6 + 2.0 * Mod[s - 1.0, 3.0], 7.75 - 2.0 * Div[s - 1.0, 3.0])], s, 1.0, 12.0) → liste3Circle(J, 1.0) → kSequence(Text[If[s ≟ 1.0, " ", If[s < 5.0, " ", ""]] + (30.0 * (s - 1.0)) + "º", (21.25 + 2.0 * Mod[s - 1.0, 3.0], -(6.25) - 2.0 * Div[s - 1.0, 3.0])], s, 1.0, 12.0) → liste4If(yB > -(5.0), 5.0*°, ((xB - 3.0 * yB) / 2.0 - 19.0 - 1.0) * 30.0°) → angIf(ang ≟ α ∧ dist ≟ rr, true, false) → razAngle((1.0, 0.0), (0.0, 0.0), A) → βSegment(O, N) → mCircle(A, (2.0 * v - 1.0) * rr - n) → pSequence(Circle[A, (1.5 * v - 1.0) * rr - i], i, 0.0, n, n / 10.0) → liste5Polygon(P, Q, R, S) → poly1, p_1, q, r_1, sAngle((1.0, 0.0), (0.0, 0.0), A) → γCircle((0.0, 0.0), If[2.0 * v * rr > 12.0, 0.0, 2.0 * v * rr]) → cMidpoint(K, L) → UMidpoint(U, L) → VMidpoint(U, V) → WMidpoint(V, L) → ZSegment(K, C_1) → lLine(A, l) → iSegment(A, U) → tIntersect(c, t) → A_1, B_1Segment(U, A_1) → a_1Circle(U, W) → c_1Circle(U, V) → d_1Circle(U, Z) → e_1Circle(U, L) → f_1Rotate(C_1, 6.0 * v, U) → L'Segment(U, L') → b_1Mod(v * 100.0, 2.0) → abSequence(Circle[(0.0, 0.0), t], t, 1.0, 15.0) → liste1Sequence(Segment[(0.0, 0.0), (15.0; 2.0 * 3.141592653589793 * t / 36.0)], t, 0.0, 37.0) → liste2Segment(O, D_1) → jCircle(O, C_1) → g_1Point(g_1) → E_1Segment(O, E_1) → h_1Circle(U, C_1) → k_1Circle(F_1, 8.0 - r / 2.5) → q_1Line(F_1, l) → i_1Intersect(q_1, i_1) → G_1, H_1Line(J_1, r_1) → j_1Point(j_1) → N_1Line(N_1, l) → l_1Line(J_1, l) → m_1Point(m_1) → O_1Point(l_1) → P_1Intersect(l_1, r_1) → M_1Polygon(M_1, N_1, J_1, F) → poly2, m_2, n_1, j_2, f_2Point(l_1) → Q_1Point(m_1) → R_1Polygon(P_1, Q_1, R_1, O_1) → poly3, p_2, q_2, r_2, o_1Point(j_1) → S_1Point(o_1) → T_1Polygon(S_1, T_1, O_1, J_1) → poly4, s_1, t_1, o_2, j_3Midpoint(s_1) → V_1Midpoint(o_2) → W_1Midpoint(S_1, J_1) → Z_1Midpoint(t_1) → A_2Segment(V_1, W_1) → a_2Segment(Z_1, A_2) → b_2Intersect(b_2, a_2) → B_2Circle(B_2, V_1) → c_2