
Parabola Motion Demo
Loading the math board and drawing, please wait…
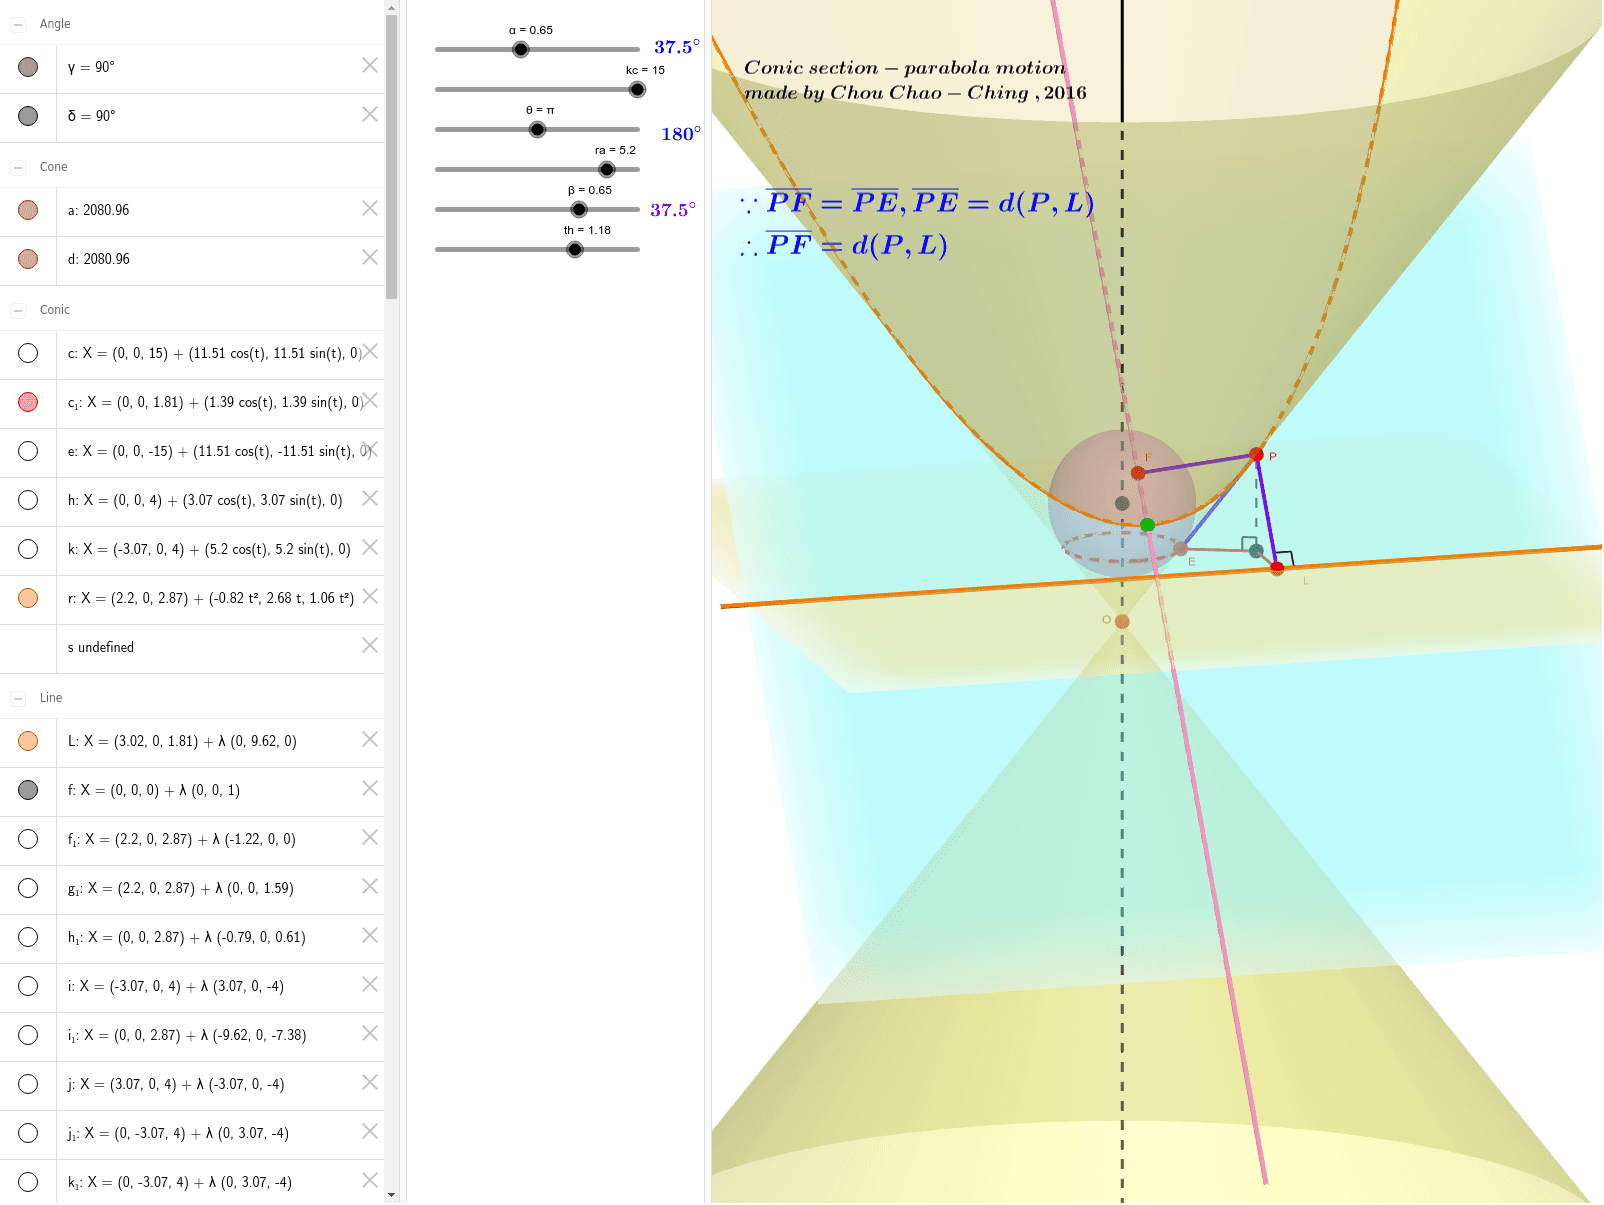
This example demonstrates the motion trajectory and geometric properties of a parabola. It involves core mathematical concepts such as parabola, symmetry, exponent functions, logic reasoning, cuboid in solid geometry, and median value theorem. The construction highlights the use of GeoGebra commands/objects like Intersect (intersection), OrthogonalLine (perpendicular line), Cone (cone), Mirror (reflection), Line (line), Vector (vector), Circle (circle), Midpoint (midpoint), Rotate (rotation), Plane (plane), Point (point), IntersectPath (path intersection), AngularBisector (angle bisector), Sphere (sphere), OrthogonalPlane (orthogonal plane), Angle (angle), and Segment (segment). Suitable for high school and above learners to understand dynamic changes and geometric constructions of parabolas.
GeoGebra Commands & Parameters
Intersect(xAxis, zAxis) → OOrthogonalLine(O, xOyPlane) → fCone(C, O, rc) → a, c, bMirror(C, O) → C'Cone(C', O, rc) → d, e, gLine(A, O) → iMirror(A, B) → A'Vector(O, C) → uCircle(A, ra, u) → kCircle(B, rb, f) → hLine(A', O) → jIntersect(h, k) → D, E_1, ,Midpoint(D, E_1) → G'Line(G', i) → nIntersect(n, zAxis) → GRotate(B, β, G, xOyPlane) → B'Plane(G, G', A) → lPlane(E_1, D, G) → mOrthogonalLine(G, m) → qPoint(q) → HVector(G, H) → vPlane(E_1, D, I) → oIntersectPath(o, a) → rIntersectPath(o, d) → sIntersect(j, r) → J,Intersect(f, o) → KLine(J, I) → tAngularBisector(t, j) → f_1, g_1Intersect(f, f_1) → L_1OrthogonalLine(L_1, j, space) → h_1Intersect(j, h_1) → M_1Sphere(L_1, M_1) → wOrthogonalLine(L_1, o) → i_1Intersect(i_1, o) → FOrthogonalPlane(M_1, f) → a_1IntersectPath(a_1, w) → c_1Intersect(i, s) → N,Midpoint(J, N) → MMirror(F, M) → F'Mirror(T, B) → T'Line(T', O) → pLine(T, O) → j_1Line(T, O) → k_1IntersectPath(o, a_1) → LLine(R, O) → m_1Intersect(m_1, r) → P,Intersect(m_1, c_1) → E,OrthogonalLine(P, a_1) → n_1Intersect(n_1, a_1) → SOrthogonalLine(P, L, space) → p_1Intersect(L, p_1) → UAngle(L, p_1) → γSegment(U, S) → q_1Segment(S, E) → r_1Segment(P, U) → s_1Segment(P, E) → t_1Segment(F, P) → b_1Angle(r_1, n_1) → δSegment(P, S) → d_1
AI Drawing Prompt Reference
Draw a parabola motion demonstration, showing trajectory and symmetry, highlighting core mathematical concepts. Start with coordinate axes intersection and perpendicular lines, construct cones and reflections, then create vectors, circles, and rotations. Use path intersections, midpoints, and angle bisectors to build geometric bodies, and finally complete the dynamic changes with spheres, planes, and angle bisectors.
The prompt above was compiled from the original drawing commands and is for reference only.