
Net of a Cylinder - Interactive GeoGebra Demonstration
Loading the math board and drawing, please wait…
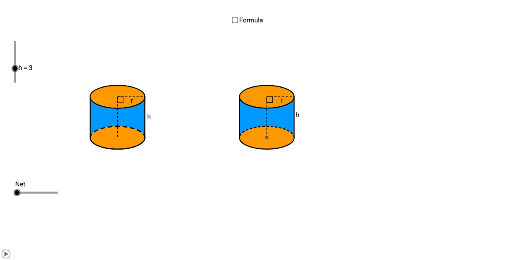
① This GeoGebra example dynamically demonstrates the unfolding of a three-dimensional cylinder into its two-dimensional net, showing how the lateral surface and two circular bases are laid out flat. ② Core mathematical concepts include solid geometry, cylinder nets, surface development, and the combination of circles, ellipses, and rectangles through geometric transformations. ③ Construction highlights: using commands such as Point, Circle, Intersect, Ellipse, Vector, Translate, Rotate, Mirror, Polygon, Arc, Segment, and Slider to build the cylinder's base circles and elliptical projections, then animate the unfolding of the lateral rectangle and circular bases. Key objects include A, r, c, B, C, d, D, E, e, h, F, G, u, poly1, and more. ④ Suitable for middle and high school geometry lessons, introductory solid geometry, and interactive teaching materials that help students visualize the relationship between 3D shapes and their 2D nets.
GeoGebra Commands & Parameters
Point(xAxis) → ACircle(A, r) → cIntersect(c, xAxis) → B, CEllipse(E, D, C) → eIntersect(xAxis, yAxis) → FVector(F, G) → uTranslate(B, Vector[(u * h)]) → B'_1Translate(C, Vector[(u * h)]) → C'_1Translate(A, Vector[(u * h)]) → A'Translate(e, Vector[(u * h)]) → e'_1Polygon(B'_1, B, C, C'_1) → poly1, b', b, c_1, c'Arc(e'_1, C'_1, B'_1) → fArc(e, B, C) → gArc(e, C, B) → kArc(e'_1, C'_1, B'_1) → p_5Arc(e'_1, B'_1, C'_1) → qArc(e, B, C) → sSegment(A', A) → h_6Segment(A', C'_1) → pAngle(A, A', C'_1) → αLine(A, A') → jIntersect(e'_1, j) → H, IIntersect(k, j) → J,Circle(I, r) → tIntersect(t, j, 2) → KCircle(K, I) → d_1Circle(J, r) → e_1Intersect(e_1, j, 1) → LCircle(L, J) → f_1Intersect(f_1, j, 2) → MIntersect(d_1, j, 2) → NIntersect(s, j) → O,Vector(H, N) → vVector(O, M) → wTranslate(H, Vector[(v * n)]) → H'_1Translate(D, Vector[(u * h)]) → D'Translate(E, Vector[(u * h)]) → E'Line(B, B'_1) → lLine(C, C'_1) → mIntersect(d_1, l, 1) → PIntersect(d_1, m, 1) → QVector(B'_1, P) → zVector(C'_1, Q) → u_1Translate(B'_1, Vector[(z * n)]) → B''Translate(C'_1, Vector[(u_1 * n)]) → C''Midpoint(B'_1, A') → RMidpoint(B, A) → SLine(R, S) → a_1Intersect(q, a_1) → T,Intersect(d_1, a_1, 1) → UVector(T, U) → v_1Translate(T, Vector[(v_1 * n)]) → T'Intersect(f_1, l, 1) → VIntersect(f_1, m, 1) → WIntersect(f_1, a_1, 2) → ZIntersect(s, a_1) → A_1,Vector(B, V) → w_1Vector(A_1, Z) → z_1Vector(C, W) → b_1Translate(B, Vector[(w_1 * (n - 1))]) → B'Translate(A_1, Vector[(z_1 * (n - 1))]) → C_1Translate(O, Vector[(w * (n - 1))]) → O'Translate(C, Vector[(b_1 * (n - 1))]) → C'If(n < 1, B'', P) → B_1If(n < 1, T', U) → D_1If(n < 1, H'_1, N) → E_1If(n < 1, C'', Q) → F_1Conic(B_1, D_1, E_1, F_1, I) → g_1Conic(I, B_1, D_1, E_1, F_1) → h_1If(n < 1, B, If[n < 2, B', V]) → G_1If(n < 1, A_1, If[n < 2, C_1, Z]) → H_1If(n < 1, O, If[n < 2, O', M]) → I_1If(n < 1, C, If[n < 2, C', W]) → J_1Conic(G_1, H_1, I_1, J_1, J) → k_1Vector(H, O) → i_1Translate(H, Vector[(i_1 * (n - 2))]) → H'If(n < 2, H, If[n < 3, H', O]) → K_1Segment(H, K_1) → j_1Arc(e, B, C) → q_1Intersect(g, k_1) → M_1, N_1, R_1, S_1Arc(k_1, M_1, N_1) → r_1Arc(k_1, N_1, M_1) → p_1Arc(e, C, B) → s_1OrthogonalLine(I, j) → l_1OrthogonalLine(J, l) → m_1Circle(I, w_2) → t_1Intersect(t_1, l_1, 1) → L_1Intersect(t_1, l_1, 2) → O_1OrthogonalLine(O_1, l_1) → n_1OrthogonalLine(L_1, m_1) → a_2Intersect(m_1, n_1) → P_1Intersect(m_1, a_2) → Q_1Circle(H, r) → c_2Intersect(c_2, j, 2) → T_1Circle(T_1, H) → d_2OrthogonalLine(H, j) → b_2Intersect(d_2, l_1, 1) → U_1OrthogonalLine(T_1, j) → e_2Intersect(d_2, e_2, 1) → V_1Angle(U_1, T_1, V_1) → βCircle(L_1, r) → f_2Intersect(f_2, l_1, 2) → W_1Vector(I, W_1) → u_2Translate(d_2, Vector[(u_2 * (n - 3))]) → g_2Center(g_2) → Z_1Intersect(g_2, b_2) → A_2, B_3Rotate(A_2, w_3, Z_1) → B_2If(n < 3, H, If[n < 4, B_2, L_1]) → C_2Mirror(C_2, j) → D_2Mirror(E_2, j) → F_2Midpoint(I, L_1) → G_2Intersect(m, l_1) → H_2Midpoint(H_2, C'_1) → I_2Vector(H_2, G_2) → v_2OrthogonalLine(C'_1, m) → i_2Polygon(D_2, F_2, E_2, C_2) → poly2, d_3, f_3, e_3, c_3Vector(C'_1, W_1) → z_2Translate(C'_1, Vector[(z_2 * (n - 3))]) → J_2If(n < 3, C'_1, If[n < 4, J_2, W_1]) → K_2Mirror(K_2, j) → L_2Conic(D_2, L_2, I, K_2, C_2) → h_2Arc(h_2, B_2, D_2) → k_2Arc(h_2, B_2, D_2) → p_2Conic(F_2, N_2, J, M_2, E_2) → q_2Intersect(q_2, k_1) → O_2, P_2, Q_2, R_2Center(h_2) → S_2Center(q_2) → T_2OrthogonalLine(T_2, j) → j_2OrthogonalLine(S_2, j) → m_2Intersect(h_2, m_2) → U_2, V_2Intersect(q_2, j_2) → W_2, Z_2Polygon(U_2, D_2, F_2, W_2) → poly3, u_3, d_4, f_4, w_5Polygon(V_2, C_2, E_2, Z_2) → poly4, v_3, c_4, e_4, z_3Intersect(q_2, d_3, 2) → A_3Intersect(q_2, e_3, 2) → C_3Polygon(F_2, A_3, C_3, E_2) → poly5, f_5, a_3, c_5, e_5Arc(q_2, C_3, A_3) → s_2Arc(q_2, E_2, F_2) → t_2Arc(q_2, E_2, F_2) → g_3Segment(A_3, C_3) → l_2Intersect(k_1, l_2) → D_3, E_3Segment(E_3, A_3) → n_2Segment(D_3, C_3) → b_3Segment(F_2, E_2) → h_3Arc(k_1, D_3, E_3) → k_3Segment(E_3, D_3) → i_3Segment(D_2, C_2) → j_3Segment(L_2, K_2) → l_3Arc(q_2, W_2, F_2) → p_3Arc(q_2, E_2, Z_2) → q_3Arc(q_2, E_2, Z_2) → r_3Arc(q_2, W_2, F_2) → s_3Intersect(k_1, d_3) → F_3, J_3Intersect(k_1, e_3) → G_3, K_3Arc(k_1, G_3, F_3) → t_3Arc(k_1, F_3, R_2) → g_4Arc(k_1, O_2, G_3) → h_4Segment(F_2, E_2) → r_2Intersect(k_1, r_2) → H_3, I_3Segment(F_2, I_3) → m_3Segment(E_2, H_3) → n_3Arc(q_2, E_2, F_2) → k_4Arc(k_1, H_3, I_3) → p_4Segment(I_3, H_3) → a_4Segment(F_2, E_2) → b_4Segment(E_2, Z_2) → i_4Segment(D_2, F_2) → j_4Segment(C_2, E_2) → l_4Arc(k_1, N_1, M_1) → q_4Arc(k_1, N_1, M_1) → r_4Midpoint(j_4) → L_3Translate(e, Vector[(u * h)]) → e'Arc(k_1, M_1, N_1) → s_4Arc(k_1, R_2, N_1) → t_4Arc(k_1, R_2, O_2) → d_5Arc(k_1, P_2, Q_2) → g_5Center(h_1) → M_3Segment(M_3, F_1) → aMidpoint(c_1) → N_3Point(xAxis) → O_3Circle(O_3, r) → h_5Intersect(h_5, xAxis) → P_3, Q_3Ellipse(R_3, S_3, Q_3) → k_5OrthogonalLine(S_3, i_2) → iOrthogonalLine(Q_3, i_2) → m_4OrthogonalLine(P_3, i_2) → n_4OrthogonalLine(R_3, i_2) → a_5Intersect(i_2, a_5) → T_3Intersect(n_4, i_2) → U_3Intersect(i, i_2) → V_3Intersect(m_4, i_2) → W_3Ellipse(T_3, V_3, W_3) → q_5Polygon(U_3, W_3, Q_3, P_3) → poly6, u_4, w_6, q_6, p_6Ellipse(T_3, V_3, W_3) → r_5Arc(k_5, Q_3, P_3) → s_5Arc(k_5, P_3, Q_3) → t_5Center(q_5) → Z_3Segment(O_3, Z_3) → b_5Segment(Z_3, W_3) → i_5Angle(W_3, Z_3, O_3) → γIntersect(k_1, f_4) → A_4,Intersect(k_1, e_4) → B_4,Intersect(g_3, k_1) → C_4, D_4, E_4, F_4Polygon(Z_2, C_4, B_4) → poly7, b_6, z_4, c_6Polygon(F_4, A_4, W_2) → poly8, w_7, f_6, a_6Arc(q_2, W_2, F_4) → d_6Arc(q_2, C_4, Z_2) → e_6Arc(q_2, W_2, F_4) → g_6Arc(q_2, C_4, Z_2) → k_6Arc(k_1, G_3, J_3) → r_6Intersect(k_1, b) → G_4, H_4Segment(N_2, H_4) → j_5Segment(M_2, G_4) → l_5Segment(E_3, D_3) → m_5Segment(H_3, I_3) → n_5