
Mechanism Animation (Exponential and Polynomial Functions)
Loading the math board and drawing, please wait…
In collections
My 3D Collection
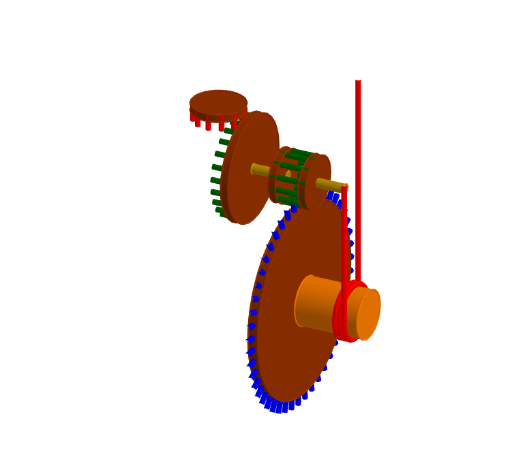
This GeoGebra example demonstrates a dynamic mechanical mechanism animation, where multiple geometric objects such as cylinders, parametric curves, and segments move under the control of a parameter t. The core mathematical concepts involve exponential functions, polynomial functions, and parametric equations, along with sequence generation and geometric transformations. The construction uses commands like Sequence to create object lists, Cylinder for 3D parts, CurveCartesian for parametric curves, and Segment for connecting points. Key objects include multiple cylinders (c1 to c8 with copies), curves (c, d, a), and lists (liste1, liste2, liste3), all animated via a slider or parameter. This is suitable for high school or university mathematics education, illustrating the integration of functions and geometric construction in mechanical simulations.
GeoGebra Commands & Parameters
Sequence(Segment[(-0.8, cos(i + t), sin(i + t)), (0.8, cos(i + t), sin(i + t))], i, π / 6, (2 * π), π / 6) → liste2Cylinder((-0.8, 0, 0), (-0.5, 0, 0), 1.1) → c3, c3_2, c3_3, c3_4Cylinder((0.8, 0, 0), (0.5, 0, 0), 1.1) → c4, c4_2, c4_3, c4_4Cylinder((-0.2, 0, -5.2), (0.2, 0, -5.2), 4) → c1, c1_2, c1_3, c1_4Cylinder((-2, 0, 0), (-0.5, 0, 0), 0.2) → c6, c6_2, c6_3, c6_4Cylinder((-2.3, 0, 0), (-2, 0, 0), 2.2) → c5, c5_2, c5_3, c5_4Sequence(Segment[(-2, (2 * cos(i + t)), (2 * sin(i + t))), (-2.8, (2 * cos(i + t)), (2 * sin(i + t)))], i, π / 12, (2 * π), π / 12) → liste3Cylinder((0.5, 0, 0), (2, 0, 0), 0.2) → c7, c, d, aCylinder((-3.5, 0, 2.2), (-3.5, 0, 2.5), 1.1) → c8, c8_2, c8_3, c8_4Cylinder((0.3, 0, -5.2), (3, 0, -5.2), 1) → c2, c2_2, c2_3, c2_4CurveCartesian(2 + (s * 0.5 / ((5 * π))), (1.1 * cos(s)), -5.2 + (-1.1 * sin(s)), s, 0, (5 * π)) → gSegment((2.5, -1.1, -5.2), (2.5, -1.1, (1.1 * t))) → iSegment((2, 1.1, -5.2), (2, 1.1, 5 - (1.1 * t))) → hSequence(Segment[(0, (4 * cos(i - t / 4 + e)), -5.2 + (4 * sin(i - t / 4 + e))), (0, (4.5 * cos(i - t / 4 + e)), -5.2 + (4.5 * sin(i - t / 4 + e)))], i, 0, (2 * π), π / 24) → liste1Sequence(Segment[(-3.5 + cos(i - (2 * t) - e), sin(i - (2 * t) - e), 1.8), (-3.5 + cos(i - (2 * t) - e), sin(i - (2 * t) - e), 2.5)], i, π / 6, (2 * π), π / 6) → liste4
AI Drawing Prompt Reference
Create a 3D mechanical animation scene with multiple cylinders, parametric curves, and segments. Central area has a set of short segments evenly distributed around a circle, rotating about a horizontal axis. Symmetric cylindrical structures appear on both sides. A helical curve at the bottom connects two vertical cylinders, with two vertical segments moving up and down. Two additional ring-like segment sets rotate around different axes. All objects move under a parameter, showing dynamic mechanical linkage.
The prompt above was compiled from the original drawing commands and is for reference only.