
Jet and Wind Vector Synthesis Simulation
Loading the math board and drawing, please wait…
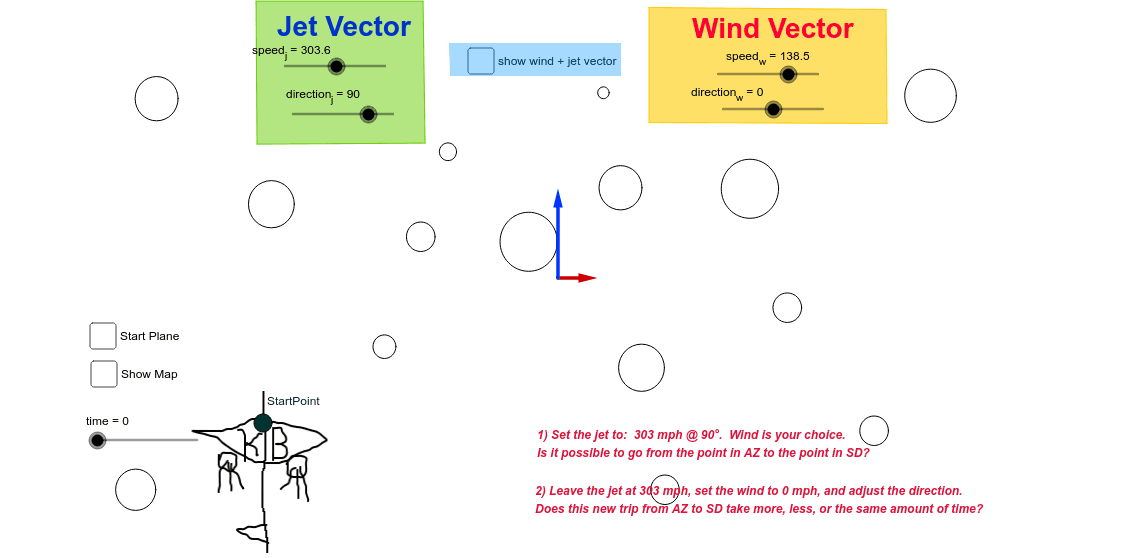
This GeoGebra example dynamically demonstrates the resultant flight trajectory and position changes of a jet plane when synthesizing its velocity vector with the wind velocity vector in a two-dimensional plane. The core mathematical concepts involved include vectors, the parallelogram rule for vector addition, the decomposition and synthesis of velocity and direction, and parametric coordinate geometry. In terms of construction, the `Vector` command is utilized to define the plane's velocity `vector_j` and the wind's velocity `vector_w`, while the `Translate` command is applied to simulate the resultant displacement over time `time`. Visual elements like the plane polygon `poly1`, direction segments, and guide circles are rendered using `Polygon`, `Segment`, and `Circle` commands, with interactive sliders controlling speed and direction parameters. This example is highly suitable for high school and college-level physics, analytic geometry, and linear algebra courses, serving as an intuitive teaching tool for vector addition and kinematic synthesis.
GeoGebra Commands & Parameters
Vector((0, 0), StartPoint) → vector_sVector((0, 0), (0 + speed_w * cos(direction_w / 180 * 3.14), 0 + speed_w * sin(direction_w / 180 * 3.14))) → vector_wVector((0, 0), (0 + speed_j * cos(direction_j / 180 * 3.14), 0 + speed_j * sin(direction_j / 180 * 3.14))) → vector_jTranslate((-383.74751, 427.82819), Vector[vector_w * time]) → B_9Translate((-101.94722, 122.76974), Vector[vector_w * time]) → B_1Translate((373.59867, -717.66124), Vector[vector_w * time]) → B_2Translate((291.78433, -304.20541), Vector[vector_w * time]) → B_3Translate((-478.63411, 139.75126), Vector[vector_w * time]) → B_4Translate((158.83601, 627.76471), Vector[vector_w * time]) → B_5Translate((-605.40599, -232.82316), Vector[vector_w * time]) → B_6Translate((670.17568, 302.42241), Vector[vector_w * time]) → B_7Translate((218.49231, 305.81139), Vector[vector_w * time]) → B_8Circle(B_1, 100) → c_1Circle(B_2, 50) → c_2Circle(B_3, 80) → c_3Circle(B_4, 50) → c_4Circle(B_8, 75) → c_8Circle(B_7, 100) → c_7Circle(B_5, 20) → cCircle(B_6, 40) → c_6Polygon(A, B, C, D) → poly1, a_1, b, c_5, dPolygon(E, F, G, H) → poly2, e, f, g, hCircle(B_9, 30) → c_9Vector((1500, 600), (1500 + speed_w * cos(direction_w / 180 * 3.14), 600 + speed_w * sin(direction_w / 180 * 3.14))) → vector_1Translate((-1000, 250), Vector[vector_1 * time]) → B_{10}Circle(B_{10}, 80) → c_10Translate((0, 0), Vector[time * vector_j + time * vector_w + vector_s]) → plane_wTranslate(Rotate[pic1, direction_j / 180 * 3.14, (0, 0)], Vector[vector_s + (vector_j + vector_w) * time]) → pic1'Translate((0, 0), Vector[time * vector_j + vector_s]) → planexxnoxxwindSegment(StartPoint, plane_w) → iVector((0, 0), (0 + speed_w * cos(direction_w / 180 * 3.14), 0 + speed_w * sin(direction_w / 180 * 3.14))) → vector_2Vector((0, 0), (0 + speed_w * cos(direction_w / 180 * 3.14), 0 + speed_w * sin(direction_w / 180 * 3.14))) → vector_3Vector((0, 0), (0 + speed_w * cos(direction_w / 180 * 3.14), 0 + speed_w * sin(direction_w / 180 * 3.14))) → vector_4Translate((-1400.59867, 607.66124), Vector[vector_2 * time]) → B_{11}Translate((1300.59867, 617.66124), Vector[vector_4 * time]) → B_{13}Translate((1103.59867, -517.66124), Vector[vector_3 * time]) → B_{12}Circle(B_{13}, 90) → c_13Circle(B_{12}, 50) → c_12Circle(B_{11}, 75) → c_11Vector((0, 0), (0 + speed_w * cos(direction_w / 180 * 3.14), 0 + speed_w * sin(direction_w / 180 * 3.14))) → vector_5Vector((0, 0), (0 + speed_w * cos(direction_w / 180 * 3.14), 0 + speed_w * sin(direction_w / 180 * 3.14))) → vector_6Translate((-1473.59867, -717.66124), Vector[vector_5 * time]) → B_{14}Translate((800.59867, -100.66124), Vector[vector_6 * time]) → B_{15}Circle(B_{15}, 50) → c_15Circle(B_{14}, 70) → c_14Polygon(J, L, R, S) → poly3, j_1, l, r, s