
Geometric Proof of Pythagorean Theorem
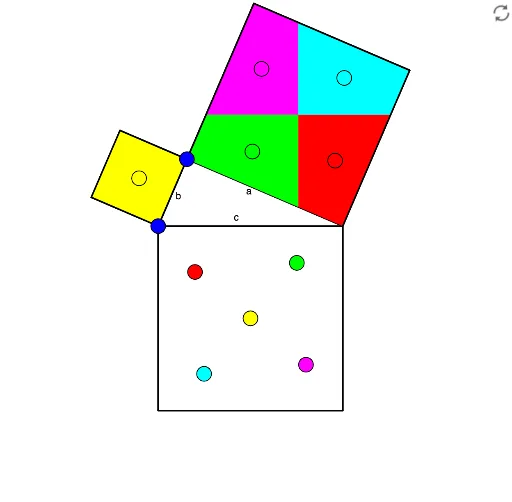
Loading the math board and drawing, please wait…
This example demonstrates the Pythagorean Theorem through geometric manipulation by dragging points. It involves core concepts like the Pythagorean Theorem, right triangles, and Cartesian coordinates. Construction highlights the use of GeoGebra commands such as Intersect, Point, Ray, Mirror, Semicircle, CircleArc, Segment, Polygon, Midpoint, OrthogonalLine, Vector, Centroid, and Translate. Ideal for middle school and above to explore and understand proofs of the Pythagorean Theorem.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → APoint(xAxis) → BRay(A, B) → aPoint(a) → CMirror(C, A) → C'Semicircle(C, C') → cIntersect(c, yAxis) → D,CircleArc(A, D, C) → dPoint(d) → ESegment(C, E) → bSegment(E, C') → eSegment(C', C) → fPolygon(C', C, 4) → poly1, g, h, i, j, F, GPolygon(C, E, 4) → poly2, k, l, m, n, H, IPolygon(E, C', 4) → poly3, p, q, r, s, J, KMidpoint(E, J) → LOrthogonalLine(L, i) → tOrthogonalLine(L, t) → a_1Intersect(a_1, s) → MIntersect(t, r) → NIntersect(a_1, q) → OIntersect(t, e) → PPolygon(M, L, N, K) → poly4, m_1, l_1, n_1, k_1Polygon(L, N, J, O) → poly5, l_2, n_2, j_1, oPolygon(L, P, C', O) → poly6, l_3, p_1, c', o_1Polygon(P, L, M, E) → poly7, p_2, l_4, m_2, e_1Vector(L, C) → uVector(L, F) → vVector(L, C') → wVector(L, G) → u_1Centroid(poly4) → QCentroid(poly5) → RCentroid(poly6) → SCentroid(poly7) → TTranslate(T, w) → T'Translate(S, u) → S'Translate(R, v) → R'Translate(Q, u_1) → Q'Segment(Q, Q') → b_1Segment(R, R') → c_1Segment(S, S') → d_1Segment(T, T') → f_1Point(b_1) → UPoint(c_1) → VPoint(d_1) → WPoint(f_1) → ZVector(Q, U) → v_1Vector(R, V) → w_1Vector(S, W) → g_1Vector(T, Z) → h_1Translate(L, w_1) → L'Translate(N, w_1) → N'Translate(J, w_1) → J'Translate(O, w_1) → O'Polygon(L', N', J', O') → poly5', l', n', j', o'Translate(M, v_1) → M'Translate(L, v_1) → L'_1Translate(N, v_1) → N'_1Translate(K, v_1) → K'Polygon(M', L'_1, N'_1, K') → poly4', m', l'_1, n'_1, k'Translate(L, g_1) → L'_2Translate(P, g_1) → P'Translate(C', g_1) → C''Translate(O, g_1) → O'_1Polygon(L'_2, P', C'', O'_1) → poly6', l'_2, p', c'', o'_1Translate(P, h_1) → P'_1Translate(L, h_1) → L'_3Translate(M, h_1) → M'_1Translate(E, h_1) → E'Polygon(P'_1, L'_3, M'_1, E') → poly7', p'_1, l'_3, m'_1, e'Midpoint(H, C) → A_1Midpoint(C, G) → B_1Segment(A_1, B_1) → i_1Point(i_1) → C_1Vector(A_1, C_1) → q_1Translate(poly2, q_1) → poly2'