
Fourbar Mechanism Velocity and Acceleration Diagrams
Loading the math board and drawing, please wait…
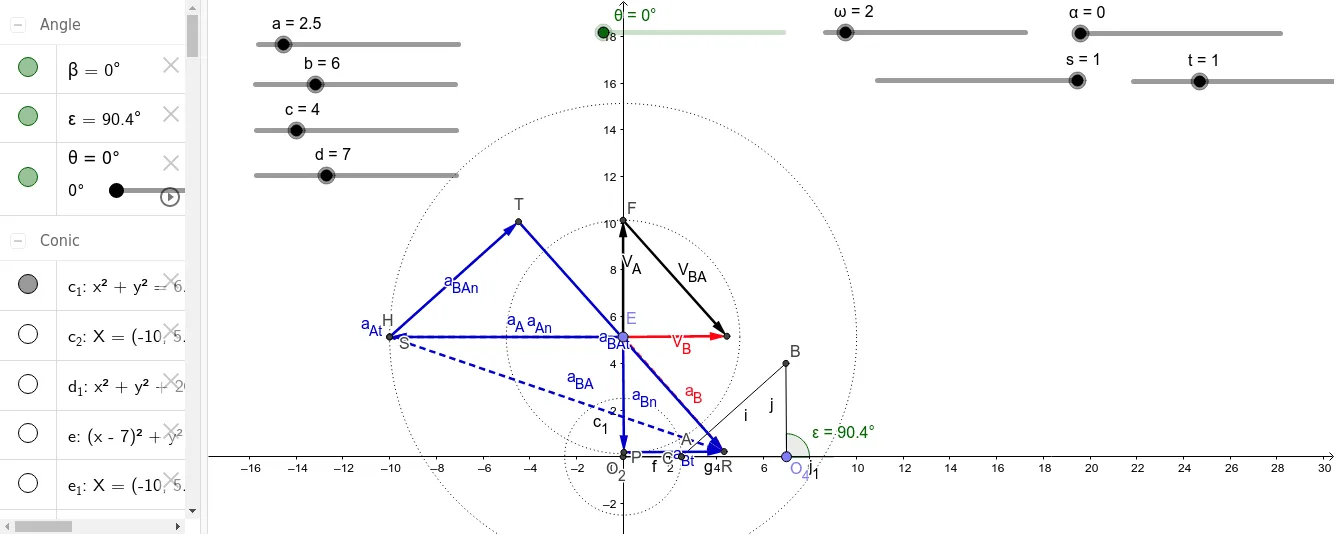
This example demonstrates the velocity and acceleration diagrams of a fourbar mechanism, providing a dynamic visualization of the motion characteristics. Key mathematical concepts include vectors, angles, and rotation. GeoGebra commands such as Intersect, Rotate, Angle, Segment, and Point are used in construction. Suitable for mechanical engineering and mathematics education, particularly for students and teachers studying mechanism kinematics.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → O_2Intersect(c_1, xAxis, 2) → CRotate(C, θ, O_2) → AAngle(C, O_2, A) → βSegment(O_2, A) → fPoint(Circle[O_2, d]) → O_4Segment(O_2, O_4) → gCircle(A, b) → hIntersect(e, h, 2) → BSegment(A, B) → iSegment(B, O_4) → jPoint(yAxis) → EOrthogonalLine(E, f) → kCircle(E, Vs) → pIntersect(p, k, 2) → FVector(E, F) → V_AOrthogonalLine(F, i) → lOrthogonalLine(E, j) → mIntersect(l, m) → GVector(E, G) → V_BVector(F, G) → V_{BA}Line(E, f) → nCircle(E, an2) → qIntersect(q, n, 1) → HVector(E, H) → a_{An}OrthogonalLine(H, a_{An}, xOyPlane) → f_1Circle(H, at2) → d_1Intersect(f_1, d_1, 2) → JLine(J, i) → g_1Point(Circle[O_4, 2]) → MSegment(O_4, M) → j_1Angle(M, O_4, B) → εDistance(E, G) → distanceEGDistance(F, G) → distanceFGDistance(E, F) → distanceEFDistance(O_2, A) → distanceBC'Distance(E, H) → distanceEHCircle(J, an3, xOyPlane) → e_1Intersect(g_1, e_1, 1) → NVector(J, N) → w_1OrthogonalLine(N, w_1, xOyPlane) → k_1Line(E, j) → l_1Circle(E, an4) → p_1Intersect(p_1, l_1, 2) → PIntersect(p_1, l_1, 1) → QVector(E, P) → a_{Bn}OrthogonalLine(P, a_{Bn}, xOyPlane) → m_1Intersect(k_1, m_1) → RVector(P, R) → a_{Bt}OrthogonalLine(N, w_1, xOyPlane) → s_1Vector(E, R) → a_BIntersect(f_1, d_1, 2) → SVector(H, S) → a_{At}Vector(E, S) → a_ALine(S, i) → a_1Circle(S, an3, xOyPlane) → c_2Intersect(a_1, c_2, 1) → TVector(S, T) → a_{BAn}OrthogonalLine(T, a_{BAn}, xOyPlane) → q_1Vector(T, R) → a_{BAt}Vector(S, R) → a_{BA}Distance(T, R) → distanceTRDistance(P, R) → distancePRDistance(E, H) → oDistance(H, S) → distanceHSDistance(H, T) → distanceHTDistance(T, R) → rDistance(E, P) → distanceEPDistance(P, R) → uDistance(C, B) → distanceCBCircle(T, at3, xOyPlane) → r_1Circle(P, at4) → t_1Distance(R, T) → distanceRTDistance(T, R) → vDistance(R, T) → wDistance(E, H) → b_1Distance(H, S) → n_1Distance(S, T) → distanceSTDistance(T, R) → o_1Distance(E, P) → u_1Distance(P, R) → v_1Distance(S, R) → distanceSRDistance(E, S) → distanceESDistance(E, R) → distanceERDistance(O_2, C) → distanceO2C