
Exploring Dandelin Spheres
Loading the math board and drawing, please wait…
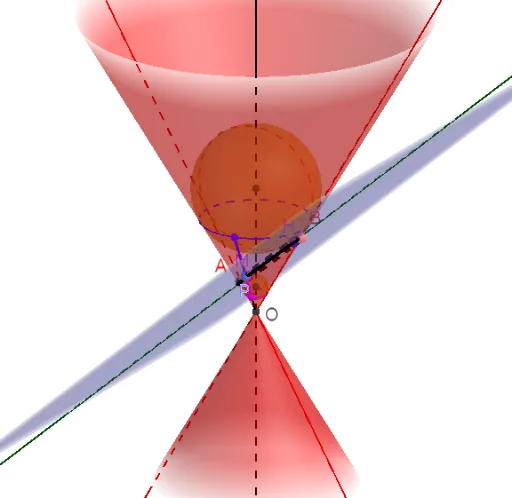
This example demonstrates the concept of Dandelin spheres, an important concept in coordinate geometry used to explain the properties of hyperbolas. By constructing the intersection of a cone, a plane, and spheres, the geometric properties of hyperbolas can be visually understood. The example uses GeoGebra commands such as InfiniteCone, Plane, IntersectPath, Circle, and Sphere, suitable for high school mathematics education and learning.
GeoGebra Commands & Parameters
InfiniteCone((0, 0, 0), zAxis, α) → aAxes(a) → d, e, fRotate(f, (-α), yAxis) → f'_1Point(f'_1) → ARotate(f, α, yAxis) → f'Point(f') → BPlane(A, B_1, B) → bIntersectPath(b, a) → cAxes(c) → i, jAngularBisector(f', i) → b2, b1Center(a) → OVector(O, B) → vOBAngle(Vector[A, B], Vector[A, O]) → βVector(O, A) → vOARotate(vOA, β / 2, A, k) → vOA'Angle(Vector[B, A], Vector[O, B]) → α1Rotate(vOB, α1 / 2, B, k) → vOB'Ray(B, B') → gIntersect(f, b1) → GOrthogonalLine(G, i, k) → hIntersect(i, h) → HCircle(G, H, k) → pSphere(G, H) → lRay(A, A') → mIntersect(f, b2) → LOrthogonalLine(L, i, k) → nIntersect(i, n) → MCircle(L, M, k) → sPoint(c) → PLine(O, P) → a_1Segment(M, P) → b_1Segment(P, H) → e_1Sphere(L, M) → l'OrthogonalLine(L, f'_1, k) → qOrthogonalLine(G, f'_1, k) → rIntersect(f'_1, r) → CIntersect(q, f'_1) → DCircle(f, C) → tCircle(f, D) → c_1Line(O, P) → d_1Intersect(d_1, c_1) → E,Intersect(d_1, t) → F,Segment(P, F) → f_1Segment(E, P) → g_1Segment(O, E) → h_1
AI Drawing Prompt Reference
Create a Dandelin spheres model for a hyperbola. Start by drawing a cone, then a plane intersecting the cone to form a hyperbola. Construct two Dandelin spheres that are tangent to the asymptotes of the hyperbola. Finally, draw the geometric properties of the hyperbola using the centers and points of tangency of the spheres, including asymptotes, foci, and vertices.
The prompt above was compiled from the original drawing commands and is for reference only.