
Dynamic Proof of SSS Congruence Theorem
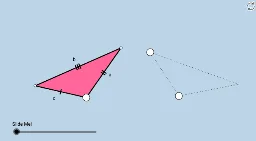
Loading the math board and drawing, please wait…
This example demonstrates the dynamic proof of the Side-Side-Side (SSS) Congruence Theorem for triangles. It involves core mathematical concepts such as triangle congruence criteria and geometric transformations (reflection, rotation, translation). The construction utilizes GeoGebra commands like Circle, Intersect, Segment, Polygon, Point, Line, Angle, Dilate, Vector, Translate, Rotate, Mirror, and Ray. It is suitable for high school mathematics students and teachers to understand and teach the SSS congruence theorem.
GeoGebra Commands & Parameters
Circle(A, a) → dIntersect(d, e) → B, CCircle(C, b) → fSegment(A, C) → gCircle(A, c) → kIntersect(k, f) → F, G, ,Segment(C, F) → hSegment(F, A) → iPolygon(A, C, F) → poly1, f_1, a_1, c_1Circle(D, i) → pPoint(p) → ESegment(D, E) → nCircle(D, g) → qCircle(E, h) → rIntersect(q, r, 2) → HSegment(D, H) → sSegment(H, E) → tLine(A, n) → g_1Point(g_1) → IAngle(I, A, F) → αDilate(A, If[0 < o ≤ 1, 1 - o, 0], D) → A'Vector(A, A') → uTranslate(F, u) → F'Translate(A, u) → A'_1Segment(F', A'_1) → i'Rotate(F', If[1 < o ≤ 2, ((-(o - 1)) * α), (-α)], D) → F''Rotate(A'_1, If[1 < o ≤ 2, ((-(o - 1)) * α), (-α)], D) → JSegment(F'', J) → i''Dilate(A, If[2 < o ≤ 3, 3 - o, 0], D) → A'_2Vector(A, A'_2) → vTranslate(A, v) → A'_3Translate(C, v) → C'Segment(A'_3, C') → g'Line(D, g) → h_1Point(h_1) → KAngle(H, D, K) → βRotate(A'_3, If[3 < o ≤ 4, ((-(o - 3)) * β), (-β)], D) → LRotate(C', If[3 < o ≤ 4, ((-(o - 3)) * β), (-β)], D) → C''Segment(L, C'') → g''Line(C, t) → i_1Point(i_1) → MAngle(M, C, F) → γDilate(C, If[4 < o ≤ 5, 5 - o, 0], C'') → C'_1Vector(C, C'_1) → wTranslate(C, w) → C'_2Translate(F, w) → F'_1Segment(C'_2, F'_1) → h'Rotate(C'_2, If[5 < o ≤ 6, ((-(o - 5)) * γ), (-γ)], C'') → NRotate(F'_1, If[5 < o ≤ 6, ((-(o - 5)) * γ), (-γ)], C'') → OSegment(N, O) → h''Polygon(D, C'', E) → poly2, e_1, d_1, c''Dilate(A, If[(6 * 0.5) < o ≤ 7.5, 7.5 - o, 0], D) → A'_4Vector(A, A'_4) → u_1Translate(A, u_1) → A'_5Translate(C, u_1) → C'_3Translate(F, u_1) → F'_2Polygon(A'_5, C'_3, F'_2) → poly1', f'_2, a'_5, c'_3Rotate(A'_5, If[7.5 < o ≤ 8.5, ((-(o - 7.5)) * γ), (-γ)], D) → PRotate(C'_3, If[7.5 < o ≤ 8.5, ((-(o - 7.5)) * γ), (-γ)], D) → QRotate(F'_2, If[7.5 < o ≤ 8.5, ((-(o - 7.5)) * γ), (-γ)], D) → RPolygon(P, Q, R) → poly1'', r_1, p_1, q_1Line(F, C) → j_1Mirror(A, j_1) → A'_6Mirror(C, j_1) → C'_4Mirror(F, j_1) → F'_3Polygon(A'_6, C'_4, F'_3) → poly1'_1, f'_3, a'_6, c'_4Point(j_1) → SPoint(j_1) → TRay(C'_4, T) → k_1Ray(F'_3, S) → l_1Segment(A'_6, F'_3) → m_1Segment(A'_6, C'_4) → n_1