
Cube Geometry: Shortest Path Between Points - A Net Copy
Loading the math board and drawing, please wait…
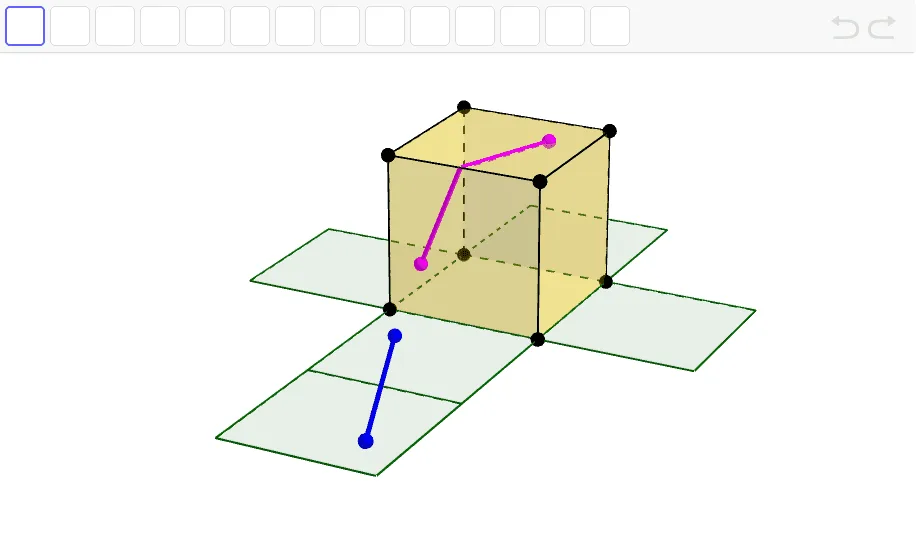
① This applet demonstrates the shortest path between two points on adjacent faces of a cube, shown simultaneously on the 3D cube and its net (unfolded surface), making the correspondence between the 3D path and its 2D straight-line representation clear. ② Core mathematical concepts include surface shortest paths in solid geometry, cube nets, symmetry, and the principle that the shortest path on a surface becomes a straight line when unfolded. ③ Construction details: The cube is created using the Cube command; points are placed on faces with Point and PointIn; intersections with edges are computed via Intersect and IntersectPath; path segments are drawn with Segment; faces are constructed using Polygon and Plane; the net is generated as a copy to visualize the path. ④ Suitable for high school to early university students learning solid geometry, optimization of paths on surfaces, and the use of nets to solve 3D problems.
GeoGebra Commands & Parameters
Intersect(yAxis, zAxis) → APoint(xAxis) → BPoint(Circle[B, Distance[A, B], Segment[A, B]]) → CCube(A, B, C) → a, D, faceCDHG, faceEFGH, edgeAD, edgeAB, edgeBC, edgeCD, edgeAE, edgeDH, edgeEH, edgeEF, E, edgeBF, edgeFG, edgeCG, edgeGH, F, G, H, faceABCD, faceADHE, faceABFE, faceBCGFPointIn(faceEFGH) → IPointIn(faceABFE) → JOrthogonalPlane(J, edgeEF) → bOrthogonalPlane(I, edgeEF) → cIntersect(edgeEF, b) → KIntersect(edgeEF, c) → LOrthogonalPlane(J, edgeBF) → dIntersectPath(c, d) → eOrthogonalPlane(I, edgeFG) → f_1IntersectPath(f_1, d) → gIntersect(e, faceABFE) → MSegment(J, M) → hSegment(M, L) → iSegment(L, I) → jVector(L, K) → uSegment(J, N) → kSegment(N, I) → lPolygon(B, A, 4, xOyPlane) → poly1, m, n, p, q, f, PPolygon(P, f, 4, xOyPlane) → poly2, r, s, t, a_1, O, QPolygon(A, D, 4, xOyPlane) → poly3, b_1, c_1, d_1, e_1, R, SPolygon(C, B, 4, xOyPlane) → poly4, g_1, h_1, i_1, j_1, T, UPolygon(D, C, 4, xOyPlane) → poly5, k_1, l_1, m_1, n_1, V, WCircle(edgeAB, J) → q_1IntersectIntersect(xOyPlane, q_1) → C_1, D_1Circle(edgeEF, I) → p_1Plane(A, E, F) → oIntersect(o, p_1) → Z, A_1Circle(edgeAB, A_1) → r_1Intersect(xOyPlane, r_1) → B_1, E_1Segment(D_1, E_1) → s_1