
Comparing Rates of Change in a Car Race
Loading the math board and drawing, please wait…
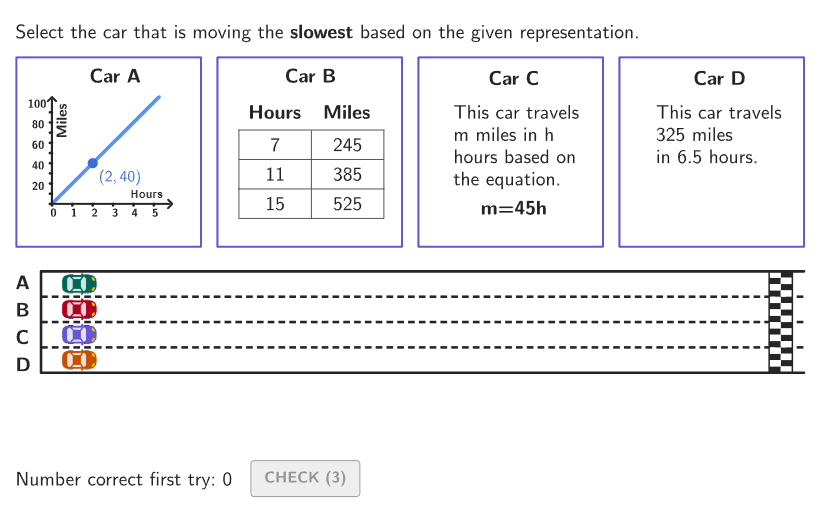
This example demonstrates how to visualize the position of cars in a race using different speed representations. It focuses on the concept of slope as a measure of rate of change in linear relationships. Key mathematical concepts include linear functions, slope comparison, and coordinate geometry. The construction uses GeoGebra commands like RandomUniform, Sequence, and Polygon to create the race track and car models. Suitable for grades 6-8 for algebra and function practice, ideal for classroom activities and online learning resources.
GeoGebra Commands & Parameters
RandomUniform(0, 0.99, 200) → allRandomSeeds, {0.07536995706471185, 0.32824398293471024, 0.5405278112233036, 0.6649148474939078, 0.5006162004100416, 0.7149908206683631, 0.888918252052941, 0.8786544653798103, 0.10978001909606723, 0.6298269886342113, 0.9498566092712807, 0.9279592129695333, 0.6174705258993755, 0.1551642949034372, 0.2957008027515774, 0.05758673623316867, 0.9001759058417332, 0.19903558280325603, 0.7294353040385582, 0.6914133513232606, 0.9701593479656597, 0.8559646729748696, 0.3761454681992267, 0.17980763395486749, 0.02932263874741608, 0.5113984128222984, 0.2576343850162359, 0.9716646786294414, 0.16366187698215062, 0.9045126101951195, 0.4333801691474773, 0.423603190732944, 0.026508621833590058, 0.923881330036718, 0.8721936337858348, 0.07584882750367412, 0.15100525293034534, 0.26236404698933385, 0.559786061134826, 0.28853675021938935, 0.7692067463582213, 0.5416183292026325, 0.007993882608907925, 0.8035620506347639, 0.7168321728520424, 0.9728853970986978, 0.8816316300887643, 0.20569143162605644, 0.19900726682394748, 0.42912425367352064, 0.5088565020597612, 0.1624206440395982, 0.5833455624976838, 0.3441846712064137, 0.5705277623525934, 0.4650211251006965, 0.7724085334088369, 0.647512665621895, 0.1633313939072731, 0.4433659451547565, 0.2079667183935607, 0.9178719518767109, 0.9104141836310834, 0.3044590179054461, 0.5045513745448905, 0.7067424908083919, 0.03193487397797327, 0.5591131547715676, 0.5995426273831705, 0.8914230819498179, 0.12628852066181256, 0.24293143017971278, 0.18148326635593448, 0.3894167855599936, 0.09079771225720888, 0.05664258956095468, 0.647438218642499, 0.189419355316947, 0.59838902182481, 0.09692592292940654, 0.15403791302935002, 0.13015702156358225, 0.46418491411457735, 0.9421315773144102, 0.6553499707037717, 0.20643722711579168, 0.823041357000883, 0.2177619364693272, 0.963916588739453, 0.38207637628196206, 0.035847723816624905, 0.6242259188186552, 0.21917631131623364, 0.24186111993750073, 0.16888120411406188, 0.8642122064813994, 0.52005675455585, 0.6393754614789219, 0.31666907278532364, 0.2190485605325656, 0.6157810630287772, 0.8243928931450714, 0.17466271074517734, 0.8126237248647271, 0.5908742198177606, 0.022583999788699814, 0.9135632709365417, 0.2378447781637362, 0.33698573375064605, 0.6115315313389861, 0.24236463414097356, 0.5141865441726815, 0.9754645605616517, 0.590471667910253, 0.9120907873772066, 0.4756617439715817, 0.37062664701241566, 0.5267961101208722, 0.6768042258775492, 0.506498713368133, 0.5543500128506502, 0.9301518450200118, 0.932749501505285, 0.37696097390219485, 0.4380127628160008, 0.33496607463587275, 0.5304705981178562, 0.8840759756154087, 0.9078572364218642, 0.49440141859885084, 0.8684025848163209, 0.3615624346390591, 0.3146203386934635, 0.8231115423689915, 0.7297878958846665, 0.9499546707376534, 0.5177126311927898, 0.7527202903779816, 0.4378047853926212, 0.8818182829735262, 0.8083600827093506, 0.2526877468129239, 0.43651963610892097, 0.3980361853912613, 0.48494053565826073, 0.3601539337535182, 0.03768754829359946, 0.18941502495523055, 0.20725291114596148, 0.7254666654060017, 0.5855247960374899, 0.6533212681927846, 0.3746504807699598, 0.6054024019639545, 0.6133639103269122, 0.9477023991497175, 0.07585027977748975, 0.7535792771349589, 0.07757696012773511, 0.294683091303444, 0.6657994848006024, 0.027239352286472774, 0.5253144359153514, 0.43294736577934273, 0.8672348252926271, 0.0714421201675007, 0.053457071132529455, 0.5123268815096389, 0.8115151866049974, 0.8957643601530497, 0.5067147268550152, 0.6954118084937855, 0.7349375586863393, 0.40484135149891726, 0.24303116088779542, 0.16958514245000209, 0.9730658986690702, 0.012512169579103383, 0.33436588332083994, 0.058652175648664984, 0.28660720703498044, 0.019947809328005366, 0.3405235106172481, 0.8761964754292657, 0.8880634142394255, 0.8809419989080765, 0.7829883382738959, 0.842939660462526, 0.42876796760368263, 0.9125367005827982, 0.7946965793860303, 0.15771667379396972, 0.47098456878771006, 0.3963306589058199, 0.9203404500026036, 0.1361993165804028, 0.49950136658915695, 0.22518499387510751, 0.6201484529369897, 0.553210415481495}Sequence(xMin + px16 + (n * (boxWidth + px16)), n, 0, 4) → xStarts, {-1.7447999999999997, 8.1189, 17.982599999999998, 27.8463, 37.71}makeBox((xStarts(1), dimensions(4) - (56 * pixelsH)), boxWidth, (boxRatio * (dimensions(4) - dimensions(2)))) → car1BoxTake(allRandomSeeds, randIndex, randIndex + numRandoms - 1) → currentRandomSeedsIf(randomSpeed ≟ 1, "fastest", "slowest") → textRandomSpeedSequence((A * 5), A, 4, 12) → possibleRates, {20, 25, 30, 35, 40, 45, 50, 55, 60}Element(possibleRates, 1 + floor((currentRandomSeeds(1) * Length[possibleRates]))) → randomRate1Element(Remove[possibleRates, {randomRate1}], 1 + floor((currentRandomSeeds(2) * (Length[possibleRates] - 1)))) → randomRate2Element(Remove[possibleRates, {randomRate1, randomRate2}], 1 + floor((currentRandomSeeds(3) * (Length[possibleRates] - 2)))) → randomRate3Element(Remove[possibleRates, {randomRate1, randomRate2, randomRate3}], 1 + floor((currentRandomSeeds(4) * (Length[possibleRates] - 3)))) → randomRate4IndexOf(Max[{randomRate1, randomRate2, randomRate3, randomRate4}], {randomRate1, randomRate2, randomRate3, randomRate4}) → maxIndexIndexOf(Min[{randomRate1, randomRate2, randomRate3, randomRate4}], {randomRate1, randomRate2, randomRate3, randomRate4}) → minIndexIf(randomSpeed ≟ 1, maxIndex, minIndex) → correctIndexCorner(5) → layoutAppSizePolygon({(-4.5, 105), (5.9, 105), (5.9, -10), (-4.5, -10)}) → graphAreaVerticalText("Miles") → labelYSegment((0, 00), (0, 105)) → yAxisSegSegment((0, 0), (5.9, 0)) → xAxisSegZip(n + "\vphantom{|}&" + (m) + "\vphantom{|}\\\hline", n, randomPointsX2, m, randomPointsY2) → textTable2ListCorner(labelX, 1) → PointBottomCasesPolygon({(xTrackStart, yTrackStart), (xTrackStart, yTrackEnd), (xTrackEnd, yTrackEnd), (xTrackEnd, yTrackStart)}) → trackPolygonSequence(Segment[(xTrackStart, yTrackEnd + (n * (yTrackStart - yTrackEnd) / 4)), (xTrackEnd, yTrackEnd + (n * (yTrackStart - yTrackEnd) / 4))], n, 1, 3) → trackLinesSequence((xTrackStart + 1, yTrackStart - (((2 * n) - 1) * (yTrackStart - yTrackEnd) / 8)), n, 1, 4) → carStartSequence((xTrackEnd + 3, yTrackEnd + (((2 * n) - 1) * (yTrackStart - yTrackEnd) / 8)), n, 1, 4) → carEndOriginalZip(A + ((750 / 800 * (xMax - xMin)), 0), A, carStart) → carEndZip(A + (Min[1, (animationSlider * R / Min[randomRates])] * (B - A)), A, carStart, B, carEnd, R, randomRates) → movingPointsSequence((xTrackEnd - 10, yTrackStart - (((2 * n) - 1) * (yTrackStart - yTrackEnd) / 8)), n, 1, 4) → carRibbonPointsSequence(Sequence[Polygon[{(xTrackEnd - ((k + 1) * finishBoxWidth), yTrackStart - (((2 * n) + k) * finishBoxHeight)), (xTrackEnd - ((k + 1) * finishBoxWidth), yTrackStart - (((2 * n) + 1 + k) * finishBoxHeight)), (xTrackEnd - ((k + 2) * finishBoxWidth), yTrackStart - (((2 * n) + 1 + k) * finishBoxHeight)), (xTrackEnd - ((k + 2) * finishBoxWidth), yTrackStart - (((2 * n) + k) * finishBoxHeight))}], n, 0, 7], k, 0, 1) → finishLineBlack, {{3.5582092503764216, 3.558209250375967, 3.558209250375967, 3.5582092503764216, 3.558209250375512, 3.5582092503764216, 3.558209250375512, 3.558209250377331}, {3.558209250375967, 3.558209250375967, 3.558209250375967, 3.5582092503764216, 3.5582092503764216, 3.5582092503764216, 3.5582092503764216, 3.5582092503764216}}Sequence(Sequence[Polygon[{(xTrackEnd - ((k + 2) * finishBoxWidth), yTrackStart - (((2 * n) - k + 1) * finishBoxHeight)), (xTrackEnd - ((k + 2) * finishBoxWidth), yTrackStart - (((2 * n) + 2 - k) * finishBoxHeight)), (xTrackEnd - ((k + 1) * finishBoxWidth), yTrackStart - (((2 * n) + 2 - k) * finishBoxHeight)), (xTrackEnd - ((k + 1) * finishBoxWidth), yTrackStart - (((2 * n) - k + 1) * finishBoxHeight))}], n, 0, 7], k, 0, 1) → finishLineWhite, {{3.5582092503764216, 3.5582092503764216, 3.5582092503768763, 3.5582092503768763, 3.5582092503764216, 3.5582092503764216, 3.5582092503764216, 3.558209250375512}, {3.5582092503764216, 3.5582092503764216, 3.5582092503768763, 3.558209250375967, 3.5582092503764216, 3.558209250375512, 3.558209250377331, 3.558209250375512}}Sort(randomRates) → randomRatesSortedZip(IndexOf[n, randomRatesSorted], n, randomRates) → indexPlaceCorner(textSize, 4) → PointSizeA_{start}Vector(PointSizeA_{start}, PointSizeA) → pointSizeAmakeBox((xStarts(2), dimensions(4) - (56 * pixelsH)), boxWidth, (boxRatio * (dimensions(4) - dimensions(2)))) → car2BoxmakeBox((xStarts(3), dimensions(4) - (56 * pixelsH)), boxWidth, (boxRatio * (dimensions(4) - dimensions(2)))) → car3BoxmakeBox((xStarts(4), dimensions(4) - (56 * pixelsH)), boxWidth, (boxRatio * (dimensions(4) - dimensions(2)))) → car4BoxElement({"Car A", "Car B", "Car C", "Car D"}, correctIndex) → correctCarSequence((xTrackEnd - 5.8, yTrackStart - (((2 * n) - 1) * (yTrackStart - yTrackEnd) / 8)), n, 1, 4) → CarSpeedPointsIf(randomSpeed ≟ 1, minIndex, maxIndex) → incorrectIndexSequence(Text[n, (n - 0.175, -2.5), true, true], n, 0, 5) → xNumsZip(Vector[Midpoint[CarPointA, CarPointC], n], n, movingPoints) → vectorCarsTranslate(carAGreen, vectorCars(1)) → carAMovingTranslate(carCPurple, vectorCars(3)) → carCMovingTranslate(carDOrange, vectorCars(4)) → carDMovingTranslate(carBRed, vectorCars(2)) → carBMovingSequence(Segment[(n, 0), (n, -1.5)], n, 0, 5) → xAxisSegsSequence(Text[(20 * n), ((-If[n < 5, 1.1, 1.3]), (20 * n) + 4), true, true], n, 1, 5) → yNumsIf(showanswer ∨ showsolution ∨ validate ∧ correct, If[correctIndex ≟ 1, "#008475", selectedIndex ≟ 1, "#B00020", "#252525"], validate ∧ selectedIndex ≟ 1, "#B00020", selectedIndex ≟ 1, "#6557D2", "#252525") → car1ColorIf(showanswer ∨ showsolution ∨ validate ∧ correct, If[correctIndex ≟ 2, "#008475", selectedIndex ≟ 2, "#B00020", "#252525"], validate ∧ selectedIndex ≟ 2, "#B00020", selectedIndex ≟ 2, "#6557D2", "#252525") → car2ColorIf(showanswer ∨ showsolution ∨ validate ∧ correct, If[correctIndex ≟ 3, "#008475", selectedIndex ≟ 3, "#B00020", "#252525"], validate ∧ selectedIndex ≟ 3, "#B00020", selectedIndex ≟ 3, "#6557D2", "#252525") → car3ColorIf(showanswer ∨ showsolution ∨ validate ∧ correct, If[correctIndex ≟ 4, "#008475", selectedIndex ≟ 4, "#B00020", "#252525"], validate ∧ selectedIndex ≟ 4, "#B00020", selectedIndex ≟ 4, "#6557D2", "#252525") → car4ColorPolyLine({(xTrackEnd, yTrackStart), (xTrackStart, yTrackStart), (xTrackStart, yTrackEnd), (xTrackEnd, yTrackEnd)}) → trackBorderZip(Vertex[n, 3], n, {car1Box, car2Box, car3Box, car4Box}) → PointsValidationVector(FeedbackB, PointsValidation(correctIndex)) → correctVectVector(FeedbackB, PointsValidation(selectedIndex)) → incorrectVectTranslate(picCheck, correctVect) → correctPicTranslate(picCross, incorrectVect) → incorrectPicPolygon({(xTrackEnd - (1 * finishBoxWidth), yTrackEnd), (xTrackEnd - (3 * finishBoxWidth), yTrackEnd), (xTrackEnd - (3 * finishBoxWidth), yTrackStart), (xTrackEnd - (1 * finishBoxWidth), yTrackStart)}) → finishOutlineSequence(Segment[(0, (10 * n)), (-0.1, (10 * n))], n, 0, 9) → yAxisSegsSequence(x = xMin + (n * abs(xMax - xMin) / 4), n, 1, 4) → linesAlignment
AI Drawing Prompt Reference
Draw a car race scene showing four cars moving along a straight track to compare their speeds (rates of change). The graphic includes a coordinate plane with time (0-5) on the x-axis and distance (0-100) on the y-axis. A rectangular track area is shown with horizontal dividing lines. Four cars, colored green, red, purple, and orange, are represented as rectangles starting from the left and moving rightward at different random speeds. A checkered flag pattern appears at the finish line on the right. The image includes axis labels, tick marks, and a slider to control animation progress, displaying each car's current speed value.
The prompt above was compiled from the original drawing commands and is for reference only.