
Billiard-Table Geometry: Polygonal Piecewise Path Construction
Loading the math board and drawing, please wait…
In collections
Proofs Without Words
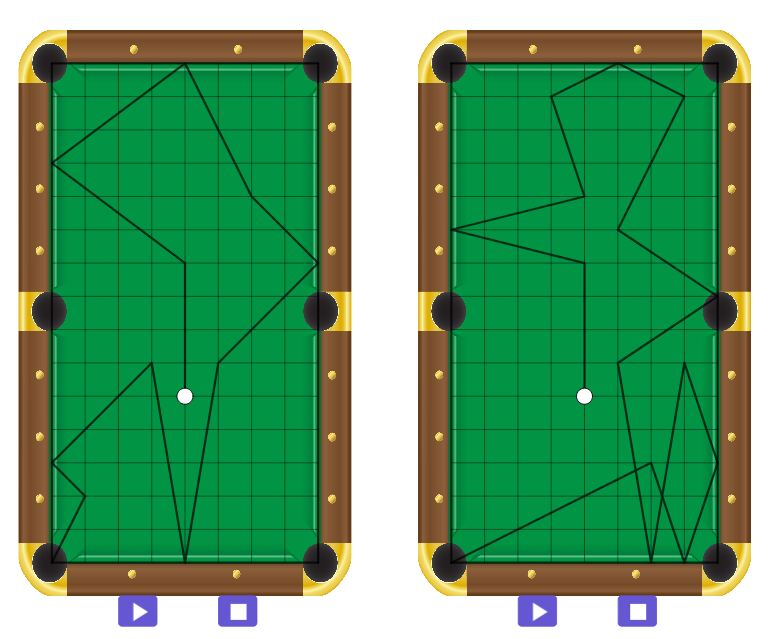
This example demonstrates a billiard-style motion path on a rectangular “table” region, where the ball’s travel is represented as a piecewise polyline produced by repeated geometric constructions (reflections/segment connections). It highlights core ideas from plane geometry, including segmented line/path building, point and segment construction, and an iterative/sequence-based generation of key points that form the overall trajectory. Construction highlights: Polygon is used to draw the table boundary, while PolyLine builds the resulting path segments; Sequence generates multiple points automatically for iterative steps (e.g., P1–P4, Q1–Q4 and other indexed points); Point objects mark all constructed vertices; additional geometric primitives (circles/lines such as c1, c2 and l, m, n, o, plus direction/auxiliary lines and vectors like l1, l2, q1–q4, L) control intersection locations and the orientation of successive segments. Suitable for high school to early undergraduate learners, and useful for teaching algorithmic geometry construction and iterative trajectory visualization.
GeoGebra Commands & Parameters
Polygon(P1, P2, P3, P4) → c1, l, m, n, oPolyLine(A, B, K, L, C, D, E, F, G, H, I, J) → pol1Sequence(Segment[Translate[P1, Vector[(k * Vector[P1, P4] / 15)]], Translate[P2, Vector[(k * Vector[P1, P4] / 15)]]], k, 1, 15) → l1Sequence(Segment[Translate[P1, Vector[(k * Vector[P1, P2] / 8)]], Translate[P4, Vector[(k * Vector[P1, P2] / 8)]]], k, 1, 8) → l2Polygon(Q1, Q2, Q3, Q4) → c2, q1, q2, q3, q4Point(q4) → OPoint(q3) → SPoint(q2) → VPoint(q1) → ZPoint(q2) → B_1Point(q1) → C_1PolyLine(M, N, Z, A_1, B_1, C_1, D_1, E_1, O, Q, R, S, T, U, V, W) → pol2Sequence(Segment[Translate[Q1, Vector[(k * Vector[Q1, Q4] / 15)]], Translate[Q2, Vector[(k * Vector[Q1, Q4] / 15)]]], k, 1, 15) → l4Sequence(Segment[Translate[Q1, Vector[(k * Vector[Q1, Q2] / 8)]], Translate[Q4, Vector[(k * Vector[Q1, Q2] / 8)]]], k, 1, 8) → l3Point(pol1, t1) → B1Point(pol2, t2) → B2
AI Drawing Prompt Reference
Draw a rectangular “table” using a polygon with four vertices. Construct a billiard-style piecewise linear trajectory inside the table by creating sequences of intermediate points obtained from translation steps along directions defined by the rectangle’s vertices, then connect those points in order to form a polyline path. Mark key constructed vertices as points and ensure the path is built from multiple segment chains that follow the same iterative construction idea along two different edge directions. Finally, add a second polyline that connects another set of iterated points near the opposite side of the rectangle, keeping the main endpoints visible so the two trajectories’ segment connections are clear.
The prompt above was compiled from the original drawing commands and is for reference only.