
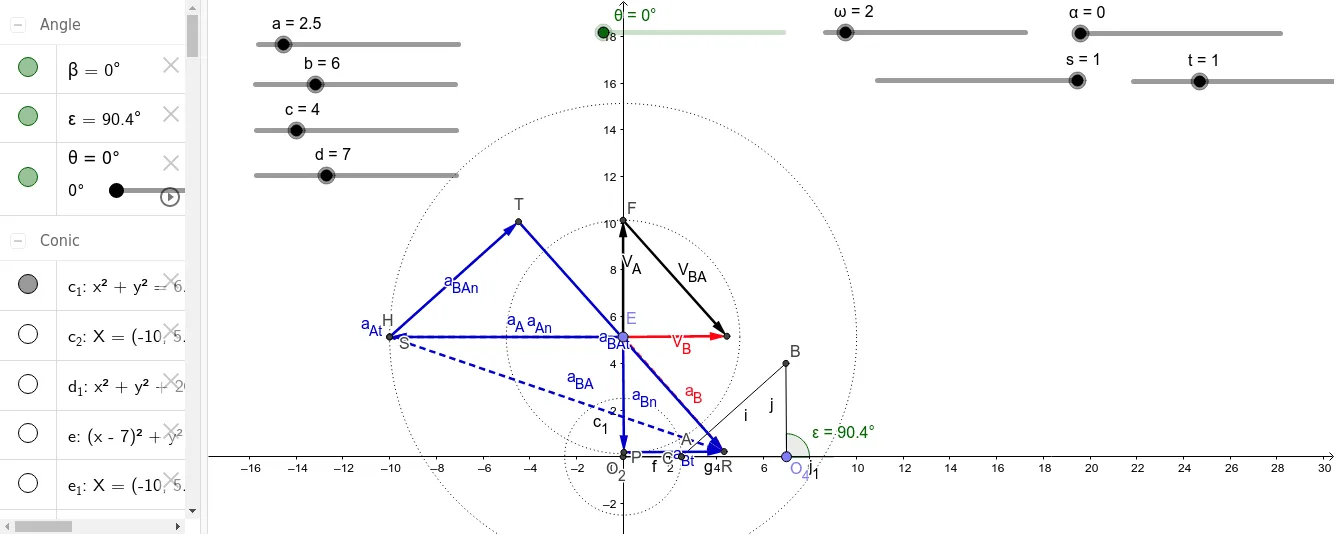
四杆机构的速度与加速度图解
几何画板及绘图内容加载中,请稍等……
本范例展示了四杆机构的速度和加速度图解,通过几何作图直观地展示了机构运动的动态特性。核心数学概念包括向量、角度和旋转。使用了GeoGebra中的Intersect、Rotate、Angle、Segment、Point等命令进行构造。适合机械工程和数学教育领域,特别是研究机构运动学的学生和教师。
GeoGebra 命令及参数
Intersect(xAxis, yAxis) → O_2Intersect(c_1, xAxis, 2) → CRotate(C, θ, O_2) → AAngle(C, O_2, A) → βSegment(O_2, A) → fPoint(Circle[O_2, d]) → O_4Segment(O_2, O_4) → gCircle(A, b) → hIntersect(e, h, 2) → BSegment(A, B) → iSegment(B, O_4) → jPoint(yAxis) → EOrthogonalLine(E, f) → kCircle(E, Vs) → pIntersect(p, k, 2) → FVector(E, F) → V_AOrthogonalLine(F, i) → lOrthogonalLine(E, j) → mIntersect(l, m) → GVector(E, G) → V_BVector(F, G) → V_{BA}Line(E, f) → nCircle(E, an2) → qIntersect(q, n, 1) → HVector(E, H) → a_{An}OrthogonalLine(H, a_{An}, xOyPlane) → f_1Circle(H, at2) → d_1Intersect(f_1, d_1, 2) → JLine(J, i) → g_1Point(Circle[O_4, 2]) → MSegment(O_4, M) → j_1Angle(M, O_4, B) → εDistance(E, G) → distanceEGDistance(F, G) → distanceFGDistance(E, F) → distanceEFDistance(O_2, A) → distanceBC'Distance(E, H) → distanceEHCircle(J, an3, xOyPlane) → e_1Intersect(g_1, e_1, 1) → NVector(J, N) → w_1OrthogonalLine(N, w_1, xOyPlane) → k_1Line(E, j) → l_1Circle(E, an4) → p_1Intersect(p_1, l_1, 2) → PIntersect(p_1, l_1, 1) → QVector(E, P) → a_{Bn}OrthogonalLine(P, a_{Bn}, xOyPlane) → m_1Intersect(k_1, m_1) → RVector(P, R) → a_{Bt}OrthogonalLine(N, w_1, xOyPlane) → s_1Vector(E, R) → a_BIntersect(f_1, d_1, 2) → SVector(H, S) → a_{At}Vector(E, S) → a_ALine(S, i) → a_1Circle(S, an3, xOyPlane) → c_2Intersect(a_1, c_2, 1) → TVector(S, T) → a_{BAn}OrthogonalLine(T, a_{BAn}, xOyPlane) → q_1Vector(T, R) → a_{BAt}Vector(S, R) → a_{BA}Distance(T, R) → distanceTRDistance(P, R) → distancePRDistance(E, H) → oDistance(H, S) → distanceHSDistance(H, T) → distanceHTDistance(T, R) → rDistance(E, P) → distanceEPDistance(P, R) → uDistance(C, B) → distanceCBCircle(T, at3, xOyPlane) → r_1Circle(P, at4) → t_1Distance(R, T) → distanceRTDistance(T, R) → vDistance(R, T) → wDistance(E, H) → b_1Distance(H, S) → n_1Distance(S, T) → distanceSTDistance(T, R) → o_1Distance(E, P) → u_1Distance(P, R) → v_1Distance(S, R) → distanceSRDistance(E, S) → distanceESDistance(E, R) → distanceERDistance(O_2, C) → distanceO2C