
赤经与赤纬:天球上的恒星位置与周年路径动画
几何画板及绘图内容加载中,请稍等……
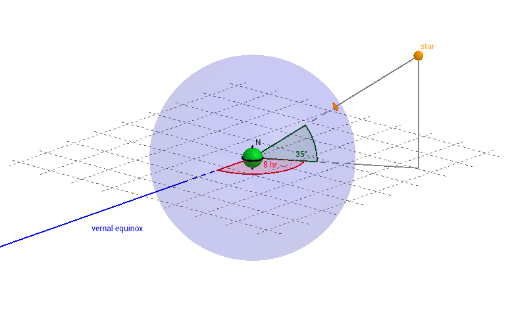
① 本范例通过三维动画直观展示恒星在天球上的位置如何由赤经(Right Ascension)和赤纬(Declination)两个坐标确定,并同时呈现太阳的周年视运动路径。② 核心数学概念包括球面坐标系统、三维空间中的向量与平面、椭圆的参数方程、旋转与平移变换,以及角度与弧度的度量。③ 作图要点:利用GeoGebra的Line、Vector、Ellipse、Translate、Sphere、Segment、Circle、Rotate、Angle、Surface、Intersect等命令构建天球、赤道面、黄道面、恒星位置标记及太阳轨道;通过滑块控制赤经、赤纬和日期,实现动态演示;涉及对象包括raval、ra、dec2、rc、erad、deccon、obliq、argperi、ecc、fecc、au、bsemi、asemi、day、daydeg、rr、Ecenter3、focus、bang、z1、vtrans、orbitbot、sunorbit、text1、text2、Ebot、eaxisbot、srad、Nbot、vobliq、equatorbot、Scenter3、Sunbot、solsticesbot、c、obliqdisplay、argpdisplay、Stardec、darksidebot等。④ 适合高中天文选修课、大学天文学入门或数学立体几何教学,帮助学生理解天球坐标与三维空间几何的关联。
GeoGebra 命令及参数
Line((6, 6, 0), zAxis) → decconVector((0, 0, 0), (0, 0, z1)) → vtransEllipse(((-2 * focus), 0, z1), (0, 0, z1), asemi, xOyPlane) → orbitbotTranslate(Rotate[Rotate[orbitbot, argperi - 90°, zAxis], (-obliq), yAxis], vtrans) → sunorbitSphere((0, 0, z1), erad) → EbotSegment((0, 0, z1 - (1.2 * erad)), (0, 0, z1 + (1.2 * erad))) → eaxisbotVector((0, 0, 0), (cos(obliq + π / 2), 0, sin(obliq + π / 2))) → vobliqCircle((0, 0, 0), erad, zAxis) → equatorbotRotate(Ecenter3 - (0, 0, z0), (-obliq), yAxis) → Scenter3Sphere(Scenter3, srad) → SunbotLine((-1, 0, z1), (1, 0, z1)) → solsticesbotAngle((x(Ecenter3) - (10 * sin(obliq)), y(Ecenter3), z0 + (10 * cos(obliq))), Ecenter3, (x(Ecenter3), y(Ecenter3), z0 + 10)) → obliqdisplayAngle((0, -10, z0), (0, 0, z0), ((10 * sin(argperi)), (-10 * cos(argperi)), z0), zAxis) → argpdisplaySurface((((((-1.02 * erad) * cos(j)) * cos(daydeg)) - ((((1.02 * erad) * sin(i)) * sin(j)) * sin(daydeg))) * cos((-obliq))) + ((z1 + (((1.02 * erad) * cos(i)) * sin(j))) * sin((-obliq))), (((-1.02 * erad) * cos(j)) * sin(daydeg)) + ((((1.02 * erad) * sin(i)) * sin(j)) * cos(daydeg)), ((-((((-1.02 * erad) * cos(j)) * cos(daydeg)) - ((((1.02 * erad) * sin(i)) * sin(j)) * sin(daydeg)))) * sin((-obliq))) + ((z1 + (((1.02 * erad) * cos(i)) * sin(j))) * cos((-obliq))), i, 0, (2 * π), j, 0, π / 2) → darksidebotSegment((0, -20, z1), (0, 0, 0)) → lineofnodesbotSegment(Stardec, (x(Stardec), y(Stardec), 0)) → decvlineSegment((0, 0, 0), (x(Stardec), y(Stardec), 0)) → dechlineSegment((0, 0, 0), Stardec) → declineAngle((0, -10, 0), (0, 0, 0), ((10 * cos(ra - 90°)), (10 * sin(ra - 90°)), 0), zAxis) → radispAngle(dechline, decline) → decdispSphere((0, 0, 0), 5) → celsphereIntersect(decline, celsphere) → celstar_1, celstar_2Circle(celstar_2, 0.2, decline) → celcircle