
Steffen Congruent Figures Dynamic Illustration
Loading the math board and drawing, please wait…
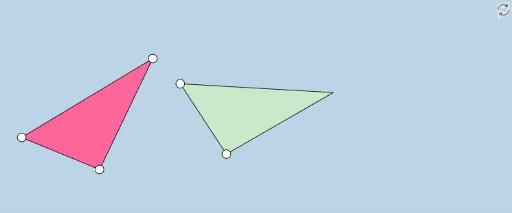
This example dynamically illustrates Steffen congruent figures, covering core concepts like congruence, translation, parametric curves, subtraction, optimization problems, and statistical characteristics. It utilizes commands such as Segment, Circle, Point, Angle, Rotate, Ray, Intersect, Line, Dilate, Vector, Polygon, Translate, If, Mirror in GeoGebra for construction. Suitable for high school mathematics students and educators exploring geometric transformations and optimization.
GeoGebra Commands & Parameters
Segment(A, B) → aSegment(B, C) → bSegment(C, A) → cCircle(D, (k * a)) → dPoint(d) → ESegment(D, E) → eCircle(E, (k * b)) → fAngle(A, B, C) → αRotate(D, α, E) → D'Angle(D, E, D') → βRay(E, D') → gIntersect(f, g, 1) → FAngle(C, A, B) → γRotate(E, (-γ), D) → E'Angle(E', D, E) → δRay(D, E') → hSegment(D, E') → iSegment(E', E) → jLine(E, D') → lLine(E, D') → nCircle(D, (k * c)) → pRay(D, E') → mIntersect(p, m, 1) → GSegment(E, G) → qSegment(D, G) → rDilate(D, If[0 < s ≤ 1, 1 - s], A) → D'_1Vector(D, D'_1) → uPolygon(A, C, B) → poly1, b_1, a_1, c_1Polygon(D, E, G) → poly2, g_1, d_1, e_1Translate(D, u) → D'_2Translate(E, u) → E'_1Translate(G, u) → G'Polygon(D'_2, E'_1, G') → poly2', g', d'_2, e'_1Vector(D, A) → vTranslate(D, v) → D'_3Translate(E, v) → E'_2Translate(G, v) → G'_1Polygon(D'_3, E'_2, G'_1) → poly2'_1, g'_1, d'_3, e'_2Segment(D'_1, G') → tSegment(E'_1, D'_1) → h_1Segment(A, G'_1) → i_1Segment(G'_1, E'_2) → j_1Segment(E'_2, A) → k_1Angle(C, A, E'_2) → εIf(ε > γ, ε - γ, γ - ε) → ζRotate(D'_3, If[1 < s ≤ 2, ((-(s - 1)) * ζ), (-ζ)], A) → HRotate(E'_2, If[1 < s ≤ 2, ((-(s - 1)) * ζ), (-ζ)], A) → IRotate(G'_1, If[1 < s ≤ 2, ((-(s - 1)) * ζ), (-ζ)], A) → JPolygon(H, I, J) → poly3, j_2, h_2, i_2Segment(A, J) → l_1Segment(A, I) → m_1Segment(I, J) → n_1Dilate(J, If[2 < s ≤ 3, 3 - s, 0], C) → J'Dilate(I, If[2 < s ≤ 3, 3 - s, 0], B) → I'Segment(I', J') → p_1Angle(A, I, J) → θAngle(D'_2, E'_1, G') → ιAngle(J, A, I) → λAngle(G', D'_1, E'_1) → μPolygon(A, J', I') → poly4, i', a_2, j'Segment(G'_1, E'_2) → q_1Segment(G', E'_1) → f_1Rotate(D'_3, ((s - 1) * ζ), A) → KRotate(D'_3, If[1 < s ≤ 2, ((s - 1) * ζ), ζ], A) → LRotate(E'_2, If[1 < s ≤ 2, ((s - 1) * ζ), ζ], A) → MRotate(G'_1, If[1 < s ≤ 2, ((s - 1) * ζ), ζ], A) → NPolygon(L, M, N) → poly5, n_2, l_2, m_2Dilate(M, If[2 < s ≤ 3, 3 - s, 0], B) → M'Dilate(N, If[2 < s ≤ 3, 3 - s, 0], C) → N'Segment(M', N') → r_1Polygon(A, M', N') → poly6, n', a_3, m'Angle(A, M', N') → οAngle(A, M, N) → ρSegment(A, M) → t_1Segment(M, N) → b_2Segment(A, N) → c_2Angle(B, A, C) → σAngle(G, E, D) → τAngle(N, M, A) → υAngle(N', M', A) → ϕLine(E, G) → s_1Mirror(D, q) → D'_4Mirror(E, q) → E'_3Mirror(G, q) → G'_2Polygon(D'_4, E'_3, G'_2) → poly2'_2, g'_2, d'_4, e'_3Segment(E, D'_4) → f_2Segment(D'_4, G) → g_2