
Rocket Trajectory
Loading the math board and drawing, please wait…
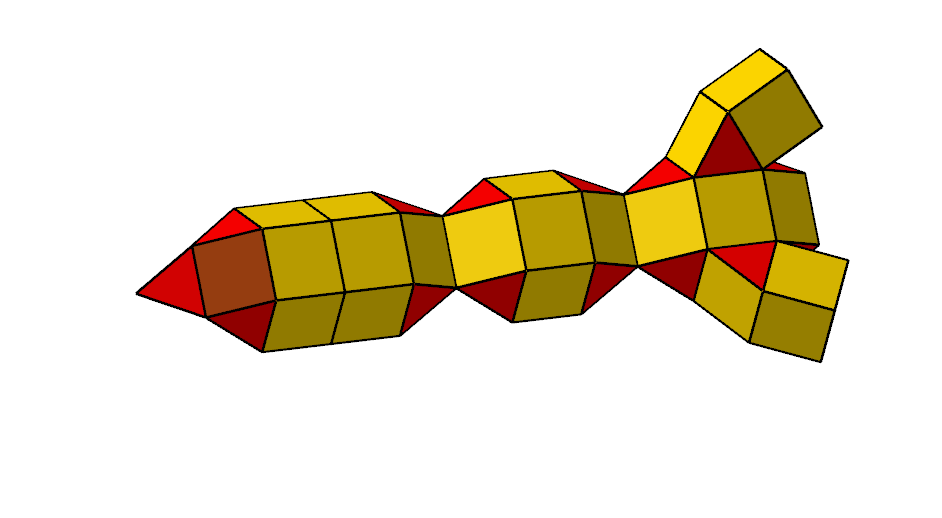
This example demonstrates the trajectory of a rocket. It involves key mathematical concepts such as functions, rotation, polygons, and circles. Using GeoGebra commands like Rotate, Polygon, and Circle, the trajectory of a rocket launch can be constructed. Suitable for high school or university mathematics education and learning.
GeoGebra Commands & Parameters
Rotate(A, 120°, xAxis) → A'Rotate(A', 120°, xAxis) → A''Polygon(A, A', A'') → wielokąt1, a'', a, a'Circle(A, 1, a'') → cPoint(xAxis) → BPoint(xAxis) → CCylinder(B, C, 1) → b, d, e, fIntersect(c, f) → D, E, ,Circle(A', 1, a'') → gIntersect(g, f) → F, G, ,Polygon(A, A', G, E) → wielokąt2, a_1, a'_1, g_1, e_1Rotate(E, 120°, xAxis) → E'Rotate(G, 120°, xAxis) → G'Rotate(E', 120°, xAxis) → E''Rotate(G', 120°, xAxis) → G''Polygon(G'', E, A) → wielokąt3, a_2, g'', e_2Polygon(G'', A, A'', E'') → wielokąt4, g''_1, a_3, a''_1, e''Polygon(E'', A'', G') → wielokąt5, g', e''_1, a''_2Polygon(A'', A', E', G') → wielokąt6, a''_3, a'_2, e', g'_1Polygon(G, E', A') → wielokąt7, a'_3, g_2, e'_1Polygon(E, H, K, G) → wielokąt8, e_3, h, k, g_3Polygon(E', I, L, G') → wielokąt9, e'_2, i, l, g'_2Polygon(M, G'', E'', J) → wielokąt10, m, g''_2, e''_2, jCircle(E, 1, a_2) → pLine(M, H) → nCircle(H, 1, n) → qIntersect(q, p) → N, O, ,Polygon(E, O, H) → wielokąt11, h_1, e_4, oPolygon(P, G'', M) → wielokąt12, m_1, p_1, g''_3Polygon(O, P, M, H) → wielokąt13, o_1, p_2, m_2, h_2Rotate(O, 90°, m_1) → O'Polygon(O', Q, R, S) → wielokąt14, o', q_1, r, sPolygon(O', P, O, Q) → wielokąt15, o'_1, p_3, o_2, q_2Polygon(Q, O, E, R) → wielokąt16, q_3, o_3, e_5, r_1Polygon(G'', S, R, E) → wielokąt17, g''_4, s_1, r_2, e_6Polygon(P, O', S, G'') → wielokąt18, p_4, o'_2, s_2, g''_5Rotate(O, (-(120°)), xAxis) → O'_1Rotate(P, (-(120°)), xAxis) → P'Rotate(Q, (-(120°)), xAxis) → Q'Rotate(O', (-(120°)), xAxis) → O''Rotate(R, (-(120°)), xAxis) → R'Rotate(S, (-(120°)), xAxis) → S'Polygon(E'', G', S', R') → wielokąt19, e''_3, g'_3, s', r'Polygon(O'_1, J, E'') → wielokąt20, e''_4, o'_3, j_1Polygon(O'_1, E'', R', Q') → wielokąt21, o'_4, e''_5, r'_1, q'Polygon(J, O'_1, P', L) → wielokąt22, j_2, o'_5, p', l_1Polygon(O'_1, Q', O'', P') → wielokąt23, o'_6, q'_1, o'', p'_1Polygon(Q', R', S', O'') → wielokąt24, q'_2, r'_2, s'_1, o''_1Polygon(P', G', L) → wielokąt25, l_2, p'_2, g'_4Polygon(P', O'', S', G') → wielokąt26, p'_3, o''_2, s'_2, g'_5Rotate(P', (-(120°)), xAxis) → P''Rotate(O'_1, (-(120°)), xAxis) → TRotate(O'', 120°, xAxis) → O'''Rotate(S', (-(120°)), xAxis) → S''Rotate(Q', (-(120°)), xAxis) → Q''Rotate(O'', (-(120°)), xAxis) → O'''_1Rotate(R', (-(120°)), xAxis) → R''Polygon(G, S'', R'', E') → wielokąt27, g_4, s'', r'', e'_3Polygon(G, P'', K) → wielokąt28, k_1, g_5, p''Polygon(G, P'', O'''_1, S'') → wielokąt29, g_6, p''_1, o'''_1, s''_1Polygon(S'', O'''_1, Q'', R'') → wielokąt30, s''_2, o'''_2, q'', r''_1Polygon(P'', T, Q'', O'''_1) → wielokąt31, p''_2, t, q''_1, o'''_3Polygon(K, I, T, P'') → wielokąt32, k_2, i_1, t_1, p''_3Polygon(T, E', I) → wielokąt33, i_2, t_2, e'_4Polygon(T, E', R'', Q'') → wielokąt34, t_3, e'_5, r''_2, q''_2Circle(H, 1, h) → c_1Midpoint(H, M) → UCircle(U, sqrt(3) / 2, m_2) → d_1Intersect(c_1, d_1) → V, W, ,Rotate(W, 120°, xAxis) → W'Rotate(W', 120°, xAxis) → W''Polygon(H, W, M) → wielokąt35, m_3, h_3, wPolygon(H, W, W', K) → wielokąt36, h_4, w_1, w', k_3Polygon(K, W', I) → wielokąt37, i_3, k_4, w'_1Polygon(W', W'', L, I) → wielokąt38, w'_2, w'', l_3, i_4Polygon(W, M, J, W'') → wielokąt39, w_2, m_4, j_3, w''_1Polygon(W'', J, L) → wielokąt40, l_4, w''_2, j_4Rotate(Z, 60°, xAxis) → Z'Rotate(Z', 60°, xAxis) → Z''Rotate(Z'', 60°, xAxis) → Z'''Rotate(Z''', 60°, xAxis) → A_1Rotate(A_1, 60°, xAxis) → B_1Polygon(W, B_1, A_1) → wielokąt41, a_4, w_3, b_1Polygon(B_1, Z, W', W) → wielokąt42, b_2, z_1, w'_3, w_4Polygon(W', Z, Z') → wielokąt43, z', w'_4, z_2Polygon(W'', W', Z', Z'') → wielokąt44, w''_3, w'_5, z'_1, z''Polygon(W'', Z'', Z''') → wielokąt45, z''', w''_4, z''_1Polygon(W, W'', Z''', A_1) → wielokąt46, w_5, w''_5, z'''_1, a_5Rotate(C_1, 60°, xAxis) → D_1Rotate(D_1, 60°, xAxis) → E_1Rotate(E_1, 60°, xAxis) → F_1Rotate(F_1, 60°, xAxis) → G_1Rotate(G_1, 60°, xAxis) → H_1Polygon(B_1, H_1, G_1, A_1) → wielokąt47, b_3, h_5, g_7, a_6Polygon(B_1, H_1, C_1, Z) → wielokąt48, b_4, h_6, c_2, z_3Polygon(A_1, Z''', F_1, G_1) → wielokąt49, a_7, z'''_2, f_1, g_8Polygon(Z, C_1, D_1, Z') → wielokąt50, z_4, c_3, d_2, z'_2Polygon(Z', D_1, E_1, Z'') → wielokąt51, z'_3, d_3, e_7, z''_2Polygon(F_1, Z''', Z'', E_1) → wielokąt52, f_2, z'''_3, z''_3, e_8Rotate(I_1, 120°, xAxis) → J_1Rotate(J_1, 120°, xAxis) → K_1Polygon(H_1, I_1, G_1) → wielokąt53, g_9, h_7, i_5Polygon(H_1, I_1, J_1, C_1) → wielokąt54, h_8, i_6, j_5, c_4Polygon(C_1, J_1, D_1) → wielokąt55, d_4, c_5, j_6Polygon(J_1, K_1, E_1, D_1) → wielokąt56, j_7, k_5, e_9, d_5Polygon(K_1, F_1, E_1) → wielokąt57, e_{10}, k_6, f_3Polygon(I_1, K_1, F_1, G_1) → wielokąt58, i_7, k_7, f_4, g_{10}Rotate(L_1, 60°, xAxis) → M_1Rotate(M_1, 60°, xAxis) → N_1Rotate(N_1, 60°, xAxis) → O_1Rotate(O_1, 60°, xAxis) → P_1Rotate(P_1, 60°, xAxis) → Q_1Polygon(I_1, Q_1, L_1) → wielokąt59, l_5, i_8, q_4Polygon(I_1, L_1, M_1, J_1) → wielokąt60, i_9, l_6, m_5, j_8Polygon(M_1, J_1, N_1) → wielokąt61, n_1, m_6, j_9Polygon(J_1, K_1, O_1, N_1) → wielokąt62, j_{10}, k_8, o_4, n_2Polygon(P_1, K_1, O_1) → wielokąt63, o_5, p_5, k_9Polygon(Q_1, I_1, K_1, P_1) → wielokąt64, q_5, i_{10}, k_{10}, p_6Polygon(L_1, R_1, S_1, M_1) → wielokąt65, l_7, r_3, s_3, m_7Polygon(M_1, S_1, T_1, N_1) → wielokąt66, m_8, s_4, t_4, n_3Polygon(R_1, L_1, Q_1, W_1) → wielokąt67, r_4, l_8, q_6, w_6Polygon(W_1, Q_1, P_1, V_1) → wielokąt68, w_7, q_7, p_7, v_1Polygon(V_1, P_1, O_1, U_1) → wielokąt69, v_2, p_8, o_6, u_1Polygon(T_1, N_1, O_1, U_1) → wielokąt70, t_5, n_4, o_7, u_2Polygon(R_1, W_1, E_2, Z_1) → wielokąt71, r_5, w_8, e_{11}, z_5Polygon(R_1, Z_1, A_2, S_1) → wielokąt72, r_6, z_6, a_8, s_5Polygon(S_1, A_2, B_2, T_1) → wielokąt73, s_6, a_9, b_5, t_6Polygon(E_2, W_1, V_1, D_2) → wielokąt74, e_{12}, w_9, v_3, d_6Polygon(D_2, V_1, U_1, C_2) → wielokąt75, d_7, v_4, u_3, c_6Polygon(C_2, U_1, T_1, B_2) → wielokąt76, c_7, u_4, t_7, b_6Rotate(F_2, 120°, xAxis) → G_2Rotate(G_2, 120°, xAxis) → H_2Polygon(Z_1, F_2, E_2) → wielokąt77, e_{13}, z_7, f_5Polygon(Z_1, F_2, G_2, A_2) → wielokąt78, z_8, f_6, g_{11}, a_{10}Polygon(A_2, G_2, B_2) → wielokąt79, b_7, a_{11}, g_{12}Polygon(B_2, G_2, H_2, C_2) → wielokąt80, b_8, g_{13}, h_9, c_8Polygon(F_2, E_2, D_2, H_2) → wielokąt81, f_7, e_{14}, d_8, h_{10}Polygon(H_2, D_2, C_2) → wielokąt82, c_9, h_{11}, d_9Midpoint(F_2, H_2) → I_2Circle(I_2, sqrt(3) / 2, h_{10}) → r_7Intersect(xAxis, r_7) → J_2, K_2Polygon(G_2, H_2, J_2) → wielokąt83, j_{11}, g_{14}, h_{12}Polygon(G_2, F_2, J_2) → wielokąt84, j_{12}, g_{15}, f_8Polygon(F_2, H_2, J_2) → wielokąt85, j_{13}, f_9, h_{13}
AI Drawing Prompt Reference
Draw a rocket trajectory, involving rotating triangles and cylinders, generating multiple polygons and circles through rotation and intersection, showing the geometric construction process of a rocket launch, ultimately forming a complex solid composite.
The prompt above was compiled from the original drawing commands and is for reference only.