
Radians in Unit Circle: Reflection, Translation, Rotation
Loading the math board and drawing, please wait…
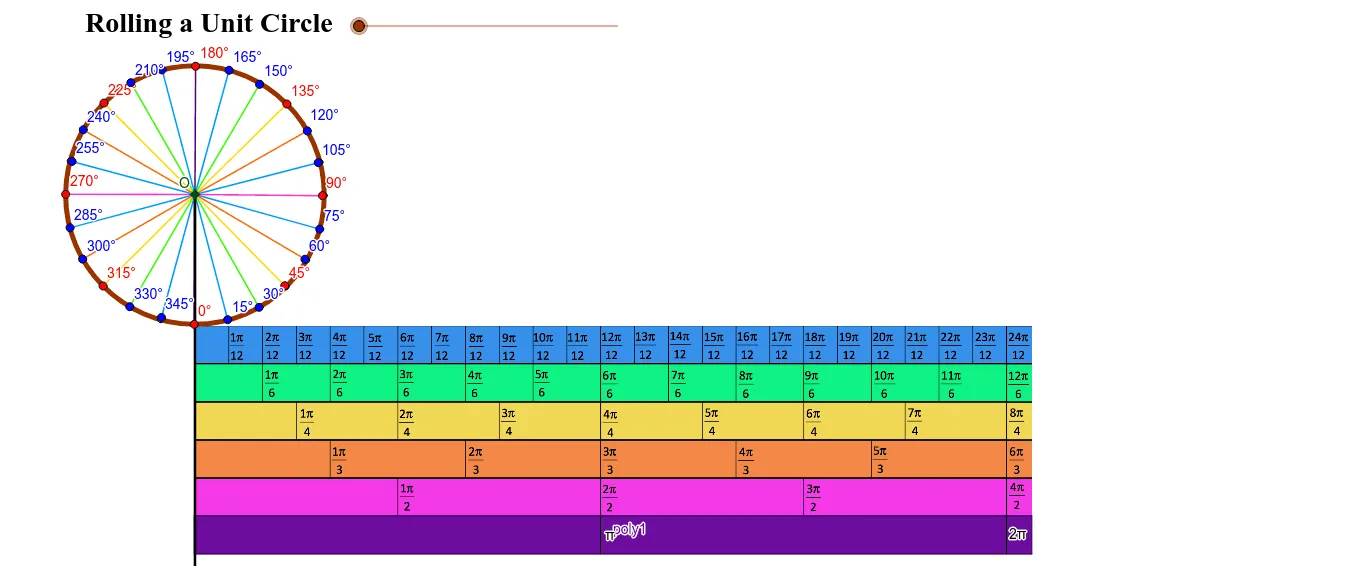
This GeoGebra example demonstrates the geometric meaning of radian measure on the unit circle, showing how a point moves along the circumference as the central angle changes. Core mathematics concepts include the unit circle, radians, central angles, arc length, coordinate geometry, and plane transformations such as reflection, translation, and rotation. The construction employs GeoGebra commands including Line, Circle, OrthogonalLine, Intersect, Segment, Rotate, Angle, CircleArc, Vector, Translate, Mirror, Point, Polygon, and Ray, together with objects such as center, A, B, α, F, F′, Q, Q′, and R to build arcs, projections, and transformed images. It is suitable for high school trigonometry and pre-calculus courses, as well as introductory university calculus, serving as a visual tool for radian definition, unit-circle exploration, and transformation geometry.
GeoGebra Commands & Parameters
Line(A, B) → aLine(C, D) → bCircle(E, 2) → cOrthogonalLine(E, a) → dIntersect(d, a) → FSegment(A, F) → eRotate(F, (-(180 * e / 6.28))°, E) → F'Angle(F', E, F) → αCircleArc(E, F, F') → fVector(E, F') → uRotate(F', 3.141592653589793, E) → F''_1Vector(P, Q) → vTranslate(Q, v) → Q'Vector(Q, Q') → wTranslate(Q', w) → Q''Translate(Q'', w) → Q'''Translate(Q''', w) → RTranslate(R, w) → R'Vector(Q', Q'') → zVector(Q'', Q''') → mVector(Q''', R) → nVector(R, R') → pVector(P, R') → qRotate(F', 0.7853981633974483, E) → F''Angle(F', E, F'') → βRotate(F', 0.2617993877991494, E) → F''_2Angle(F', E, F''_2) → γRotate(F', 0.5235987755982988, E) → F''_3Angle(F', E, F''_3) → δRotate(F', 1.0471975511965976, E) → F''_4Angle(F', E, F''_4) → εRotate(F', 1.3089969389957472, E) → F''_5Angle(F', E, F''_5) → ζRotate(F', 1.5707963267948966, E) → F''_6Angle(F', E, F''_6) → ηRotate(F', 1.8325957145940461, E) → F''_7Angle(F', E, F''_7) → θRotate(F', 2.0943951023931953, E) → F''_8Angle(F', E, F''_8) → ιRotate(F''_8, 0.2617993877991494, E) → UAngle(F''_8, E, U) → κRotate(U, 0.2617993877991494, E) → U'Angle(U, E, U') → λRotate(U', 0.2617993877991494, E) → U''Angle(U', E, U'') → μRotate(U'', 0.2617993877991494, E) → U'''Angle(U'', E, U''') → νRotate(U''', 0.2617993877991494, E) → VAngle(U''', E, V) → ξRotate(V, 0.2617993877991494, E) → V'Angle(V, E, V') → οRotate(V', 0.2617993877991494, E) → V''Angle(V', E, V'') → ρRotate(V'', 0.2617993877991494, E) → V'''Angle(V'', E, V''') → σRotate(V''', 0.2617993877991494, E) → WAngle(V''', E, W) → τRotate(W, 0.2617993877991494, E) → W'Angle(W, E, W') → υRotate(W', 0.2617993877991494, E) → W''Angle(W', E, W'') → ϕRotate(W'', 0.2617993877991494, E) → W'''Angle(W'', E, W''') → χRotate(W''', 0.2617993877991494, E) → ZAngle(W''', E, Z) → ψRotate(Z, 0.2617993877991494, E) → Z'Angle(Z, E, Z') → ωRotate(Z', 0.2617993877991494, E) → Z''Angle(Z', E, Z'') → α_1Mirror(A_1, J) → B_1Line(B_1, a) → gOrthogonalLine(T, g) → hIntersect(g, h) → C_1Segment(J, B_1) → iSegment(B_1, C_1) → jSegment(C_1, T) → kSegment(T, J) → lPoint(l) → D_1OrthogonalLine(D_1, j) → rIntersect(j, r) → E_1Segment(D_1, E_1) → sOrthogonalLine(G, a) → tIntersect(t, j) → F_1Intersect(t, l) → G_1Segment(F_1, G_1) → a_1Polygon(B_1, J, T, C_1) → poly1, b_1, j_1, t_1, c_1OrthogonalLine(E, a) → d_1Point(d_1) → H_1Segment(H_1, F''_2) → e_1Segment(H_1, F''_3) → f_1Segment(H_1, F'') → g_1Segment(H_1, F''_4) → h_1Segment(H_1, F''_5) → i_1Segment(H_1, F''_6) → k_1Segment(H_1, F''_7) → l_1Segment(H_1, F''_8) → m_1Segment(H_1, U) → n_1Segment(H_1, U') → p_1Segment(H_1, U'') → q_1Point(d_1) → I_1Segment(H_1, I_1) → r_1Segment(H_1, V) → s_1Segment(H_1, V') → a_2Segment(H_1, V'') → b_2Segment(H_1, V''') → c_2Segment(H_1, W) → d_2Segment(H_1, W') → e_2Segment(H_1, W'') → f_2Segment(H_1, W''') → g_2Segment(H_1, Z) → h_2Segment(H_1, Z') → i_2Segment(H_1, Z'') → j_2Point(d_1) → J_1Ray(H_1, J_1) → k_2Point(k_2) → K_1Segment(H_1, K_1) → l_2Segment(F', H_1) → m_2Segment(H_1, U''') → n_2Ray(H_1, K_1) → p_2Intersect(e_1, f_1) → OPoint(m_2) → L_1Point(k_1) → M_1Point(n_2) → N_1Point(e_2) → P_1Point(g_1) → Q_1Point(n_1) → R_1Point(b_2) → S_1Point(h_2) → T_1Point(e_1) → U_1Point(f_1) → V_1Point(h_1) → W_1Point(i_1) → Z_1Point(l_1) → A_2Point(m_1) → B_2Point(p_1) → C_2Point(q_1) → D_2Point(s_1) → E_2Point(c_2) → F_2Point(d_2) → G_2Point(f_2) → H_2Point(g_2) → I_2Point(i_2) → J_2Point(j_2) → K_2Point(a_2) → L_2