
Polygon Angle Sums: Dynamic Quadrilateral through Octagon
Loading the math board and drawing, please wait…
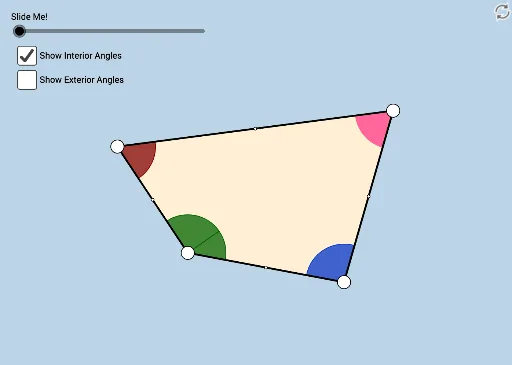
① This interactive GeoGebra example dynamically demonstrates the interior and exterior angle sum theorems for polygons ranging from quadrilaterals to octagons, allowing users to drag vertices and observe angle changes in real time. ② Core mathematical concepts include the polygon interior angle sum formula (n-2)×180°, the constant exterior angle sum of 360°, and behavior for both convex and concave polygons. ③ Construction highlights: using GeoGebra commands such as Ray, Point, Circle, Intersect, Segment, Angle, CircleSector, Vector, Translate, Dilate, If, Line, Polygon, Rotate, Mirror, Midpoint, and CircleArc, the example builds adjustable polygons with labeled angle arcs and dynamic modification via sliders or draggable points. ④ Suitable for middle and high school geometry classes, math lab activities, or self-directed exploration, this resource helps learners grasp the fundamental angle-sum relationships and serves as an effective teaching aid for classroom demonstrations or flipped lessons.
GeoGebra Commands & Parameters
Ray(P, A) → h_1Point(h_1) → RRay(A, R) → j_1Ray(A, B) → aCircle(A, 1.5) → gIntersect(g, j_1) → I_1,Intersect(g, a, 1) → HSegment(P, A) → l_1Intersect(g, l_1, 1) → H_1Segment(P, C) → k_1Circle(C, 1.5) → kIntersect(k, k_1) → Z,Ray(B, C) → bIntersect(k, b) → M, NPoint(a) → D_1Point(b) → E_1Ray(B, D_1) → eRay(C, E_1) → fPoint(e) → DPoint(f) → EAngle(A, C, B) → γAngle(D, B, C) → εAngle(E, C, A) → ζCircle(B, 1.5) → hIntersect(h, b, 1) → JIntersect(h, a, 1) → KIntersect(h, a, 2) → LCircleSector(B, J, K) → qCircleSector(B, L, J) → tVector(B, C) → uCircleSector(A, I_1, H) → c_1Vector(A, C) → vTranslate(q, u) → q'Segment(B, C) → lDilate(C, If[0 < j ≤ 1, j, 0], B) → C'Vector(B, C') → wTranslate(q, w) → q'_1Dilate(A, If[1 < j ≤ 2, 2 - j, 0], C) → C'_1Vector(A, C'_1) → mDilate(C, If[0 < n ≤ 1, n, 0], B) → C'_2Dilate(A, If[1 < n ≤ 2, 2 - n, 0], C) → A'Vector(B, C'_2) → u_1Vector(A, A') → v_1If(0 < n ≤ 1, Translate[t, u_1], Translate[t, u]) → e_1If(1 < n ≤ 2, Translate[c_1, v_1], Translate[c_1, v]) → f_1Ray(C, P) → g_1Point(g_1) → QRay(P, Q) → i_1Point(i_1) → SPoint(j_1) → TCircle(P, 1.5) → p_1Intersect(p_1, l_1) → U,Intersect(p_1, i_1) → V,Intersect(p_1, k_1) → W,CircleSector(P, U, W) → q_1Intersect(k, b, 2) → A_1Line(P, b) → b_1Intersect(p_1, b_1) → C_1, G_1Angle(B, A, P) → αVector(P, C) → iDilate(P, If[2 < j ≤ 3, 3 - j, 0], C) → P'Vector(P, P') → w_1Translate(q_1, w_1) → r_1CircleSector(C, N, Z) → sCircleSector(P, V, U) → t_1Dilate(P, If[2 < n ≤ 3, 3 - n, 0], C) → P'_1Vector(P, P'_1) → m_1If(2 < n ≤ 3, Translate[t_1, m_1], Translate[t_1, w_1]) → e_2Angle(H, A, I_1) → δAngle(V, P, U) → ηAngle(U, P, W) → θPolygon(A, B, C, P) → poly1, a_2, b_2, c_2, p_2Segment(A, C) → n_1Intersect(g, n_1) → F,Intersect(k, n_1) → G,Line(P, n_1) → cLine(B, n_1) → dCircleSector(C, Z, G) → d_1CircleSector(C, G, M) → s_1CircleSector(A, H, F) → d_2If(0 < j ≤ 1, Dilate[C, 1 - j, B]) → IIf(1 < j ≤ 2, Dilate[A, 2 - j, P]) → OIf(1 < j ≤ 2, Dilate[C, 2 - j, P]) → B_1Vector(C, I) → rVector(A, O) → u_2Translate(s_1, r) → h_2Rotate(d_2, 180°, A) → k_2Vector(A, B) → v_2Vector(C, B) → w_2Translate(s_1, w_2) → s_2Mirror(s_2, B) → t_2Vector(A, P) → i_2Vector(C, P) → j_2CircleSector(A, F, H_1) → f_2Translate(f_2, i_2) → d_3Vector(C, B_1) → l_2Translate(d_1, j_2) → f_3Mirror(f_3, P) → g_3Translate(f_2, u_2) → h_3Translate(d_1, l_2) → k_3Segment(A, B) → m_2Polygon(A, B, C) → poly2, c_4, a_3, b_3Polygon(A, C, P) → poly3, p_4, a_4, c_5Midpoint(m_2) → M_4Midpoint(l) → J_1Midpoint(k_1) → M_2Midpoint(l_1) → M_3Segment(J, C) → n_2Segment(J_1, C) → i_3Rotate(J_1, If[0 < j ≤ 1, (((-j) * 180))°, -180°], J_1) → M_1Rotate(C, If[0 < j ≤ 1, (((-j) * 180))°, -180°], J_1) → C'_3Segment(M_1, C'_3) → j_3Rotate(s_1, If[0 < j ≤ 1, (((-j) * 180))°, -180°], J_1) → r_3Segment(J_1, B) → r_2Rotate(d_2, If[0 < j ≤ 1, ((j * 180))°, 180°], M_4) → pRotate(A, If[0 < j ≤ 1, ((j * 180))°, 180°], M_4) → A'_1Segment(M_4, A'_1) → g_2Rotate(C, If[1 < j ≤ 2, (((j - 1) * 180))°, 180°], M_2) → C'_4Segment(M_2, C'_4) → q_2Rotate(d_1, If[1 < j ≤ 2, (((j - 1) * 180))°, 180°], M_2) → c_3Rotate(A, If[1 < j ≤ 2, (((-(j - 1)) * 180))°, 180°], M_3) → A'_2Segment(M_3, A'_2) → e_3Rotate(f_2, If[1 < j ≤ 2, (((-(j - 1)) * 180))°, 180°], M_3) → p_3CircleArc(C, G, M) → q_3CircleArc(A, H, F) → s_3CircleArc(C, Z, G) → t_3CircleArc(A, F, H_1) → d_4Segment(M_2, C) → l_3Segment(M_2, P) → m_3Segment(P, M_3) → n_3Segment(M_3, A) → b_4Segment(A, M_4) → e_4Segment(M_4, B) → f_4