
Non-Lamp Geometric Demonstration
Loading the math board and drawing, please wait…
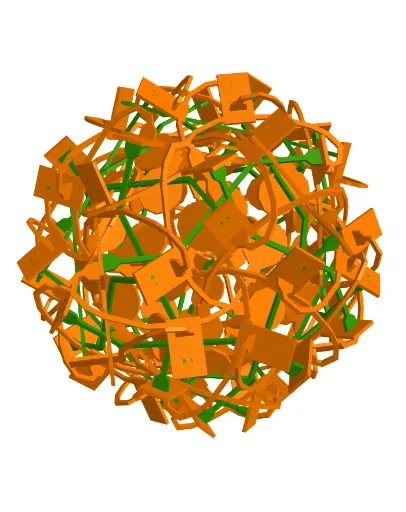
This example demonstrates the construction and properties of a non-traditional geometric shape, the dodecahedron. It involves core mathematical concepts including solid geometry, midpoints, line-plane relationships, normal distribution (for point generation), and coordinate geometry. GeoGebra commands used in the construction include Point, Dodecahedron, Midpoint, Line, Intersect, Translate, Plane, Ray, Rotate, OrthogonalLine, IntersectPath, Distance, PointIn, Circle, Mirror, Polygon, and Sequence. It is suitable for high school and above students for learning solid geometry and spatial visualization skills.
GeoGebra Commands & Parameters
Point(Circle[((A * (1 - sqrt(5))) + (B * (3 + sqrt(5)))) / 4, (Distance[A, B] * sqrt(10 + (2 * sqrt(5))) / 4), Segment[A, B]]) → CDodecahedron(A, B, C) → a, D, M, N, O, P, Q, R, S, T, 면ABCDE, 면AEIOJ, E, 면ABFKJ, 면BCGLF, 면CDHMG, 면DEINH, 면INSTO, 면JKPTO, 면FKPQL, 면GLQRM, 면HMRSN, 면PQRST, F, 모서리AE, 모서리AB, 모서리BC, 모서리CD, 모서리DE, 모서리AJ, 모서리EI, 모서리IO, 모서리JO, 모서리JK, G, 모서리FK, 모서리BF, 모서리FL, 모서리GL, 모서리CG, 모서리GM, 모서리HM, 모서리DH, 모서리HN, 모서리IN, H, 모서리NS, 모서리ST, 모서리OT, 모서리PT, 모서리KP, 모서리PQ, 모서리LQ, 모서리QR, 모서리MR, 모서리RS, I, J, K, LMidpoint(A, R) → ULine(P, L) → hLine(Q, G) → gLine(Q, K) → fIntersect(h, f) → VTranslate(V, Vector[(0.9 * u)]) → WTranslate(W, Vector[(-5.2 * u) - (3.3 * v)]) → W'_1Translate(W, Vector[(2 * v)]) → W'Translate(W', Vector[(0.6 * u)]) → W''Plane(g, f) → pRay(U, l3(A12)) → B12Ray(U, Centroid[l2(A6)]) → C6Rotate(Rotate[W'', (-(72°)), C6], 120°, B12) → P_1Rotate(Rotate[W', (-(72°)), C6], 120°, B12) → O_1Rotate(Rotate[p, (-(72°)), C6], 120°, B12) → qOrthogonalLine(O_1, q) → nPlane(P_1, n) → rIntersectPath(p, r) → sPoint(s) → U_1OrthogonalLine(U_1, s, p) → cDistance(U, J) → bTranslate(W, Vector[(0.2 * u)]) → ZTranslate(W, Vector[(0.6 * u)]) → A_1Translate(W, Vector[(1.7 * u)]) → C_1Translate(V, Vector[(3.4 * v)]) → B_1Translate(C_1, Vector[(3.4 * v)]) → D_1Translate(C_1, Vector[(-1.1 * v)]) → E_1Translate(V, Vector[(-1.1 * v)]) → F_1Translate(V, Vector[(-0.5 * v)]) → V'Translate(V, Vector[(-0.9 * v)]) → V'_1Translate(C_1, Vector[(-0.9 * v)]) → G_1Translate(C_1, Vector[(-0.5 * v)]) → H_1Translate(Q, Vector[(-((Distance[Q, W] * v)))]) → I_1Translate(I_1, Vector[(0.3 * u)]) → J_1Translate(I_1, Vector[(0.3 * u) + (0.2 * v)]) → K_1Translate(I_1, Vector[(0.2 * v)]) → L_1Translate(J_1, Vector[(-((0.3 * v)))]) → M_1Translate(J_1, Vector[(1.1 * v)]) → N_1Ray(U, l3(A1)) → B1Ray(U, l3(A2)) → B2Ray(U, l3(A3)) → B3Ray(U, l3(A4)) → B4Ray(U, l3(A5)) → B5Ray(U, l3(A6)) → B6Ray(U, l3(A7)) → B7Ray(U, l3(A8)) → B8Ray(U, l3(A9)) → B9Ray(U, l3(A10)) → B10Ray(U, l3(A11)) → B11Ray(U, l3(A13)) → B13Ray(U, l3(A14)) → B14Ray(U, l3(A15)) → B15Ray(U, l3(A16)) → B16Ray(U, l3(A17)) → B17Ray(U, l3(A18)) → B18Ray(U, l3(A19)) → B19Ray(U, l3(A20)) → B20Ray(U, Centroid[l2(A1)]) → C1Ray(U, Centroid[l2(A2)]) → C2Ray(U, Centroid[l2(A3)]) → C3Ray(U, Centroid[l2(A4)]) → C4Ray(U, Centroid[l2(A5)]) → C5Ray(U, Centroid[l2(A7)]) → C7Ray(U, Centroid[l2(A8)]) → C8Ray(U, Centroid[l2(A9)]) → C9Ray(U, Centroid[l2(A10)]) → C10Ray(U, Centroid[l2(A11)]) → C11Ray(U, Centroid[l2(A12)]) → C12Translate(W, Vector[(-3.5 * u) - (1.4 * v)]) → W'_2Translate(W'_1, Vector[(0.4 * UnitVector[c])]) → R_1Line(R_1, W'_1) → tTranslate(W'_1, Vector[(0.3 * UnitVector[t])]) → S_1Translate(R_1, Vector[(-0.3 * UnitVector[t])]) → T_1Translate(U_1, Vector[(0.3 / tan(36°) * UnitVector[c])]) → V_1Point(s) → W_1Translate(V_1, Vector[U_1, W_1]) → Z_1Point(Circle[W'_2, 0.4, p]) → Q_1OrthogonalLine(S_1, t, p) → dTranslate(S_1, Vector[(1.3 * UnitVector[d])]) → A_2Translate(T_1, Vector[(1.3 * UnitVector[d])]) → B_2PointIn(p) → C_2PointIn(p) → D_2PointIn(p) → E_2Point(d) → F_2PointIn(p) → G_2PointIn(p) → H_2PointIn(p) → I_2PointIn(p) → J_2PointIn(p) → K_2PointIn(p) → L_2Translate(N_1, Vector[(1.25 * u) - (0.5 * v)]) → M_2Translate(N_1, Vector[(1.25 * u) - (0.9 * v)]) → N_2PointIn(p) → O_2PointIn(p) → P_2PointIn(p) → Q_2PointIn(p) → R_2PointIn(p) → S_2PointIn(p) → V_2PointIn(p) → W_2PointIn(p) → Z_2PointIn(p) → A_3PointIn(p) → B_3Rotate(Rotate[Rotate[W', 72°, C6], (-(120°)), B16], (-(144°)), C2) → C_3Rotate(Rotate[Rotate[W'', 72°, C6], (-(120°)), B16], (-(144°)), C2) → D_3Line(C_3, D_3) → eLine(O_1, P_1) → i_1Translate(P_1, Vector[(0.2 * UnitVector[i_1])]) → H_3Translate(O_1, Vector[(0.2 * UnitVector[i_1])]) → I_3OrthogonalLine(P_1, i_1, r) → j_1Translate(P_1, Vector[(-0.3 * UnitVector[j_1])]) → J_3Translate(H_3, Vector[(-0.3 * UnitVector[j_1])]) → K_3Translate(I_3, Vector[(-0.3 * UnitVector[j_1])]) → L_3Translate(O_1, Vector[(-0.3 * UnitVector[j_1])]) → M_3Circle(V, 4.2, r) → c_1Translate(O_1, Vector[(-0.3 * UnitVector[i_1])]) → N_3Translate(H_3, Vector[(0.3 * UnitVector[i_1])]) → O_3Translate(I_3, Vector[(1.25 * UnitVector[j_1])]) → P_3Translate(P_1, Vector[(1.25 * UnitVector[j_1])]) → Q_3Translate(Q_3, Vector[(-0.4 * UnitVector[j_1]) + (0.4 * UnitVector[i_1])]) → H_4Translate(P_3, Vector[(-0.4 * UnitVector[j_1]) - (0.4 * UnitVector[i_1])]) → I_4Midpoint(D_3, P_1) → E_3Translate(V_1, Vector[(-0.3 * UnitOrthogonalVector[p])]) → F_3Line(Q_3, j_1) → k_1Mirror(W_1, E_3) → G_3Line(G_3, F_3) → l_1Line(W_1, l_1) → a_1Line(P_3, j_1) → f_3Line(P_3, Q_3) → g_3Intersect(s, g_3) → R_3Intersect(k_1, l_1) → S_3Intersect(a_1, f_3) → T_3Mirror(G_3, E_3) → U_3Mirror(F_3, E_3) → V_3Mirror(S_3, E_3) → W_3Mirror(Q_3, E_3) → Z_3Mirror(H_4, E_3) → A_4Mirror(O_3, E_3) → B_4Mirror(P_1, E_3) → C_4Mirror(J_3, E_3) → D_4Mirror(K_3, E_3) → E_4Mirror(H_3, E_3) → F_4Mirror(O_1, E_3) → G_4Mirror(M_3, E_3) → J_4Mirror(L_3, E_3) → K_4Mirror(I_3, E_3) → L_4Mirror(N_3, E_3) → M_4Mirror(I_4, E_3) → N_4Mirror(P_3, E_3) → O_4Mirror(T_3, E_3) → P_4Mirror(W_1, E_3) → Q_4Translate(M_2, Vector[(-0.4 * u) + (0.4 * v)]) → T_2Translate(N_2, Vector[(-0.4 * u) - (0.4 * v)]) → U_2Translate(J_1, Vector[(0.6 * v)]) → R_4Translate(I_1, Vector[(0.6 * v)]) → S_4Translate(L_1, Vector[(0.6 * v)]) → T_4Translate(K_1, Vector[(0.6 * v)]) → U_4Polygon(V', B_1, U_2, M_1, J_1, I_1, L_1, K_1, R_4, S_4, T_4, U_4, D_1, N_1, T_2, M_2, S_2, R_2, Q_2, P_2, O_2, G_1, E_1, H_1, F_1, V'_1, L_2, Q_1, R_1, T_1, B_2, K_2, J_2, I_2, B_3, H_2, G_2, F_2, E_2, W_1, Z_1, V_1, U_1, D_2, A_2, A_3, S_1, W'_1, W'_2, C_2, Z_2, W_2, V_2, N_2) → 다각형1, i, n_1, p_1, q_1, r_1, s_1, t_1, b_1, d_1, e_1, f_2, j, g_2, h_2, i_2, j_2, k_2, l_2, m_2, n_2, p_2, q_2, k, r_2, s_2, t_2, a_2, b_2, c_2, d_2, e_2, h_3, a_3, l, b_3, r_4, s_4, t_4, l_5, m_5, n_5, p_5, q_5, r_5, m, s_5, t_5, a_5, b_5, c_5, f_1, g_1, h_1, m_1Polygon(O_3, H_4, L_4, K_4, J_4, C_3, F_4, E_4, D_4, C_4, B_4, A_4, Q_3, Z_3, W_3, V_3, W_1, T_3, P_3, I_4, N_3, I_3, L_3, S_3, M_3, O_1, H_3, K_3, J_3, P_1, F_3, G_3, P_4, O_4, N_4, M_4) → 다각형2, i_3, s_3, t_3, c_3, d_3, e_3, f_4, g_4, h_4, i_4, j_4, j_3, k_4, l_4, m_4, n_4, p_4, q_4, a_4, b_4, c_4, d_4, k_3, e_4, f_5, g_5, h_5, i_5, j_5, k_5, l_3, m_3, n_3, p_3, q_3, r_3Sequence(Rotate[Prism[다각형1, -0.3], ((ω * 2) * π / 5), C6], ω, 0, 4) → l4Rotate(Prism[다각형2, 0.3], 120°, B11) → oRotate(l4, 120°, B17) → l4'Rotate(l4', 120°, B17) → l4''Rotate(l4', 120°, B13) → l4''_1Rotate(l4''_1, 120°, B13) → l5Rotate(l5, 120°, B14) → l5'Rotate(l5', 120°, B14) → l5''Rotate(l5'', 120°, B15) → l5'''Rotate(l5''', 120°, B15) → l6Rotate(l4, 120°, B6) → l4'_1Rotate(l4'_1, 120°, B6) → l7Rotate(l7, 120°, B3) → l7'Rotate(o, 120°, B16) → o'Rotate(o', 120°, B16) → o''Rotate(o', 120°, B17) → o''_1Rotate(o''_1, 120°, B17) → wRotate(w, 120°, B18) → w'Rotate(w', 120°, B18) → w''Rotate(w'', 120°, B19) → w'''Rotate(w''', 120°, B19) → o_1Rotate(w''', 120°, B14) → u_1Rotate(u_1, 120°, B14) → v_1Rotate(v_1, 120°, B9) → w_1Rotate(w_1, 120°, B9) → o_2Rotate(o_2, 120°, B15) → u_2Rotate(u_2, 120°, B15) → v_2Rotate(u_2, 120°, B10) → w_2Rotate(w_2, 120°, B10) → o_3Rotate(o_3, 120°, B11) → u_3Rotate(u_3, 120°, B6) → v_3Rotate(v_3, 120°, B6) → w_3Rotate(w_3, 120°, B12) → o_4Rotate(o_4, 120°, B7) → u_4Rotate(u_4, 120°, B7) → v_4Rotate(v_4, 120°, B13) → w_4Rotate(w_4, 120°, B8) → d_5Rotate(w_1, 120°, B5) → e_5Rotate(e_5, 120°, B5) → o_5Rotate(o_5, 120°, B1) → u_5Rotate(u_5, 120°, B2) → v_5Rotate(v_5, 120°, B3) → w_5