
Hyperboloid under Rotation: Parametric Surface and Dynamic Transformation
Loading the math board and drawing, please wait…
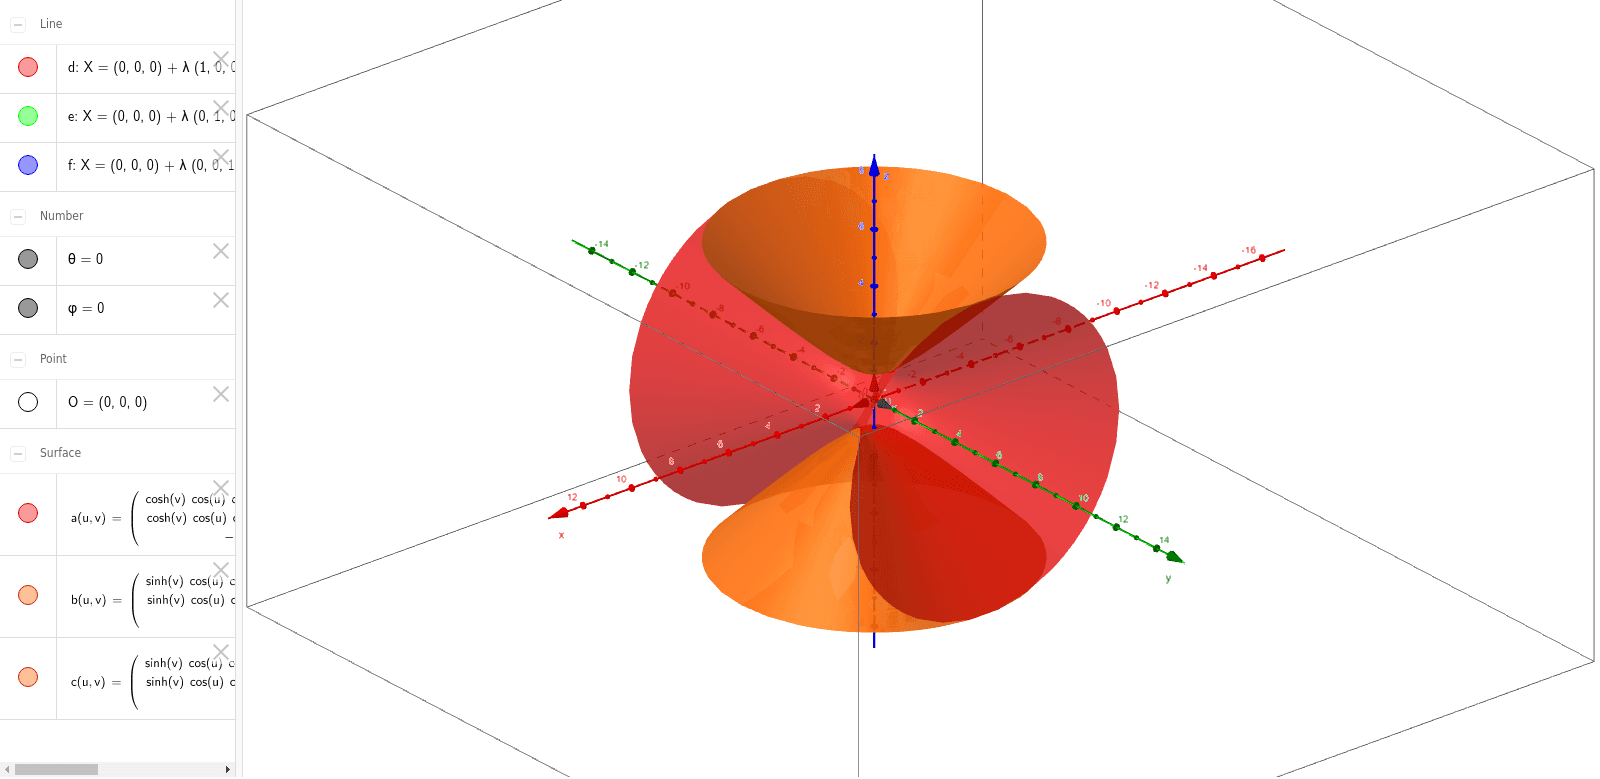
This example demonstrates a hyperboloid rotating around an axis in 3D space, constructed via parametric equations and visualized dynamically. The core mathematical concepts include the parametric representation of a hyperboloid, 3D rotation transformations, and the construction of parametric surfaces. Using GeoGebra commands, the Line command defines the rotation axis and auxiliary lines, while the Surface command generates the hyperboloid with parameters θ and φ. Sliders or dynamic objects (θ, φ) control the rotation angle, with vectors u_x, u_y, u_z serving as basis vectors, and point O plus auxiliary points a, b, c, d, e, f for positioning and constraints. This example is suitable for senior high school or early university students to understand parametric surfaces of quadric surfaces, spatial rotation mathematics, and dynamic visualization in geometry software. It also serves as teaching material for mathematical modeling or introductory computer graphics.
GeoGebra Commands & Parameters
Line(O, u_x) → dLine(O, u_y) → eLine(O, u_z) → fSurface((((cosh(v) * cos(u)) * cos(φ)) * cos(θ)) - (sinh(v) * sin(θ)) + (((cosh(v) * sin(u)) * sin(φ)) * cos(θ)), (((cosh(v) * cos(u)) * cos(φ)) * sin(θ)) + (sinh(v) * cos(θ)) + (((cosh(v) * sin(u)) * sin(φ)) * sin(θ)), (((-cosh(v)) * cos(u)) * sin(φ)) + ((cosh(v) * sin(u)) * cos(φ)), u, 0, 6.28319, v, -2.4, 2.4) → aSurface((((sinh(v) * cos(u)) * cos(φ)) * cos(θ)) - ((sinh(v) * sin(u)) * sin(θ)) + ((cosh(v) * sin(φ)) * cos(θ)), (((sinh(v) * cos(u)) * cos(φ)) * sin(θ)) + ((sinh(v) * sin(u)) * cos(θ)) + ((cosh(v) * sin(φ)) * sin(θ)), (((-sinh(v)) * cos(u)) * sin(φ)) + (cosh(v) * cos(φ)), u, 0, 6.28319, v, -2.4, 2.4) → bSurface((((sinh(v) * cos(u)) * cos(φ)) * cos(θ)) - ((sinh(v) * sin(u)) * sin(θ)) - ((cosh(v) * sin(φ)) * cos(θ)), (((sinh(v) * cos(u)) * cos(φ)) * sin(θ)) + ((sinh(v) * sin(u)) * cos(θ)) - ((cosh(v) * sin(φ)) * sin(θ)), (((-sinh(v)) * cos(u)) * sin(φ)) - (cosh(v) * cos(φ)), u, 0, 6.28319, v, -2.4, 2.4) → c
AI Drawing Prompt Reference
Draw a rotating hyperboloid. The hyperboloid is defined by a rotation axis and three basis vectors. It is generated using parametric equations with parameters θ and φ. The axis and basis vectors control the position and direction of the hyperboloid. Adjusting the parameters allows observation of how the hyperboloid rotates and deforms. The graphic should show the dynamic change of the hyperboloid in 3D space, suitable for understanding parametric surfaces and spatial rotation concepts.
The prompt above was compiled from the original drawing commands and is for reference only.