
General Quadratic Equation (Hyperbola): Imaginary Roots
Loading the math board and drawing, please wait…
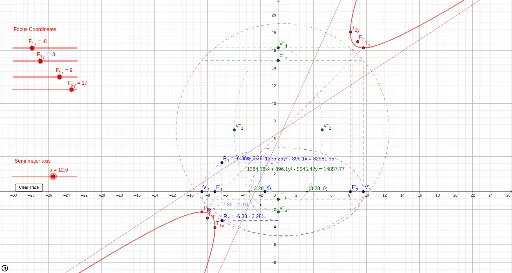
This example demonstrates the general quadratic equation of a hyperbola with imaginary roots. Key mathematical concepts include quadratic equations, imaginary roots, and hyperbolas. The construction uses GeoGebra commands such as Point, Hyperbola, Intersect, Asymptote, etc. Suitable for high school mathematics education and learning.
GeoGebra Commands & Parameters
Point({F_{2x}, F_{2y}}) → F_{2}Circle(F_{2}, (2 * a)) → c_{2}Line(F_{2}, yAxis) → l_{f2yAxis}Point({F_{1x}, F_{1y}}) → F_{1}Hyperbola(F_{1}, F_{2}, a) → hCenter(h) → MPoint({0, y(M)}) → M''Point({x(M), 0}) → M'Vector(M', M'') → uCircle(F_{1}, (2 * a)) → c_{1}Intersect(c_{1}, l_{f2yAxis}) → P_{C1}, BLineBisector(B, F_{2}) → t_{2x}Line(F_{1}, B) → l_{f1t2x}Line(F_{1}, P_{C1}) → l_{f1t1x}OrthogonalLine(F_{1}, yAxis) → l_{f1xAxis}Intersect(c_{2}, l_{f1xAxis}) → D, FLineBisector(F_{1}, F) → t_{1y}Intersect(t_{1y}, xAxis) → F'_{11}LineBisector(F_{1}, D) → t_{2y}Intersect(t_{2y}, xAxis) → F'_{21}Line(F_{1}, yAxis) → l_{f1yAxis}Intersect(c_{2}, l_{f1yAxis}) → P_{B1}, ALine(F_{2}, A) → l_{f2t2x}LineBisector(P_{B1}, F_{1}) → t_{1x}Intersect(t_{2y}, t_{1x}) → CCircle(M, C) → oRadius(o) → rLine(F_{2}, P_{B1}) → l_{f2t1x}Angle(l_{f2t1x}, t_{1x}) → α_{2}Angle(l_{f2t1x}, l_{f1t1x}) → α_{1}If(Min[α_{1}, 360° - α_{1}] > Min[α_{2}, 360° - α_{2}], Intersect[l_{f1t2x}, l_{f2t2x}], Intersect[l_{f1t2x}, t_{2x}]) → T_{2x}OrthogonalLine(T_{2x}, xAxis) → t'_{2y}Intersect(o, t'_{2y}) → J, KOrthogonalLine(J, yAxis) → dIntersect(d, yAxis) → F''_{11}Intersect(t'_{2y}, xAxis) → V'_{2}If(Min[α_{1}, 360° - α_{1}] > Min[α_{2}, 360° - α_{2}], Intersect[l_{f1t1x}, l_{f2t1x}], Intersect[l_{f1t1x}, t_{1x}]) → T_{1x}OrthogonalLine(T_{1x}, xAxis) → t'_{1y}Intersect(t'_{1y}, xAxis) → V'_{1}If(Distance[F'_{11}, F'_{21}] > Distance[V'_{1}, V'_{2}], true, false) → h'IsHyperbolaIf(h'IsEllipse, Intersect[t_{2x}, yAxis]) → V''_{4}If(F_{1x} ≟ F_{2x} ∨ F_{1y} ≟ F_{2y}, Line[M, yAxis], If[h'IsHyperbola, Hyperbola[F'_{11}, F'_{21}, V'_{2}], Ellipse[F'_{11}, F'_{21}, V'_{2}]]) → h'FirstAxisLength(h') → a'If(r > a' ∨ (¬Defined[a']), true, false) → h''MajorAxisIsyAxisSecondAxis(h') → e'_{y}Intersect(h', e'_{y}) → V'_{3}, V'_{4}Semicircle(V'_{4}, V'_{3}) → c_{aux2}Intersect(c_{aux2}, xAxis) → S,If(h'IsHyperbola, Intersect[t_{2x}, yAxis], Translate[S, u]) → V''_{2}If(h'IsHyperbola, Intersect[t_{1x}, yAxis], Mirror[V''_{2}, yAxis]) → V''_{1}Circle(V''_{4}, Distance[M'', V''_{1}]) → c_{aux3}Intersect(c_{aux3}, Line[M'', xAxis]) → F''_{21}, F''_{22}OrthogonalLine(K, yAxis) → sIntersect(s, yAxis) → F''_{12}If(h''MajorAxisIsyAxis, F''_{11}, F''_{21}) → F''_1If(h''MajorAxisIsyAxis, F''_{12}, F''_{22}) → F''_{2}Intersect(t_{1y}, t_{2x}) → NFirstAxis(h) → e_{x}SecondAxis(h) → e_{y}Line(T_{2x}, T_{1x}) → l_{t2xt1x}Intersect(l_{t2xt1x}, xAxis) → R_{x}OrthogonalLine(R_{x}, xAxis) → l_{r11}If(h'IsHyperbola, Hyperbola[F''_1, F''_{2}, V''_{2}], Ellipse[F''_1, F''_{2}, V''_{2}]) → h''Intersect(h'', xAxis) → R_1, R_{11}Line(Point[{0, (-x(R_{11}))}], xAxis) → l_{r22}Excentricity(h) → cEccentricity(h) → ePolar(M, h) → tMirror(t, e_{x}) → t'Tangent(M, h) → q,Segment(F_{1}, A) → s_{a1}Segment(F_{2}, P_{C1}) → s_{b1}Segment(F_{1}, P_{C1}) → s_{e12}Segment(A, F_{2}) → s_{d21}Segment(F_{1}, B) → s_{e22}Segment(F_{2}, P_{B1}) → s_{d12}Segment(A, P_{B1}) → s_{a2}Segment(P_{C1}, B) → s_{b2}OrthogonalLine(F_{2}, yAxis) → l_{f2xAxis}Intersect(c_{1}, l_{f2xAxis}) → G, HLine(H, F_{1}) → l_{f1t1y}Line(F_{1}, G) → l_{f1t2y}Line(F_{2}, D) → l_{f2t2y}Line(F_{2}, F) → l_{f2t1y}PointIn(h) → PointhAsymptote(h) → l_{a2}, l_{a1}Vertex(h) → V_{1}, V_{2}, V_{3}, V_{4}SecondAxisLength(h) → bSecondAxisLength(h') → b'Excentricity(h') → c'Eccentricity(h') → e'Intersect(o, t'_{1y}) → E, IIntersect(t_{1x}, t_{1y}) → OIntersect(l_{r22}, l_{r11}) → R_{22}FirstAxisLength(h'') → a''SecondAxisLength(h'') → b''Excentricity(h'') → c''Intersect(t_{1y}, l_{f1t1y}) → T_{1y}Intersect(t_{2y}, l_{f2t2y}) → T_{2y}Segment(J, V'_{2}) → s_{f12}Segment(K, V'_{2}) → s_{f11}Segment(I, V'_{1}) → s_{f21}Segment(E, V'_{1}) → s_{f22}Intersect(t_{2x}, t_{2y}) → LSegment(N, F'_{11}) → s_{g11}Segment(O, F'_{11}) → s_{g12}Segment(L, F'_{21}) → s_{g21}Segment(F'_{21}, C) → s_{g22}Segment(F''_{11}, E) → s_{h11}Segment(F''_{11}, J) → s_{h12}Segment(R_{x}, T_{1x}) → s_{j1}Segment(R_{x}, T_{2x}) → s_{j2}Segment(R_{x}, R_{22}) → s_{r2}CircleArc(Point[{0, 0}], Point[{0, (-x(R_1))}], Point[{0, x(R_1)}]) → c_{aux1}Segment(R_{22}, Point[{0, y(R_{22})}]) → s_{r22}Line(Point[{0, x(R_{11})}], xAxis) → l_{r21}Intersect(l_{r21}, l_{r11}) → R_{21}Segment(R_{21}, Point[{0, y(R_{21})}]) → s_{r21}Segment(R_{x}, R_{21}) → s_{r1}Point(h') → z_{1}Directrix(h) → d_{2}, d_{1}Directrix(h') → d'_{2}, d'_{1}Point({imaginary(z_{1}), real(z'_{11})}) → z''_{11}Point({imaginary(z_{1}), real(z'_{12})}) → z''_{12}If(Defined[T_{1x}] ∧ Defined[T_{1y}], true, false) → h'MajorAxisIsxAxisFirstAxis(h') → e'_{x}Circle(F'_{11}, (2 * a')) → c'_{1}Circle(F'_{21}, (2 * a')) → c'_{2}Intersect(c'_{2}, t_{1y}) → P, QLineBisector(Q, F'_{11}) → t'_{2x}LineBisector(F'_{11}, P) → t'_{1x}Intersect(t'_{1x}, t'_{2y}) → RCircle(M', R) → o'Radius(o') → r'If(h'IsEllipse, Intersect[t_{1x}, yAxis]) → V''_{3}Segment(O, If[h'IsHyperbola, V''_{1}, V''_{3}]) → s_{i11}Segment(If[h'IsHyperbola, V''_{1}, V''_{3}], C) → s_{i12}Segment(If[h'IsHyperbola, V''_{2}, V''_{4}], L) → s_{i22}Segment(N, If[h'IsHyperbola, V''_{2}, V''_{4}]) → s_{i21}Segment(F''_{12}, I) → s_{h21}Segment(F''_{12}, K) → s_{h22}Eccentricity(h'') → e''FirstAxis(h'') → e''_{x}SecondAxis(h'') → e''_{y}Segment(T_{2x}, V'_{2}) → s_{f1d}Segment(T_{1x}, V'_{1}) → s_{f2d}