
Explore the Unit Circle
Loading the math board and drawing, please wait…
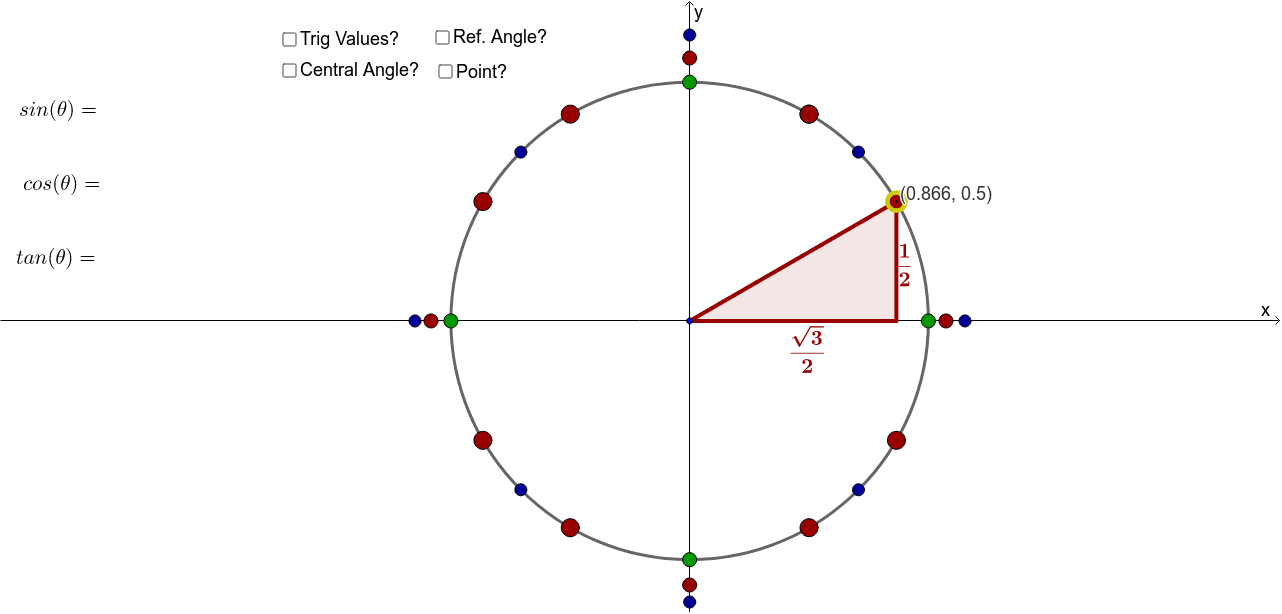
This example demonstrates the unit circle and its connection with special right triangles. It involves core mathematical concepts such as the definition of the unit circle, trigonometric values, and the side-angle relationships of special right triangles. The construction uses GeoGebra commands and objects like Point, Sequence, Segment, Min, If, Polygon, Element, Random, Angle, etc., to provide a dynamic visualization for better understanding. Suitable for high school mathematics teaching and learning trigonometry and geometry.
GeoGebra Commands & Parameters
Point(c) → ASequence(((π * k)) / 12, k, 0, 24) → AnglesSequence((cos(Element[Angles306090, k]), sin(Element[Angles306090, k])), k, 1, 9) → Pts306090Segment(O, B) → dMin(abs(Angles306090 - acos(x(A)))) → d306090Min(abs(Angles459045 - acos(x(A)))) → d459045Min(abs(AnglesVH - acos(x(A)))) → dVHIf((d306090 ≤ d459045) ∧ (d306090 ≤ dVH), 1, 0) → is306090If((d459045 < d306090) ∧ (d459045 < dVH), 1, 0) → is459045If((dVH < d306090) ∧ (dVH < d459045), 1, 0) → isVHIf(y(A) > 0, acos(x(A)), π + acos((-x(A)))) → thetaPolygon(O, A, B) → Triangle306090, b, o, aPolygon(O, A, B) → Triangle459045, b_1, o_1, a_1Polygon(O, A, B) → TriangleVH, b_2, o_2, a_2Sequence((cos(Element[Angles459045, k]), sin(Element[Angles459045, k])), k, 1, 4) → Pts459045Sequence((cos(Element[AnglesVH, k]), sin(Element[AnglesVH, k])), k, 1, 4) → PtsVHSequence((cos(Element[AnglesAll, k]), sin(Element[AnglesAll, k])), k, 1, Length[AnglesAll]) → PtsAllElement(AnglesAllLabels, 2) → FailRandom(1, 14) → randIntIf((π / 2 < theta) ∧ (theta < ((3 * π)) / 2), "-", "") → negCosIf(tan(theta) < 0, "-", "") → negTanAngle(O2, O, A) → alphaGreenIf(theta ≟ π / 3 ∨ theta ≟ (2 * π / 3) ∨ theta ≟ (4 * π / 3) ∨ theta ≟ (5 * π / 3), 1) → isTall306090If(theta ≟ π / 6 ∨ theta ≟ (5 * π / 6) ∨ theta ≟ (7 * π / 6) ∨ theta ≟ (11 * π / 6), 1) → isSkinny306090If(theta ≟ π / 4 ∨ theta ≟ (3 * π / 4) ∨ theta ≟ (5 * π / 4) ∨ theta ≟ (7 * π / 4), 1) → isReal459045If(theta ≟ 0 ∨ theta ≟ π ∨ theta ≟ (2 * π), 1) → isHPoint(xAxis) → CPoint(xAxis) → DPoint(xAxis) → EPoint(xAxis) → FPoint(yAxis) → GPoint(yAxis) → HPoint(yAxis) → IPoint(yAxis) → JPoint(c_1) → A_1Point(c_2) → A_2Angle(O2, O, A) → alphaRedAngle(O2, O, A) → alphaBluePoint(c_3) → A_3If(y(A_3) > 0, acos(x(A_3)), π + acos((-x(A_3)))) → theta_1If((π < theta) ∧ (theta < (2 * π)), "-", "") → negSin