
Conic Section Simulation
Loading the math board and drawing, please wait…
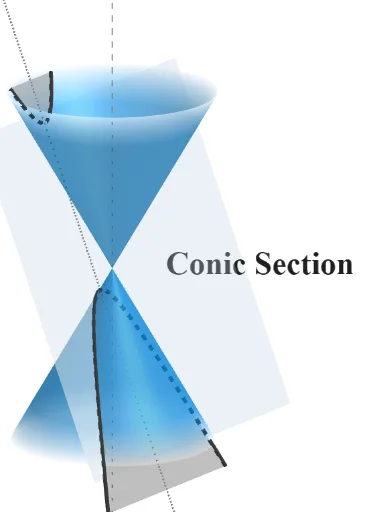
This example demonstrates the generation process of conic sections. Key mathematical concepts include the definition, equations, and properties of conic sections. Using GeoGebra commands such as InfiniteCone, Rotate, Intersect, etc., the dynamic generation of circles, ellipses, hyperbolas, and parabolas can be shown. Suitable for high school mathematics education and learning.
GeoGebra Commands & Parameters
InfiniteCone((0, 0, 3), Vector[(0, 0, 0), (0, 0, 1)], π / 6) → aPoint(f) → ALine(A, g) → hPoint(f) → BRotate(B, 30°, A) → B'Angle(B, A, B') → αLine(B, h) → iLine(A, B') → jIntersect(i, j) → CMirror(C, B) → C'Mirror(C, A) → C'_1Mirror(C', A) → C''Polygon(A, C'_1, C'') → 다각형1, c'', a_1, c'_1Polygon(A, C', C) → 다각형2, c, a_2, c'Angle(C, C', A) → βRotate(C, Slope, B) → C'_2Line(B, C'_2) → kAngle(C, B, C'_2) → δIntersectPath(xOyPlane, a) → dIntersect(f, yAxis) → DIntersect(g, d) → E, FIntersect(f, d) → G, HSemicircle(E, F, b) → eMidpoint(E, F) → IRotate(F, π / 2 - Slope, f) → F'Vector(I, F') → uOrthogonalPlane(I, u) → lIntersectPath(l, a) → pAngle(A, C, C') → εAngle(C'_2, B, C') → θLine((0, 0, 0), (0, 0, 1)) → mIntersectPath(l, a) → qIntersectPath(l, a) → rIntersectPath(l, a) → sIntersectPath(n, l) → tIntersectPath(n, a) → c_1Point(c'') → JLine(J, c'_1) → f_1IntersectPath(l, a) → d_1