
Adjustable Angle and Inclination of Line Segment
Loading the math board and drawing, please wait…
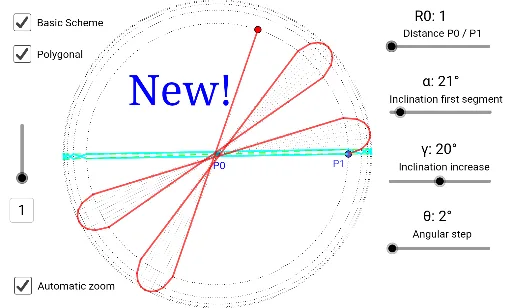
This example demonstrates how to adjust the angle and inclination of a line segment through rotation and tilting. Key mathematical concepts include angles, rotation, and geometric transformations. Using GeoGebra commands such as Rotate, Ray, and Intersect, the direction and position of the line segment can be dynamically changed. Suitable for middle school and above students to learn about geometric transformations and angle-related problems.
GeoGebra Commands & Parameters
Line(P0, A) → rt0Rotate(A, θ, P0) → A1Line(P0, A1) → rt1Rotate(B1, α, P1) → C1Ray(P1, C1) → sr1Intersect(rt1, sr1) → F1Circle(P0, F1) → c1If(x(F1) < x(P0), 1, 2) → SnDx1Intersect(c1, rt0, SnDx1) → P2Rotate(B2, α + γ, P2) → C2Ray(P2, C2) → sr2Intersect(rt1, sr2) → F2Rotate(F2, θ, P0) → W2If(x(F2) < x(P0), 1, 2) → SnDx2Circle(P0, F2) → c2Intersect(c2, rt0, SnDx2) → P3Rotate(B3, α + (2 * γ), P3) → C3Ray(P3, C3) → sr3Intersect(rt1, sr3) → F3Rotate(F3, (2 * θ), P0) → W3Circle(P0, F3) → c3If(x(F3) < x(P0), 1, 2) → SnDx3Intersect(c3, rt0, SnDx3) → P4Rotate(B4, α + (3 * γ), P4) → C4Ray(P4, C4) → sr4Intersect(rt1, sr4) → F4Rotate(F4, (3 * θ), P0) → W4If(x(F4) < x(P0), 1, 2) → SnDx4Circle(P0, F4) → c4Intersect(c4, rt0, SnDx4) → P5Rotate(B5, α + (4 * γ), P5) → C5Ray(P5, C5) → sr5Intersect(rt1, sr5) → F5Rotate(F5, (4 * θ), P0) → W5Circle(P0, F5) → c5If(x(F5) < x(P0), 1, 2) → SnDx5Intersect(c5, rt0, SnDx5) → P6Rotate(B6, α + (5 * γ), P6) → C6Ray(P6, C6) → sr6Intersect(rt1, sr6) → F6Rotate(F6, (5 * θ), P0) → W6If(x(F6) < x(P0), 1, 2) → SnDx6Circle(P0, F6) → c6Intersect(c6, rt0, SnDx6) → P7Rotate(B7, α + (6 * γ), P7) → C7Ray(P7, C7) → sr7Intersect(rt1, sr7) → F7Rotate(F7, (6 * θ), P0) → W7Circle(P0, F7) → c7If(x(F7) < x(P0), 1, 2) → SnDx7Intersect(c7, rt0, SnDx7) → P8Rotate(B8, α + (7 * γ), P8) → C8Ray(P8, C8) → sr8Intersect(rt1, sr8) → F8Rotate(F8, (7 * θ), P0) → W8If(x(F8) < x(P0), 1, 2) → SnDx8Circle(P0, F8) → c8Intersect(c8, rt0, SnDx8) → P9Rotate(B9, α + (8 * γ), P9) → C9Ray(P9, C9) → sr9Intersect(rt1, sr9) → F9Rotate(F9, (8 * θ), P0) → W9Circle(P0, F9) → c9If(x(F9) < x(P0), 1, 2) → SnDx9Intersect(c9, rt0, SnDx9) → P10Rotate(B10, α + (9 * γ), P10) → C10Ray(P10, C10) → sr10Intersect(rt1, sr10) → F10Rotate(F10, (9 * θ), P0) → W10If(x(F10) < x(P0), 1, 2) → SnDx10Circle(P0, F10) → c10Intersect(c10, rt0, SnDx10) → P11Rotate(B11, α + (10 * γ), P11) → C11Ray(P11, C11) → sr11Intersect(rt1, sr11) → F11Rotate(F11, (10 * θ), P0) → W11Circle(P0, F11) → c11If(x(F11) < x(P0), 1, 2) → SnDx11Intersect(c11, rt0, SnDx11) → P12Rotate(B12, α + (11 * γ), P12) → C12Ray(P12, C12) → sr12Intersect(rt1, sr12) → F12Rotate(F12, (11 * θ), P0) → W12If(x(F12) < x(P0), 1, 2) → SnDx12Circle(P0, F12) → c12Intersect(c12, rt0, SnDx12) → P13Rotate(B13, α + (12 * γ), P13) → C13Ray(P13, C13) → sr13Intersect(rt1, sr13) → F13Rotate(F13, (12 * θ), P0) → W13Circle(P0, F13) → c13If(x(F13) < x(P0), 1, 2) → SnDx13Intersect(c13, rt0, SnDx13) → P14Rotate(B14, α + (13 * γ), P14) → C14Ray(P14, C14) → sr14Intersect(rt1, sr14) → F14Rotate(F14, (13 * θ), P0) → W14If(x(F14) < x(P0), 1, 2) → SnDx14Circle(P0, F14) → c14Intersect(c14, rt0, SnDx14) → P15Rotate(B15, α + (14 * γ), P15) → C15Ray(P15, C15) → sr15Intersect(rt1, sr15) → F15Rotate(F15, (14 * θ), P0) → W15Circle(P0, F15) → c15If(x(F15) < x(P0), 1, 2) → SnDx15Intersect(c15, rt0, SnDx15) → P16Rotate(B16, α + (15 * γ), P16) → C16Ray(P16, C16) → sr16Intersect(rt1, sr16) → F16Rotate(F16, (15 * θ), P0) → W16If(x(F16) < x(P0), 1, 2) → SnDx16Circle(P0, F16) → c16Intersect(c16, rt0, SnDx16) → P17Rotate(B17, α + (16 * γ), P17) → C17Ray(P17, C17) → sr17Intersect(rt1, sr17) → F17Rotate(F17, (16 * θ), P0) → W17Circle(P0, F17) → c17If(x(F17) < x(P0), 1, 2) → SnDx17Intersect(c17, rt0, SnDx17) → P18Rotate(B18, α + (17 * γ), P18) → C18Ray(P18, C18) → sr18Intersect(rt1, sr18) → F18Rotate(F18, (17 * θ), P0) → W18If(x(F18) < x(P0), 1, 2) → SnDx18Circle(P0, F18) → c18Intersect(c18, rt0, SnDx18) → P19Rotate(B19, α + (18 * γ), P19) → C19Ray(P19, C19) → sr19Intersect(rt1, sr19) → F19Rotate(F19, (18 * θ), P0) → W19Circle(P0, F19) → c19If(x(F19) < x(P0), 1, 2) → SnDx19Intersect(c19, rt0, SnDx19) → P20Rotate(B20, α + (19 * γ), P20) → C20Ray(P20, C20) → sr20Intersect(rt1, sr20) → F20Rotate(F20, (19 * θ), P0) → W20If(x(F20) < x(P0), 1, 2) → SnDx20Circle(P0, F20) → c20Intersect(c20, rt0, SnDx20) → P21Rotate(B21, α + (20 * γ), P21) → C21Ray(P21, C21) → sr21Intersect(rt1, sr21) → F21Rotate(F21, (20 * θ), P0) → W21Circle(P0, F21) → c21If(x(F21) < x(P0), 1, 2) → SnDx21Intersect(c21, rt0, SnDx21) → P22Rotate(B22, α + (21 * γ), P22) → C22Ray(P22, C22) → sr22Intersect(rt1, sr22) → F22Rotate(F22, (21 * θ), P0) → W22If(x(F22) < x(P0), 1, 2) → SnDx22Circle(P0, F22) → c22Intersect(c22, rt0, SnDx22) → P23Rotate(B23, α + (22 * γ), P23) → C23Ray(P23, C23) → sr23Intersect(rt1, sr23) → F23Rotate(F23, (22 * θ), P0) → W23Circle(P0, F23) → c23If(x(F23) < x(P0), 1, 2) → SnDx23Intersect(c23, rt0, SnDx23) → P24Rotate(B24, α + (23 * γ), P24) → C24Ray(P24, C24) → sr24Intersect(rt1, sr24) → F24Rotate(F24, (23 * θ), P0) → W24If(x(F24) < x(P0), 1, 2) → SnDx24Circle(P0, F24) → c24Intersect(c24, rt0, SnDx24) → P25Rotate(B25, α + (24 * γ), P25) → C25Ray(P25, C25) → sr25Intersect(rt1, sr25) → F25Rotate(F25, (24 * θ), P0) → W25Circle(P0, F25) → c25If(x(F25) < x(P0), 1, 2) → SnDx25Intersect(c25, rt0, SnDx25) → P26Rotate(B26, α + (25 * γ), P26) → C26Ray(P26, C26) → sr26Intersect(rt1, sr26) → F26Rotate(F26, (25 * θ), P0) → W26If(x(F26) < x(P0), 1, 2) → SnDx26Circle(P0, F26) → c26Intersect(c26, rt0, SnDx26) → P27Rotate(B27, α + (26 * γ), P27) → C27Ray(P27, C27) → sr27Intersect(rt1, sr27) → F27Rotate(F27, (26 * θ), P0) → W27Circle(P0, F27) → c27If(x(F27) < x(P0), 1, 2) → SnDx27Intersect(c27, rt0, SnDx27) → P28Rotate(B28, α + (27 * γ), P28) → C28Ray(P28, C28) → sr28Intersect(rt1, sr28) → F28Rotate(F28, (27 * θ), P0) → W28If(x(F28) < x(P0), 1, 2) → SnDx28Circle(P0, F28) → c28Intersect(c28, rt0, SnDx28) → P29Rotate(B29, α + (28 * γ), P29) → C29Ray(P29, C29) → sr29Intersect(rt1, sr29) → F29Rotate(F29, (28 * θ), P0) → W29Circle(P0, F29) → c29If(x(F29) < x(P0), 1, 2) → SnDx29Intersect(c29, rt0, SnDx29) → P30Rotate(B30, α + (29 * γ), P30) → C30Ray(P30, C30) → sr30Intersect(rt1, sr30) → F30Rotate(F30, (29 * θ), P0) → W30If(x(F30) < x(P0), 1, 2) → SnDx30Circle(P0, F30) → c30Intersect(c30, rt0, SnDx30) → P31Rotate(B31, α + (30 * γ), P31) → C31Ray(P31, C31) → sr31Intersect(rt1, sr31) → F31Rotate(F31, (30 * θ), P0) → W31Circle(P0, F31) → c31If(x(F31) < x(P0), 1, 2) → SnDx31Intersect(c31, rt0, SnDx31) → P32Rotate(B32, α + (31 * γ), P32) → C32Ray(P32, C32) → sr32Intersect(rt1, sr32) → F32Rotate(F32, (31 * θ), P0) → W32If(x(F32) < x(P0), 1, 2) → SnDx32Circle(P0, F32) → c32Intersect(c32, rt0, SnDx32) → P33Rotate(B33, α + (32 * γ), P33) → C33Ray(P33, C33) → sr33Intersect(rt1, sr33) → F33Rotate(F33, (32 * θ), P0) → W33Circle(P0, F33) → c33If(x(F33) < x(P0), 1, 2) → SnDx33Intersect(c33, rt0, SnDx33) → P34Rotate(B34, α + (33 * γ), P34) → C34Ray(P34, C34) → sr34Intersect(rt1, sr34) → F34Rotate(F34, (33 * θ), P0) → W34If(x(F34) < x(P0), 1, 2) → SnDx34Circle(P0, F34) → c34Intersect(c34, rt0, SnDx34) → P35Rotate(B35, α + (34 * γ), P35) → C35Ray(P35, C35) → sr35Intersect(rt1, sr35) → F35Rotate(F35, (34 * θ), P0) → W35Circle(P0, F35) → c35If(x(F35) < x(P0), 1, 2) → SnDx35Intersect(c35, rt0, SnDx35) → P36Rotate(B36, α + (35 * γ), P36) → C36Ray(P36, C36) → sr36Intersect(rt1, sr36) → F36Rotate(F36, (35 * θ), P0) → W36Circle(P0, F36) → c36If(x(F36) < x(P0), 1, 2) → SnDx36Intersect(c36, rt0, SnDx36) → P37Max(RemoveUndefined[{MxP1, MxP2, MxP3, MxP4, MxP5, MxP6, MxP7, MxP8, MxP9, MxP10, MxP11, MxP12, MxP13, MxP14, MxP15, MxP16, MxP17, MxP18, MxP19, MxP20, MxP21, MxP22, MxP23, MxP24, MxP25, MxP26, MxP27, MxP28, MxP29, MxP30, MxP31, MxP32, MxP33, MxP34, MxP35, MxP36, MxP37}]) → QuadMaxXSegment(P1, F1) → sp1Segment(P2, F2) → g_2Segment(P3, F3) → i_2Segment(P4, F4) → k_2Circle(P0, P1) → c0Segment(P5, F5) → m_2Segment(P6, F6) → r_2Segment(P7, F7) → a_2Segment(P8, F8) → f_3Segment(P9, F9) → h_3Segment(P10, F10) → j_3Segment(P11, F11) → m_3Segment(P12, F12) → q_3Segment(P13, F13) → t_3Segment(P14, F14) → b_3Segment(P15, F15) → g_4Segment(P16, F16) → i_4Segment(P17, F17) → l_4Segment(P18, F18) → n_4Segment(P19, F19) → s_4Segment(P20, F20) → b_4Segment(P21, F21) → g_5Segment(P22, F22) → i_5Segment(P23, F23) → k_5Segment(P24, F24) → m_5Segment(P25, F25) → r_5Segment(P26, F26) → a_5Segment(P27, F27) → f_6Segment(P28, F28) → h_6Segment(P29, F29) → j_6Segment(P30, F30) → m_6Segment(P31, F31) → q_6Segment(P32, F32) → t_6Segment(P33, F33) → b_6Segment(P34, F34) → g_7Segment(P35, F35) → i_7Segment(P36, F36) → l_7Segment(P1, F1) → m_7Segment(F1, W2) → sp2Segment(W2, W3) → sp3Segment(W3, W4) → sp4Segment(W4, W5) → sp5Segment(W5, W6) → sp6Segment(W6, W7) → sp7Segment(W7, W8) → sp8Segment(W8, W9) → sp9Segment(W9, W10) → sp10Segment(W10, W11) → sp11Segment(W11, W12) → sp12Segment(W12, W13) → sp13Segment(W13, W14) → sp14Segment(W14, W15) → sp15Segment(W15, W16) → sp16Segment(W16, W17) → sp17Segment(W17, W18) → sp18Segment(W18, W19) → sp19Segment(W19, W20) → sp20Segment(W20, W21) → sp21Segment(W21, W22) → sp22Segment(W22, W23) → sp23Segment(W23, W24) → sp24Segment(W24, W25) → sp25Segment(W25, W26) → sp26Segment(W26, W27) → sp27Segment(W27, W28) → sp28Segment(W28, W29) → sp29Segment(W29, W30) → sp30Segment(W30, W31) → sp31Segment(W31, W32) → sp32Segment(W32, W33) → sp33Segment(W33, W34) → sp34Segment(W34, W35) → sp35Segment(W35, W36) → sp36Segment(P0, W2) → sg2Segment(P0, W3) → sg3Segment(P0, W4) → sg4Segment(P0, W5) → sg5Segment(P0, W6) → sg6Segment(P0, W7) → sg7Segment(P0, W8) → sg8Segment(P0, W9) → sg9Segment(P0, W10) → sg10Segment(P0, W11) → sg11Segment(P0, W12) → sg12Segment(P0, W13) → sg13Segment(P0, W14) → sg14Segment(P0, W15) → sg15Segment(P0, W16) → sg16Segment(P0, W17) → sg17Segment(P0, W18) → sg18Segment(P0, W19) → sg19Segment(P0, W20) → sg20Segment(P0, W21) → sg21Segment(P0, W22) → sg22Segment(P0, W23) → sg23Segment(P0, W24) → sg24Segment(P0, W25) → sg25Segment(P0, W26) → sg26Segment(P0, W27) → sg27Segment(P0, W28) → sg28Segment(P0, W29) → sg29Segment(P0, W30) → sg30Segment(P0, W31) → sg31Segment(P0, W32) → sg32Segment(P0, W33) → sg33Segment(P0, W34) → sg34Segment(P0, W35) → sg35Segment(P0, W36) → sg36Textfield(CN) → CampoInserimento1Segment(PS, PD) → sg0Rotate(PS, θ) → ASRotate(PD, θ) → ADSegment(AS, AD) → sg1Last(RemoveUndefined[{W1, W2, W3, W4, W5, W6, W7, W8, W9, W10, W11, W12, W13, W14, W15, W16, W17, W18, W19, W20, W21, W22, W23, W24, W25, W26, W27, W28, W29, W30, W31, W32, W33, W34, W35, W36}]) → AAAMidpoint(sp1) → Pm1Midpoint(sp2) → Pm2OrthogonalLine(Pm1, sp1) → perp1OrthogonalLine(Pm2, sp2) → perp2Intersect(perp1, perp2) → CeCeCircle(CeCe, P1) → cerchietto
AI Drawing Prompt Reference
Draw a line segment that can be adjusted for angle and inclination. Start by drawing a line segment rt0 through point P0 and point A. Then, rotate point A around point P0 to get point A1, and draw a new line segment rt1 through P0 and A1. Next, rotate point B1 around point P1 to get point C1, and draw a ray sr1 through P1 and C1. The line segment rt1 and the ray sr1 intersect at point F1. Repeat this process by rotating and intersecting to gradually adjust the direction and position of the line segment, ultimately resulting in multiple rotated line segments and points.
The prompt above was compiled from the original drawing commands and is for reference only.