
俄罗斯足球与数学构造
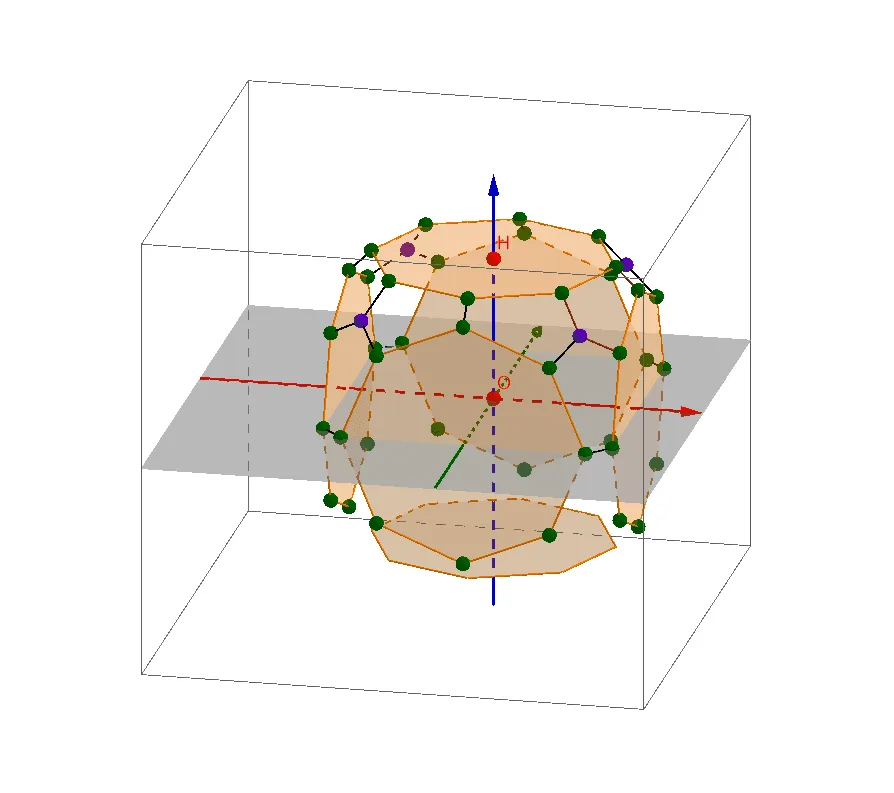
几何画板及绘图内容加载中,请稍等……
①本范例通过动态演示俄罗斯足球的几何构造,揭示其复杂的几何对称性与空间关系;②涉及的核心数学概念包括向量、矩阵变换、旋转、反射、多边形构造及正交中心;③作图要点提炼自构造摘要,运用了Point、Vector、Mirror、Polygon、Rotate、Segment、Sphere、OrthogonalPlane、Circle、Center、Ray、Intersect、Distance等GeoGebra命令与对象;④适合高中及以上数学学习者,用于理解空间几何、线性代数及变换理论的实际应用。
GeoGebra 命令及参数
Point(zAxis) → HVector(O, H) → uMirror(A, yAxis) → A'Polygon(A, A', 8) → poly1, f, C, D, E, F, G, g, h, i, j, k, l, m, BRotate(Translate[Lo, u], 22.5°, zAxis) → Lo'Point(Lo') → IPoint(Lo') → JPoint(Lo') → KRotate(Lo', 90°, xAxis) → Lo''Rotate(Rotate[Lo', 90°, xAxis], 22.5°, yAxis) → liste1Rotate(Translate[Lo, u], 45°, zAxis) → poly1'Point(Lo') → LPoint(Lo'') → MSegment(L, M) → nRotate(Lo'', 90°, zAxis) → LbRotate(Lb, 90°, zAxis) → LcRotate(Lc, 90°, zAxis) → LdPoint(Lo') → NSphere(O, N) → aPoint(Lo') → PPoint(Lb) → QSegment(P, Q) → pPoint(Lo'') → RPoint(Lo'') → SOrthogonalPlane(O, xAxis) → dPoint(Lb) → UCircle(N, S, U) → eCenter(e) → VSphere(O, N) → bPoint(Lo'') → TPoint(Lb) → WSegment(T, W) → tRay(O, V) → cIntersect(c, b) → Z,Polygon(P, Q, U, Z, N) → poly2, p_1, q, u_1, z_1, n_1Segment(S, Z) → rRotate(Z, 90°, zAxis) → Z'Rotate(Z', 90°, zAxis) → Z''Rotate(Z'', 90°, zAxis) → Z'''Point(Lo') → A_1Segment(A_1, Z''') → sSegment(R, Z''') → f_1Point(Ld) → B_1Segment(Z''', B_1) → g_1Point(Ld) → C_1Point(Lo') → D_1Segment(C_1, D_1) → h_1Point(Lo') → E_1Segment(E_1, Z'') → i_1Point(Ld) → F_1Segment(Z'', F_1) → j_1Point(Lc) → G_1Segment(Z'', G_1) → k_1Point(Lo') → H_1Segment(H_1, Z') → l_1Point(Lc) → I_1Segment(Z', I_1) → m_1Point(Lb) → J_1Segment(Z', J_1) → q_1Point(Lb) → K_1Point(Lc) → L_1Segment(K_1, L_1) → r_1Point(Lc) → M_1Point(Ld) → N_1Segment(M_1, N_1) → s_1Point(Ld) → O_1Point(Lo'') → P_1Segment(O_1, P_1) → t_1Point(Lc) → R_1Point(Lo') → S_1Segment(R_1, S_1) → a_1Point(Lo'') → Q_1Point(Lo'') → T_1Point(Lo'') → U_1Point(Lo'') → V_1Point(Lo'') → W_1Point(Lo'') → Z_1Point(Lo'') → A_2Point(Lo'') → B_2Rotate(Translate[poly1, u], 22.5°, zAxis) → poly4Rotate(poly4, 90°, xAxis) → poly4'Rotate(poly4', 90°, zAxis) → poly4''Rotate(poly4'', 90°, zAxis) → poly4'''Rotate(poly4', -90°, zAxis) → poly4''_1Mirror(poly4, O) → poly4'_1Distance(O, H) → distanceOH