
非灯几何体演示
几何画板及绘图内容加载中,请稍等……
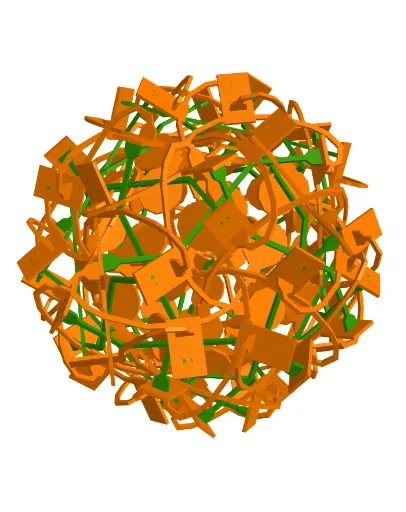
①本范例演示一个非传统几何体(十二面体)的构造与特性;②涉及核心数学概念包括立体几何、中点、线面关系、正态分布(用于点生成)、坐标几何;③构造中运用了点、十二面体、中点、线、交点、平移、射线、旋转、垂线、路径交点、距离、点在路径上、圆、镜像、多边形、序列等GeoGebra命令;④适合高中及以上学生用于立体几何学习和空间想象能力培养。
GeoGebra 命令及参数
Point(Circle[((A * (1 - sqrt(5))) + (B * (3 + sqrt(5)))) / 4, (Distance[A, B] * sqrt(10 + (2 * sqrt(5))) / 4), Segment[A, B]]) → CDodecahedron(A, B, C) → a, D, M, N, O, P, Q, R, S, T, 면ABCDE, 면AEIOJ, E, 면ABFKJ, 면BCGLF, 면CDHMG, 면DEINH, 면INSTO, 면JKPTO, 면FKPQL, 면GLQRM, 면HMRSN, 면PQRST, F, 모서리AE, 모서리AB, 모서리BC, 모서리CD, 모서리DE, 모서리AJ, 모서리EI, 모서리IO, 모서리JO, 모서리JK, G, 모서리FK, 모서리BF, 모서리FL, 모서리GL, 모서리CG, 모서리GM, 모서리HM, 모서리DH, 모서리HN, 모서리IN, H, 모서리NS, 모서리ST, 모서리OT, 모서리PT, 모서리KP, 모서리PQ, 모서리LQ, 모서리QR, 모서리MR, 모서리RS, I, J, K, LMidpoint(A, R) → ULine(P, L) → hLine(Q, G) → gLine(Q, K) → fIntersect(h, f) → VTranslate(V, Vector[(0.9 * u)]) → WTranslate(W, Vector[(-5.2 * u) - (3.3 * v)]) → W'_1Translate(W, Vector[(2 * v)]) → W'Translate(W', Vector[(0.6 * u)]) → W''Plane(g, f) → pRay(U, l3(A12)) → B12Ray(U, Centroid[l2(A6)]) → C6Rotate(Rotate[W'', (-(72°)), C6], 120°, B12) → P_1Rotate(Rotate[W', (-(72°)), C6], 120°, B12) → O_1Rotate(Rotate[p, (-(72°)), C6], 120°, B12) → qOrthogonalLine(O_1, q) → nPlane(P_1, n) → rIntersectPath(p, r) → sPoint(s) → U_1OrthogonalLine(U_1, s, p) → cDistance(U, J) → bTranslate(W, Vector[(0.2 * u)]) → ZTranslate(W, Vector[(0.6 * u)]) → A_1Translate(W, Vector[(1.7 * u)]) → C_1Translate(V, Vector[(3.4 * v)]) → B_1Translate(C_1, Vector[(3.4 * v)]) → D_1Translate(C_1, Vector[(-1.1 * v)]) → E_1Translate(V, Vector[(-1.1 * v)]) → F_1Translate(V, Vector[(-0.5 * v)]) → V'Translate(V, Vector[(-0.9 * v)]) → V'_1Translate(C_1, Vector[(-0.9 * v)]) → G_1Translate(C_1, Vector[(-0.5 * v)]) → H_1Translate(Q, Vector[(-((Distance[Q, W] * v)))]) → I_1Translate(I_1, Vector[(0.3 * u)]) → J_1Translate(I_1, Vector[(0.3 * u) + (0.2 * v)]) → K_1Translate(I_1, Vector[(0.2 * v)]) → L_1Translate(J_1, Vector[(-((0.3 * v)))]) → M_1Translate(J_1, Vector[(1.1 * v)]) → N_1Ray(U, l3(A1)) → B1Ray(U, l3(A2)) → B2Ray(U, l3(A3)) → B3Ray(U, l3(A4)) → B4Ray(U, l3(A5)) → B5Ray(U, l3(A6)) → B6Ray(U, l3(A7)) → B7Ray(U, l3(A8)) → B8Ray(U, l3(A9)) → B9Ray(U, l3(A10)) → B10Ray(U, l3(A11)) → B11Ray(U, l3(A13)) → B13Ray(U, l3(A14)) → B14Ray(U, l3(A15)) → B15Ray(U, l3(A16)) → B16Ray(U, l3(A17)) → B17Ray(U, l3(A18)) → B18Ray(U, l3(A19)) → B19Ray(U, l3(A20)) → B20Ray(U, Centroid[l2(A1)]) → C1Ray(U, Centroid[l2(A2)]) → C2Ray(U, Centroid[l2(A3)]) → C3Ray(U, Centroid[l2(A4)]) → C4Ray(U, Centroid[l2(A5)]) → C5Ray(U, Centroid[l2(A7)]) → C7Ray(U, Centroid[l2(A8)]) → C8Ray(U, Centroid[l2(A9)]) → C9Ray(U, Centroid[l2(A10)]) → C10Ray(U, Centroid[l2(A11)]) → C11Ray(U, Centroid[l2(A12)]) → C12Translate(W, Vector[(-3.5 * u) - (1.4 * v)]) → W'_2Translate(W'_1, Vector[(0.4 * UnitVector[c])]) → R_1Line(R_1, W'_1) → tTranslate(W'_1, Vector[(0.3 * UnitVector[t])]) → S_1Translate(R_1, Vector[(-0.3 * UnitVector[t])]) → T_1Translate(U_1, Vector[(0.3 / tan(36°) * UnitVector[c])]) → V_1Point(s) → W_1Translate(V_1, Vector[U_1, W_1]) → Z_1Point(Circle[W'_2, 0.4, p]) → Q_1OrthogonalLine(S_1, t, p) → dTranslate(S_1, Vector[(1.3 * UnitVector[d])]) → A_2Translate(T_1, Vector[(1.3 * UnitVector[d])]) → B_2PointIn(p) → C_2PointIn(p) → D_2PointIn(p) → E_2Point(d) → F_2PointIn(p) → G_2PointIn(p) → H_2PointIn(p) → I_2PointIn(p) → J_2PointIn(p) → K_2PointIn(p) → L_2Translate(N_1, Vector[(1.25 * u) - (0.5 * v)]) → M_2Translate(N_1, Vector[(1.25 * u) - (0.9 * v)]) → N_2PointIn(p) → O_2PointIn(p) → P_2PointIn(p) → Q_2PointIn(p) → R_2PointIn(p) → S_2PointIn(p) → V_2PointIn(p) → W_2PointIn(p) → Z_2PointIn(p) → A_3PointIn(p) → B_3Rotate(Rotate[Rotate[W', 72°, C6], (-(120°)), B16], (-(144°)), C2) → C_3Rotate(Rotate[Rotate[W'', 72°, C6], (-(120°)), B16], (-(144°)), C2) → D_3Line(C_3, D_3) → eLine(O_1, P_1) → i_1Translate(P_1, Vector[(0.2 * UnitVector[i_1])]) → H_3Translate(O_1, Vector[(0.2 * UnitVector[i_1])]) → I_3OrthogonalLine(P_1, i_1, r) → j_1Translate(P_1, Vector[(-0.3 * UnitVector[j_1])]) → J_3Translate(H_3, Vector[(-0.3 * UnitVector[j_1])]) → K_3Translate(I_3, Vector[(-0.3 * UnitVector[j_1])]) → L_3Translate(O_1, Vector[(-0.3 * UnitVector[j_1])]) → M_3Circle(V, 4.2, r) → c_1Translate(O_1, Vector[(-0.3 * UnitVector[i_1])]) → N_3Translate(H_3, Vector[(0.3 * UnitVector[i_1])]) → O_3Translate(I_3, Vector[(1.25 * UnitVector[j_1])]) → P_3Translate(P_1, Vector[(1.25 * UnitVector[j_1])]) → Q_3Translate(Q_3, Vector[(-0.4 * UnitVector[j_1]) + (0.4 * UnitVector[i_1])]) → H_4Translate(P_3, Vector[(-0.4 * UnitVector[j_1]) - (0.4 * UnitVector[i_1])]) → I_4Midpoint(D_3, P_1) → E_3Translate(V_1, Vector[(-0.3 * UnitOrthogonalVector[p])]) → F_3Line(Q_3, j_1) → k_1Mirror(W_1, E_3) → G_3Line(G_3, F_3) → l_1Line(W_1, l_1) → a_1Line(P_3, j_1) → f_3Line(P_3, Q_3) → g_3Intersect(s, g_3) → R_3Intersect(k_1, l_1) → S_3Intersect(a_1, f_3) → T_3Mirror(G_3, E_3) → U_3Mirror(F_3, E_3) → V_3Mirror(S_3, E_3) → W_3Mirror(Q_3, E_3) → Z_3Mirror(H_4, E_3) → A_4Mirror(O_3, E_3) → B_4Mirror(P_1, E_3) → C_4Mirror(J_3, E_3) → D_4Mirror(K_3, E_3) → E_4Mirror(H_3, E_3) → F_4Mirror(O_1, E_3) → G_4Mirror(M_3, E_3) → J_4Mirror(L_3, E_3) → K_4Mirror(I_3, E_3) → L_4Mirror(N_3, E_3) → M_4Mirror(I_4, E_3) → N_4Mirror(P_3, E_3) → O_4Mirror(T_3, E_3) → P_4Mirror(W_1, E_3) → Q_4Translate(M_2, Vector[(-0.4 * u) + (0.4 * v)]) → T_2Translate(N_2, Vector[(-0.4 * u) - (0.4 * v)]) → U_2Translate(J_1, Vector[(0.6 * v)]) → R_4Translate(I_1, Vector[(0.6 * v)]) → S_4Translate(L_1, Vector[(0.6 * v)]) → T_4Translate(K_1, Vector[(0.6 * v)]) → U_4Polygon(V', B_1, U_2, M_1, J_1, I_1, L_1, K_1, R_4, S_4, T_4, U_4, D_1, N_1, T_2, M_2, S_2, R_2, Q_2, P_2, O_2, G_1, E_1, H_1, F_1, V'_1, L_2, Q_1, R_1, T_1, B_2, K_2, J_2, I_2, B_3, H_2, G_2, F_2, E_2, W_1, Z_1, V_1, U_1, D_2, A_2, A_3, S_1, W'_1, W'_2, C_2, Z_2, W_2, V_2, N_2) → 다각형1, i, n_1, p_1, q_1, r_1, s_1, t_1, b_1, d_1, e_1, f_2, j, g_2, h_2, i_2, j_2, k_2, l_2, m_2, n_2, p_2, q_2, k, r_2, s_2, t_2, a_2, b_2, c_2, d_2, e_2, h_3, a_3, l, b_3, r_4, s_4, t_4, l_5, m_5, n_5, p_5, q_5, r_5, m, s_5, t_5, a_5, b_5, c_5, f_1, g_1, h_1, m_1Polygon(O_3, H_4, L_4, K_4, J_4, C_3, F_4, E_4, D_4, C_4, B_4, A_4, Q_3, Z_3, W_3, V_3, W_1, T_3, P_3, I_4, N_3, I_3, L_3, S_3, M_3, O_1, H_3, K_3, J_3, P_1, F_3, G_3, P_4, O_4, N_4, M_4) → 다각형2, i_3, s_3, t_3, c_3, d_3, e_3, f_4, g_4, h_4, i_4, j_4, j_3, k_4, l_4, m_4, n_4, p_4, q_4, a_4, b_4, c_4, d_4, k_3, e_4, f_5, g_5, h_5, i_5, j_5, k_5, l_3, m_3, n_3, p_3, q_3, r_3Sequence(Rotate[Prism[다각형1, -0.3], ((ω * 2) * π / 5), C6], ω, 0, 4) → l4Rotate(Prism[다각형2, 0.3], 120°, B11) → oRotate(l4, 120°, B17) → l4'Rotate(l4', 120°, B17) → l4''Rotate(l4', 120°, B13) → l4''_1Rotate(l4''_1, 120°, B13) → l5Rotate(l5, 120°, B14) → l5'Rotate(l5', 120°, B14) → l5''Rotate(l5'', 120°, B15) → l5'''Rotate(l5''', 120°, B15) → l6Rotate(l4, 120°, B6) → l4'_1Rotate(l4'_1, 120°, B6) → l7Rotate(l7, 120°, B3) → l7'Rotate(o, 120°, B16) → o'Rotate(o', 120°, B16) → o''Rotate(o', 120°, B17) → o''_1Rotate(o''_1, 120°, B17) → wRotate(w, 120°, B18) → w'Rotate(w', 120°, B18) → w''Rotate(w'', 120°, B19) → w'''Rotate(w''', 120°, B19) → o_1Rotate(w''', 120°, B14) → u_1Rotate(u_1, 120°, B14) → v_1Rotate(v_1, 120°, B9) → w_1Rotate(w_1, 120°, B9) → o_2Rotate(o_2, 120°, B15) → u_2Rotate(u_2, 120°, B15) → v_2Rotate(u_2, 120°, B10) → w_2Rotate(w_2, 120°, B10) → o_3Rotate(o_3, 120°, B11) → u_3Rotate(u_3, 120°, B6) → v_3Rotate(v_3, 120°, B6) → w_3Rotate(w_3, 120°, B12) → o_4Rotate(o_4, 120°, B7) → u_4Rotate(u_4, 120°, B7) → v_4Rotate(v_4, 120°, B13) → w_4Rotate(w_4, 120°, B8) → d_5Rotate(w_1, 120°, B5) → e_5Rotate(e_5, 120°, B5) → o_5Rotate(o_5, 120°, B1) → u_5Rotate(u_5, 120°, B2) → v_5Rotate(v_5, 120°, B3) → w_5