
椭圆与魔幻和
几何画板及绘图内容加载中,请稍等……
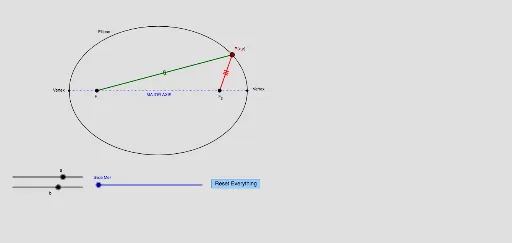
①本范例演示了椭圆的几何性质,特别是焦点、顶点与椭圆内部点的距离关系;②涉及的核心数学概念包括椭圆的定义、焦点性质、向量运算、参数方程等;③作图要点——从『构造摘要』提炼用到了Focus(焦点)、Vertex(顶点)、Segment(线段)、Translate(平移)、Point(点)、Vector(向量)、Dilate(缩放)、Angle(角度)、Rotate(旋转)、Circle(圆)、Center(中心)、Intersect(交点)等GeoGebra命令/对象;④适合高中及以上学生学习和探索椭圆的几何特性,也可用于参数方程与向量运算的教学。
GeoGebra 命令及参数
Focus(c) → F_1, F_2Vertex(c) → C, D, E, FSegment(C, D) → dTranslate(C, (0, b + 4)) → C'Translate(D, (0, b + 4)) → D'Point(c) → GSegment(G, F_1) → eSegment(G, F_2) → fTranslate(C, (b + 4, 0)) → C'_1Vector(C, C') → uVector(D, D') → vDilate(C, If[0 < n < 1, 1 - n, 0], C') → C'_2Dilate(D, If[0 < n < 1, 1 - n, 0], D') → D'_2Dilate(F_1, If[1 < n < 2, 2 - n, 1], C') → A'Vector(F_1, A') → wTranslate(G, w) → G'Segment(A', G') → mAngle(F_2, F_1, G) → αRotate(A', If[1 < n < 2, ((-(2 - n)) * α)], A') → A''Rotate(A', If[1 < n < 2, ((-(n - 2)) * α), 0], A'') → A''_1Rotate(A', If[1 < n < 2, ((-(n - 1)) * α), (-α)], A') → A''_2Rotate(G', If[1 < n < 2, ((-(n - 1)) * α), (-α)], A') → G''Circle(C', e) → qSegment(F_1, G) → sDilate(F_2, If[2 < n < 3, 3 - n, 1], D') → B'Vector(F_2, B') → tTranslate(G, t) → G'_2Translate(F_2, t) → B'_1Segment(G'_2, B'_1) → f'Angle(G, F_2, F_1) → βRotate(G'_2, If[2 < n < 3, ((n - 2) * β)], B') → LRotate(B'_1, If[2 < n < 3, ((n - 2) * β)], B') → MSegment(G, F_2) → b_1Center(c) → ASegment(A, G) → c_1Segment(A, G) → d_1Dilate(A, If[1 < n < 2, 2 - n, 0], C') → A'_1Vector(F_1, A'_1) → u_1Translate(A, u_1) → A'_2Angle(D, F_1, G) → γRotate(A'_2, ((-(n - 1)) * γ), A'_2) → BCircle(C, e) → pIntersect(p, d, 1) → HDilate(F_1, If[0 < n < 1, 1 - n, 1], C) → IVector(F_1, I) → lTranslate(G, l) → G'_1Translate(F_1, l) → JSegment(G'_1, J) → e'Rotate(G'_1, If[0 < n < 1, (-((n * α))), (-α)], I) → KRotate(J, If[0 < n < 1, (-((n * α))), (-α)], I) → J'Segment(K, J') → e''Segment(C, H) → rDilate(F_2, If[1 < n < 2, 2 - n, 1], D) → NVector(F_2, N) → v_1Translate(G, v_1) → G'_3Translate(F_2, v_1) → OSegment(G'_3, O) → f'_1Rotate(G'_3, If[1 < n < 2, ((n - 1) * β), β], N) → PRotate(O, If[1 < n < 2, ((n - 1) * β), β], N) → O'Segment(P, O') → a_1Segment(D, H) → e_1Dilate(F_1, 1 - n, C) → QVector(F_1, Q) → hTranslate(A, h) → A'_3Translate(G, h) → G'_4Segment(A'_3, G'_4) → iAngle(D, Center[c], G) → δRotate(A'_3, If[0 < n < 1, (-((n * δ)))], Q) → RRotate(G'_4, If[0 < n < 1, (-((n * δ)))], Q) → SSegment(R, S) → i'Dilate(F_2, If[1 < n < 2, 2 - n], D) → TVector(F_1, T) → w_1Translate(A, w_1) → A'_4Translate(G, w_1) → G'_5Segment(A'_4, G'_5) → f_1Angle(G, Center[c], C) → εRotate(A'_4, If[1 < n < 2, ((n - 1) * ε)], A'_4) → URotate(G'_5, If[1 < n < 2, ((n - 1) * ε)], A'_4) → VSegment(U, V) → g_1