
滑轮中的运动方程应用
几何画板及绘图内容加载中,请稍等……
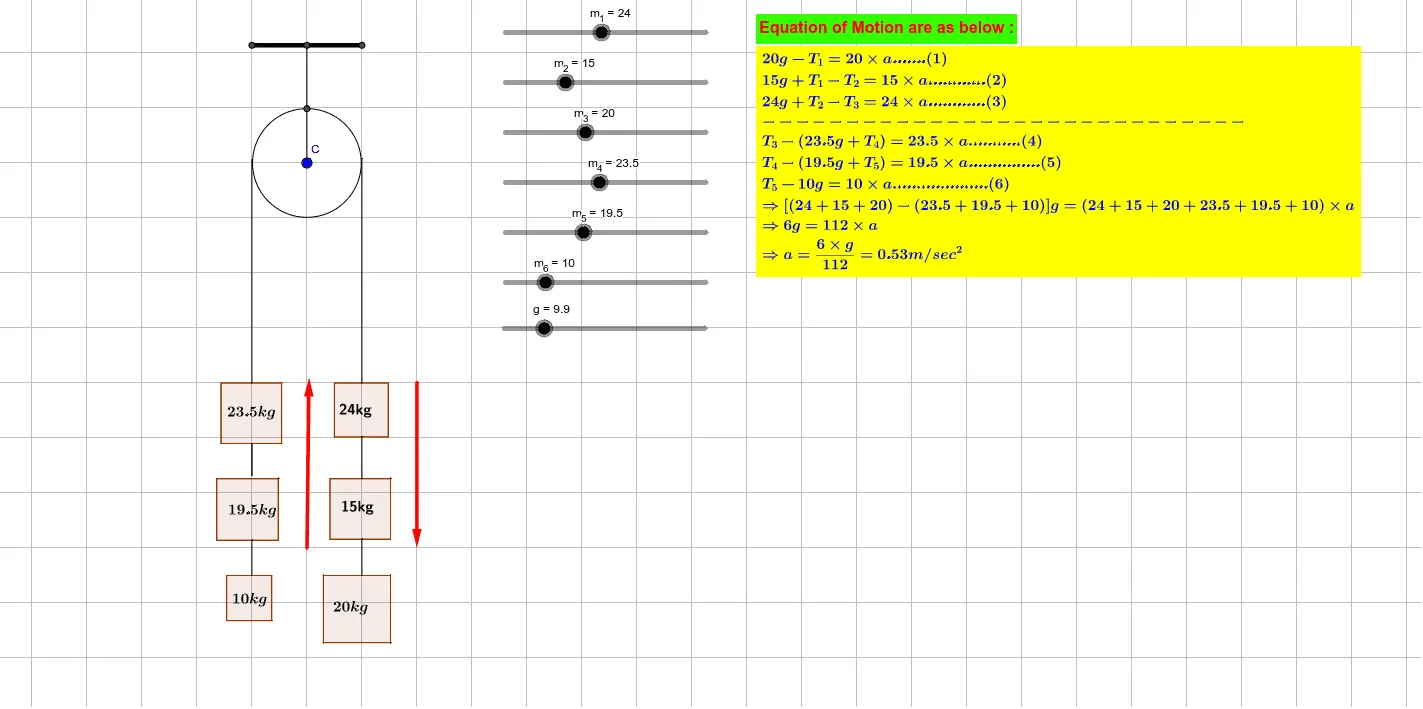
本范例演示了滑轮系统中运动方程的应用。核心数学概念包括运动方程、向量和几何作图。通过使用GeoGebra命令如Point、Vector、Polygon等,构建了滑轮系统的动态模型。适合高中物理和数学教学。
GeoGebra 命令及参数
Point(xAxis) → AOrthogonalLine(A, xAxis) → fPoint(xAxis) → BOrthogonalLine(B, xAxis) → g_3Circle(C, D) → cLine(C, g_3) → hLine(E, xAxis) → iIntersect(c, h) → F, GIntersect(i, h) → HIntersect(i, g_3) → IIntersect(f, i) → JSegment(J, I) → jPoint(f) → KPoint(f) → LLine(K, xAxis) → kLine(M, xAxis) → lIntersect(k, g_3) → NIntersect(l, g_3) → OSegment(C, H) → mPoint(k) → PPoint(k) → QPolygon(Q, P, 4) → poly1, n, p, q, r, R, SPoint(l) → TPoint(l) → UPolygon(U, T, 4) → poly2, s, t, a, b, V, WLine(Z, xAxis) → dIntersect(g_3, d) → A_1Point(d) → B_1Point(d) → C_1Polygon(C_1, B_1, 4) → poly3, e, f_1, g_1, h_1, D_1, E_1Point(d) → F_1Point(d) → G_1Polygon(F_1, G_1, 4) → poly4, i_1, j_1, k_1, l_1, H_1, I_1Point(l) → J_1Point(l) → K_1Polygon(K_1, J_1, 4) → poly5, m_7, n_1, p_1, q_1, L_1, M_1Point(k) → N_1Point(k) → O_1Polygon(N_1, O_1, 4) → poly6, r_1, s_1, t_1, a_1, P_1, Q_1Intersect(c, g_3) → R_1,Point(g_3) → S_1Point(f) → T_1Intersect(q, g_3) → U_1Intersect(g_3, a) → V_1Intersect(f, t_1) → W_1Intersect(f, p_1) → Z_1Intersect(d, i_1) → A_2Intersect(f, d) → B_2Segment(S_1, N) → b_1Segment(T_1, K) → c_1Segment(U_1, O) → d_1Segment(V_1, A_1) → e_1Segment(K, W_1) → f_2Segment(W_1, L) → g_2Segment(Z_1, B_2) → h_2Segment(W_1, L) → i_2PointIn(poly6) → C_2PointIn(poly1) → D_2PointIn(poly2) → E_2PointIn(poly5) → F_2PointIn(poly3) → G_2PointIn(poly4) → H_2Vector(I_2, J_2) → uVector(K_2, L_2) → vVector(M_2, N_2) → wVector(O_2, P_2) → u_1