
Synchronized Induction and Relative Rotation in Dynamic Geometry
Loading the math board and drawing, please wait…
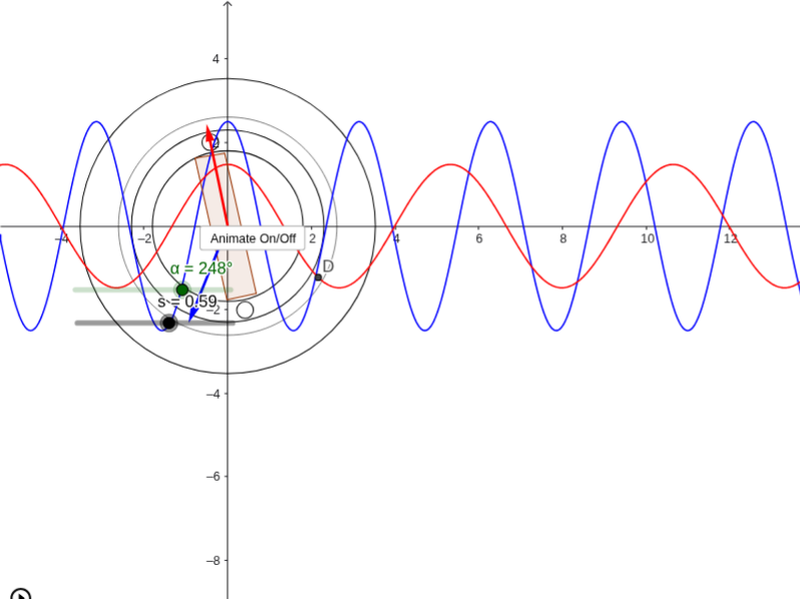
This GeoGebra example demonstrates synchronized relative rotation through dynamic geometric construction, illustrating how points, vectors, circles, and polygons move in coordination under rotation transformations. The core mathematical concepts include 2D rotation (Rotation), vector algebra (Vector), circle and segment geometry (Circle, Segment), angle measurement (Angle), polygon construction (Polygon), and intersection computation (Intersect). The construction employs GeoGebra commands such as Intersect, Point, Vector, Circle, Segment, Rotate, Angle, and Polygon, with objects including G, B, C, u, n, A, v, rot, E, F, H, and others. Animation is controlled via button1 and AnimStatus, while transformed points such as B′, B′₁, B′₂, B′₃ visualize the rotated configurations. This resource is suitable for high school geometry and vector courses, classroom demonstrations, and student-led inquiry into relative motion and transformation geometry.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → BPoint(xAxis) → CVector(B, C) → uCircle(B, 2.4) → rotPoint(rot) → EPoint(rot) → FVector(B, H) → zVector(B, L) → aVector(B, J) → bSegment(J, L) → fSegment(J, G) → eCircle(B, 2.6) → stat2Circle(B, 3.53) → stat1aCircle(B, 2.61) → stat2aRotate(B, 210°, B) → B'Rotate(B, 150°, B) → B'_1Rotate(B, 270°, B) → B'_2Rotate(B, 30°, B) → B'_3Vector((0, 0), (2.5, 0)) → wRotate(w, α, (0, 0)) → w'Rotate(w, (α * (1 - s)), (0, 0)) → w'_1Angle(w'_1, w') → βPolygon(K, M, N, R) → poly1, k, m, n_1, rRotate(K, (α * (1 - s)) + π / 2, (0, 0)) → K'Rotate(M, (α * (1 - s)) + π / 2, (0, 0)) → M'Rotate(N, (α * (1 - s)) + π / 2, (0, 0)) → N'Rotate(R, (α * (1 - s)) + π / 2, (0, 0)) → R'Polygon(K', M', N', R') → poly1', k', m', n', r'Circle((2.05, 0), 0.2) → cRotate(c, (α * (1 - s)), (0, 0)) → c'Rotate(c, (α * (1 - s)) + π, (0, 0)) → c'_1Circle((0, 0), 1.8) → pCircle((0, 0), 2.3) → d
AI Drawing Prompt Reference
Create a dynamic geometry construction demonstrating synchronized relative rotation. Start by establishing a coordinate system with a base vector and several of its rotated versions around the origin, including the measurement of the angle between them. Draw a series of concentric circles centered at the origin as reference paths. Construct a polygon and its corresponding rotated image based on a synchronized transformation parameter. Additionally, place a small circle at a specific offset and rotate it to create two symmetric positions around the origin. The overall visualization should illustrate the coordinated motion of vectors, polygons, and circles under rotation transformations.
The prompt above was compiled from the original drawing commands and is for reference only.