
Exterior Angles of Polygons by Linda Bollman
Loading the math board and drawing, please wait…
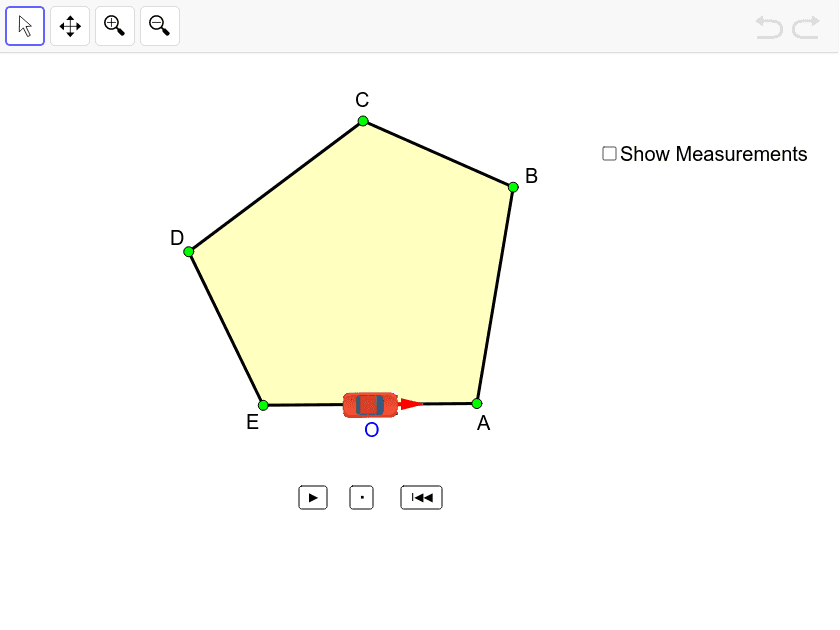
Use the metaphor of a car traveling along the sides of a polygon to help students understand the concept of exterior angles. This example involves key mathematical concepts such as exterior angles, rotation, and vectors. It uses GeoGebra commands like Rotate, Polygon, If, Vector, Angle, OrthogonalLine, Point, Midpoint, Translate, and Segment. Suitable for middle school and above students learning geometry.
GeoGebra Commands & Parameters
Rotate((x(P1) + (x(A) - x(E)) / Distance[E, A], y(P1) + (y(A) - y(E)) / Distance[E, A]), Min[Max[t - 1, 0], 1] * (180° - Angle[B, A, E]), P1) → P1'Rotate((x(P2) + (x(B) - x(A)) / Distance[A, B], y(P2) + (y(B) - y(A)) / Distance[A, B]), Min[Max[t - 3, 0], 1] * (180° - Angle[C, B, A]), P2) → P2'Rotate((x(P3) + (x(C) - x(B)) / Distance[B, C], y(P3) + (y(C) - y(B)) / Distance[B, C]), Min[Max[t - 5, 0], 1] * (180° - Angle[D, C, B]), P3) → P3'Rotate((x(P4) + (x(D) - x(C)) / Distance[C, D], y(P4) + (y(D) - y(C)) / Distance[C, D]), Min[Max[t - 7, 0], 1] * (180° - Angle[E, D, C]), P4) → P4'Rotate((x(P5) + (x(E) - x(D)) / Distance[E, D], y(P5) + (y(E) - y(D)) / Distance[E, D]), Min[Max[t - 9, 0], 1] * (180° - Angle[A, E, D]), P5) → P5'Polygon(E, A, B, C, D) → poly1, a_1, b_1, c_1, d_1, e_1If(t ≤ 2, P1, If[t ≤ 4, P2, If[t ≤ 6, P3, If[t ≤ 8, P4, If[t ≤ 10, P5, P6]]]]) → PIf(t ≤ 2, P1', If[t ≤ 4, P2', If[t ≤ 6, P3', If[t ≤ 8, P4', If[t ≤ 10, P5', P6']]]]) → P'Vector(P, P') → uAngle(P1', P1, (x(P1) + (x(A) - x(E)) / Distance[E, A], y(P1) + (y(A) - y(E)) / Distance[E, A])) → αAngle(P2', P2, (x(P2) + (x(B) - x(A)) / Distance[A, B], y(P2) + (y(B) - y(A)) / Distance[A, B])) → βAngle(P3', P3, (x(P3) + (x(C) - x(B)) / Distance[B, C], y(P3) + (y(C) - y(B)) / Distance[B, C])) → γAngle(P4', P4, (x(P4) + (x(D) - x(C)) / Distance[C, D], y(P4) + (y(D) - y(C)) / Distance[C, D])) → δAngle(P5', P5, (x(P5) + (x(E) - x(D)) / Distance[E, D], y(P5) + (y(E) - y(D)) / Distance[E, D])) → εOrthogonalLine(P, u) → fPoint(f) → FMidpoint(F, P') → GVector(G, P) → vTranslate(P, v) → P'_1Translate(P', v) → P''Segment(A, (x(A) + (x(A) - x(E)) / Distance[E, A], y(A) + (y(A) - y(E)) / Distance[E, A])) → gSegment(B, (x(B) + (x(B) - x(A)) / Distance[A, B], y(B) + (y(B) - y(A)) / Distance[A, B])) → hSegment(C, (x(C) + (x(C) - x(B)) / Distance[B, C], y(C) + (y(C) - y(B)) / Distance[B, C])) → iSegment(D, (x(D) + (x(D) - x(C)) / Distance[C, D], y(D) + (y(D) - y(C)) / Distance[C, D])) → jSegment(E, (x(E) + (x(E) - x(D)) / Distance[D, E], y(E) + (y(E) - y(D)) / Distance[D, E])) → kMidpoint(a_1) → OAngle((x(A) + (x(A) - x(E)) / Distance[E, A], y(A) + (y(A) - y(E)) / Distance[E, A]), A, B) → aAngle((x(B) + (x(B) - x(A)) / Distance[A, B], y(B) + (y(B) - y(A)) / Distance[A, B]), B, C) → bAngle((x(C) + (x(C) - x(B)) / Distance[B, C], y(C) + (y(C) - y(B)) / Distance[B, C]), C, D) → cAngle((x(D) + (x(D) - x(C)) / Distance[C, D], y(D) + (y(D) - y(C)) / Distance[C, D]), D, E) → dAngle((x(E) + (x(E) - x(D)) / Distance[D, E], y(E) + (y(E) - y(D)) / Distance[D, E]), E, A) → eIf((t ≥ 1) ∧ (t < 2), α, If[t ≥ 2, a, 0*°]) → α'If((t ≥ 3) ∧ (t < 4), β, If[t ≥ 4, b, 0*°]) → β'If((t ≥ 5) ∧ (t < 6), γ, If[t ≥ 6, c, 0*°]) → γ'If((t ≥ 7) ∧ (t < 8), δ, If[t ≥ 7, d, 0*°]) → δ'If((t ≥ 9) ∧ (t < 10), ε, If[t ≥ 9, e, 0*°]) → ε'