
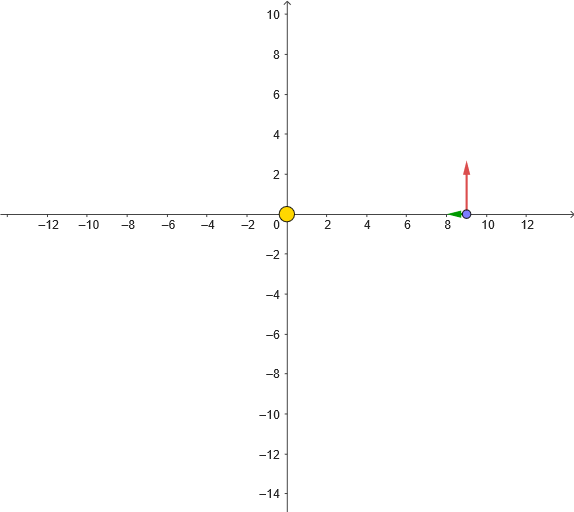
Elliptical Orbit: Demonstrating Motion and Parameter Changes
Loading the math board and drawing, please wait…
In collections
The Domain of the Time (intuitive kinematics)
This example illustrates the motion of an object along an elliptical path, involving concepts of ellipse geometry, parametric equations, and locus. The construction uses GeoGebra commands such as If, mean, Distance, and PolyLine, with objects like reg, regDif, anima, and reinicia. Suitable for high school students learning geometric transformations and parametric analysis, also useful for physics simulation teaching.
GeoGebra Commands & Parameters
If(Length[reg] ≟ 1, {reg(1)}, Sequence[reg(k) - reg(k + 1), k, 1, Length[reg] - 1]) → regDifmean(regDif) → TDistance(M, S) → dPolyLine(regM) → pol
AI Drawing Prompt Reference
Create a motion demonstration along an elliptical path by generating a sequence of points that changes with a parameter, then connect them with a polyline to form the trajectory. Compute an adjustment quantity from differences between consecutive parameter positions, take the mean to obtain a key parameter T, and measure the distance d between two points M and S. Finally, build the orbit using the parameter-driven point sequence, producing a connected curve (polyline) that illustrates motion on the ellipse and how parameter changes affect the positions.
The prompt above was compiled from the original drawing commands and is for reference only.