
Cylinder and Cone Volume Comparison by aswenson
Loading the math board and drawing, please wait…
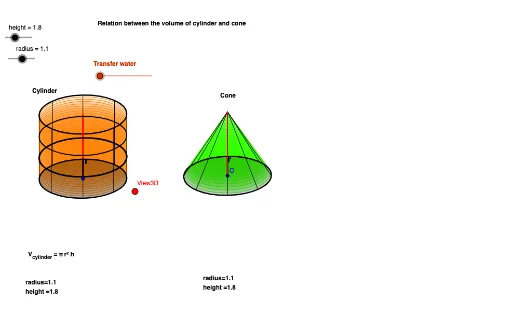
This example dynamically demonstrates the volume calculation process of cylinders and cones, visually comparing their volume relationships. Core math concepts include volume formulas, geometric properties, quadratic functions, and mean value theorems. Construction highlights the use of GeoGebra commands like Vector, Translate, OrthogonalLine, Segment, Mirror, Midpoint, Conic, Line, Intersect, Sequence, and Dilate, along with objects such as B_1, xa, sinphi, cosphi, ya, sintheta, etc. Ideal for high school solid geometry instruction, aiding students in understanding spatial figure volume calculations and property contrasts.
GeoGebra Commands & Parameters
Vector(B_1, Y) → vVector(B_1, X) → wTranslate(O, Vector[(height * w)]) → CVector(B_1, Z) → uTranslate(O, Vector[(radius * u)]) → A_3OrthogonalLine(View3D, yAxis) → a_2OrthogonalLine(View3D, xAxis) → b_2Segment(O, A_3) → dTranslate(O, Vector[(radius * v)]) → BSegment(O, B) → eMirror(B, O) → DMirror(A_3, O) → ESegment(D, O) → h_1Segment(E, O) → iMidpoint(B, A_3) → FMidpoint(B, F) → GMidpoint(O, G) → HMidpoint(H, G) → IMirror(I, G) → JConic(A_3, J, B, E, D) → fSegment(C, A_3) → jSegment(C, B) → lSegment(C, E) → m_2Segment(C, D) → n_2Line(F, O) → pMidpoint(B, E) → KLine(K, O) → qIntersect(f, p) → L, MIntersect(f, q) → N, PSegment(C, N) → rSegment(C, L) → sSegment(C, P) → tSegment(C, M) → a1Segment(C, O) → b1Vector(O, H1) → zTranslate(f, z) → p1Translate(C, z) → I1Vector(H1, I1) → u1Translate(p1, u1) → q1Translate(D, z) → J1Translate(N, z) → K1Translate(A_3, z) → M1Translate(M, z) → N1Translate(L, z) → O1Translate(E, z) → P1Translate(P, z) → Q1Translate(B, z) → R1Translate(J1, u1) → S1Translate(K1, u1) → T1Translate(M1, u1) → U1Translate(N1, u1) → V1Translate(R1, u1) → W1Translate(Q1, u1) → Z1Translate(O1, u1) → A'2Translate(P1, u1) → B2Segment(S1, J1) → l1Segment(T1, K1) → m1Segment(U1, M1) → n1Segment(V1, N1) → r1Segment(W1, R1) → s1Segment(Z1, Q1) → t1Segment(B2, P1) → a2Segment(A'2, O1) → b2Segment(I1, H1) → g2Segment(H1, M1) → h2Sequence(Translate[p1, Vector[(i * u1)]], i, 0, 1, o) → L1Sequence(Dilate[f, i, C], i, 0, 1, o) → L2Midpoint(h2) → J_1Midpoint(d) → L_1Dilate(f, a, C) → f'_2Translate(p1, Vector[(a / 3 * u1)]) → p1'Translate(p1, Vector[(1 / 3 * u1)]) → p1'_1Translate(p1, Vector[(2 / 3 * u1)]) → p1'_2Sequence(Dilate[f, i, C], i, a, 1, o) → liste11Sequence(Translate[p1, Vector[(i * u1)]], i, 0, a / 3, o) → liste1