
Congruent Triangles Shortcuts
Loading the math board and drawing, please wait…
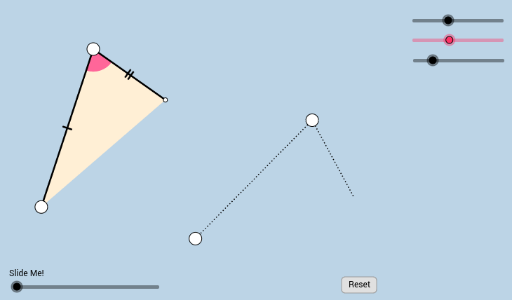
This example demonstrates several methods to prove congruence of triangles. Key mathematical concepts include the properties and theorems of congruent triangles. Using GeoGebra commands such as Circle, Point, Segment, Rotate, etc., it visually illustrates angles, sides, and transformations. Suitable for middle and high school students learning geometric proofs.
GeoGebra Commands & Parameters
Circle(A, a) → cPoint(c) → BSegment(A, B) → fCircle(A, b) → dRotate(B, α, A) → B'Angle(B, A, B') → βRay(A, B') → gIntersect(d, g, 1) → CSegment(B, C) → hSegment(A, C) → iMin(f, i) → eCircle(A, (0.25 * e)) → kIntersect(k, f) → D,Intersect(k, i) → E,Polygon(A, B, C) → poly1, c_1, a_1, b_1CircleSector(A, D, E) → pMirror(A, h) → A'Mirror(B, h) → B'_1Mirror(C, h) → C'Polygon(A', B'_1, C') → poly1', c', a', b'_1Mirror(p, h) → p'Mirror(A, h) → A'_1Mirror(B, h) → B'_2Segment(A'_1, B'_2) → f'Mirror(A, h) → A'_2Mirror(C, h) → C'_1Segment(A'_2, C'_1) → i'Line(C, B) → jPoint(j) → GPoint(j) → HRay(B, H) → lRay(C, G) → mCircle(F, a) → qPoint(q) → ISegment(F, I) → nRotate(I, α, F) → I'Angle(I, F, I') → γCircle(F, b) → rRay(F, I') → sIntersect(r, s, 1) → JSegment(I, J) → tSegment(F, J) → f_1Dilate(B, If[0 < u ≤ 1, 1 - u, 0], I) → B'_3Vector(B, B'_3) → vTranslate(A, v) → A'_3Translate(B, v) → B'_4Segment(A'_3, B'_4) → f'_1Line(B, n) → g_1Point(g_1) → KAngle(K, B, A) → δRotate(A'_3, If[1 < u ≤ 2, ((-(u - 1)) * δ), (-δ)], I) → LRotate(B'_4, If[1 < u ≤ 2, ((-(u - 1)) * δ), (-δ)], I) → MSegment(L, M) → h_1Dilate(A, If[2 < u ≤ 3, 3 - u, 0], F) → A'_4Vector(A, A'_4) → wTranslate(A, w) → A'_5Translate(C, w) → C'_2Segment(A'_5, C'_2) → i'_1Line(A, f_1) → i_1Point(i_1) → NAngle(N, A, C) → εRotate(A'_5, If[3 < u ≤ 4, ((-(u - 3)) * ε), (-ε)], F) → ORotate(C'_2, If[3 < u ≤ 4, ((-(u - 3)) * ε), (-ε)], F) → PSegment(O, P) → j_1Translate(p, w) → p'_1Rotate(p'_1, If[3 < u ≤ 4, ((-(u - 3)) * ε), (-ε)], F) → d_1Dilate(B, If[4 < u ≤ 5, 5 - u, 0], I) → B'_5Vector(B, B'_5) → u_1Translate(A, u_1) → A'_6Translate(B, u_1) → B'_6Translate(C, u_1) → C'_3Polygon(A'_6, B'_6, C'_3) → poly1'_1, c'_3, a'_6, b'_6Line(B, t) → k_1Point(k_1) → QAngle(Q, B, C) → ζRotate(A'_6, If[5 < u ≤ 6, ((-(u - 5)) * ε), (-ε)], I) → RRotate(B'_6, If[5 < u ≤ 6, ((-(u - 5)) * ε), (-ε)], I) → SRotate(C'_3, If[5 < u ≤ 6, ((-(u - 5)) * ε), (-ε)], I) → TPolygon(R, S, T) → poly2, t_1, r_1, s_1Segment(B, A) → l_1Segment(A, C) → m_1Segment(C, B) → n_1CircleSector(A, D, E) → e_1