
B-Field Distributions and Flux Plots
Loading the math board and drawing, please wait…
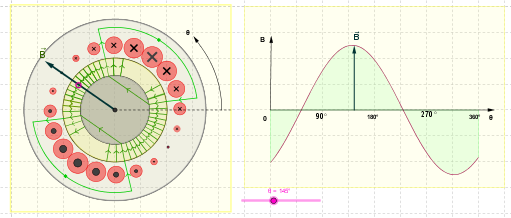
This example demonstrates B-field distributions and flux plots. Core mathematical concepts include vectors, functions, and integrals. Using GeoGebra commands such as Circle, Integral, Point, etc., the B-field distribution and flux plots are constructed. Suitable for university physics and mathematics courses.
GeoGebra Commands & Parameters
Circle((0, 0), 2) → c2Integral(f1, 6, 14) → uPoint(f1) → BCircleArc(A, B, C) → cPoint(c) → DVector(D, E) → vPoint(f1) → FVector(F, G) → wVector(Q, T) → aPoint(f1) → HPoint(f1) → ICircle((0, 0), 2.01) → c31Circle((0, 0), 1.84) → c22Function(f1, 6, 14) → fCircle((0, 0), 1.7) → c4Point(c4) → KRotate(K, θ) → WSegment(A, J) → dAngle(J, A, W) → qqRotate(Circle[P1, (0.4 * sin((3 * β)))], (3 * β) + θ) → s3Rotate(Circle[P1, (0.4 * sin((2 * β)))], (2 * β) + θ) → s2Rotate(Circle[P1, (0.4 * sin((4 * β)))], (4 * β) + θ) → s4Rotate(Circle[P1, (0.4 * sin((5 * β)))], (5 * β) + θ) → s5Rotate(Circle[P1, (0.4 * sin((6 * β)))], (6 * β) + θ) → s6Rotate(Circle[P1, (0.4 * sin((7 * β)))], (7 * β) + θ) → s7Rotate(Circle[P1, (0.4 * sin((8 * β)))], (8 * β) + θ) → s8Rotate(Circle[P1, (0.4 * sin((9 * β)))], (9 * β) + θ) → s9Rotate(Circle[P1, (0.4 * sin(β))], β + θ) → s1Rotate(N1, β + θ) → N2Rotate(N1, (2 * β) + θ) → N3Rotate(N1, (3 * β) + θ) → N4Rotate(N1, (4 * β) + θ) → N5Rotate(N1, (-β) + θ) → N_2Rotate(N1, θ) → N11Rotate(N1, (-2 * β) + θ) → N_3Rotate(N1, (-3 * β) + θ) → N_4Rotate(N1, (-4 * β) + θ) → N_5Rotate(Circle[P1, (0.4 * sin((10 * β)))], (10 * β) + θ) → s10Rotate(Circle[P1, 0], 0 + θ) → s0Rotate(Circle[P1, ((-0.4) * sin((11 * β)))], (11 * β) + θ) → s11Rotate(Circle[P1, ((-0.4) * sin((12 * β)))], (12 * β) + θ) → s12Rotate(Circle[P1, ((-0.4) * sin((13 * β)))], (13 * β) + θ) → s13Rotate(Circle[P1, ((-0.4) * sin((14 * β)))], (14 * β) + θ) → s14Rotate(Circle[P1, ((-0.4) * sin((15 * β)))], (15 * β) + θ) → s15Rotate(Circle[P1, ((-0.4) * sin((16 * β)))], (16 * β) + θ) → s16Rotate(Circle[P1, ((-0.4) * sin((17 * β)))], (17 * β) + θ) → s17Rotate(Circle[P1, ((-0.4) * sin((18 * β)))], (18 * β) + θ) → s18Rotate(Circle[P1, ((-0.4) * sin((19 * β)))], (19 * β) + θ) → s19Rotate(S1, β + θ) → S2Rotate(S1, (2 * β) + θ) → S3Rotate(S1, (4 * β) + θ) → S5Rotate(S1, (-β) + θ) → S_2Rotate(S1, (-2 * β) + θ) → S_3Rotate(S1, (-3 * β) + θ) → S_4Rotate(S1, (-4 * β) + θ) → S_5Rotate(S1, (3 * β) + θ) → S4Rotate(S1, θ) → S11Rotate(V1, θ) → VVector(V) → bCircle((0, 0), 1.33) → c32Circle((0, 0), 1.3) → c3Circle((0, 0), 3.51) → c11Circle((0, 0), 3.5) → c1Point(d) → LPoint(d) → MSegment(L, M) → eSequence(Segment[Rotate[L, (-asin(1 - k / j))], Rotate[M, (-asin(1 - k / j))]], k, 1, j) → z2Sequence(Segment[Rotate[L, acos(1 - k / j) + 3.141592653589793 / 2], Rotate[M, acos(1 - k / j) + 3.141592653589793 / 2]], k, 1, j) → z3Sequence(Segment[Rotate[L, asin(1 - k / j)], Rotate[M, asin(1 - k / j)]], k, 1, j) → z1Rotate((1.0791742935578592, 0.7750466243220067), θ) → NRotate((1.6244657241348275, 1.1666666666666665), θ) → OElement(z1, 6) → qq6Rotate((1.2177290821973479, 0.5314605423922333), θ) → PRotate((1.833030277982336, 0.8), θ) → SSegment(Rotate[(1.2177290821973479, 0.5314605423922333), θ], Rotate[(1.833030277982336, 0.8), θ]) → q6Rotate((1.2674526134856594, 0.398595406794175), θ) → URotate((1.9078784028338913, 0.6000000000000001), θ) → ZSequence(Segment[Rotate[L, (-acos(1 - k / j)) - 3.141592653589793 / 2], Rotate[M, (-acos(1 - k / j)) - 3.141592653589793 / 2]], k, 1, j) → z4Element(z1, 7) → qq7Segment(Rotate[(1.2674526134856594, 0.398595406794175), θ], Rotate[(1.9078784028338913, 0.6000000000000001), θ]) → q7Element(z1, 8) → qq8Rotate((1.3018071472837596, 0.26573027119611653), θ) → A_1Rotate((1.9595917942265424, 0.3999999999999999), θ) → B_1Segment(A_1, B_1) → q8Rotate((1.0629210847844666, 0.7971908135883498), θ) → C_1Rotate((1.6, 1.2), θ) → D_1Segment(C_1, D_1) → q4Element(z1, 3) → qq3Rotate((0.9488468565221743, 0.9300559491864081), θ) → E_1Rotate((1.4282856857085702, 1.4), θ) → F_1Segment(E_1, F_1) → q3Element(z1, 2) → qq2Rotate((0.7971908135883498, 1.0629210847844666), θ) → G_1Rotate((1.2, 1.6), θ) → I_1Segment(G_1, I_1) → q2Element(z1, 1) → qq1Rotate((0.5791456991917646, 1.1957862203825247), θ) → J_1Rotate((0.8717797887081347, 1.8), θ) → K_1Segment(J_1, K_1) → q1Element(z1, 4) → qq4Element(z1, 5) → qq5Segment(Rotate[(1.1506458270518263, 0.6643256779902915), θ], Rotate[(1.7320508075688772, 1), θ]) → q5Element(z1, 9) → qq9Rotate((1.3219914074953556, 0.13286513559805826), θ) → L_1Rotate((1.98997487421324, 0.19999999999999996), θ) → M_1Segment(L_1, M_1) → q9Rotate((0.5791456991917646, -1.1957862203825247), θ) → N_1Rotate((0.8717797887081347, -1.8), θ) → O_1Segment(N_1, O_1) → w1Rotate((0.7971908135883498, -1.0629210847844666), θ) → P_1Rotate((1.2, -1.6), θ) → Q_1Segment(P_1, Q_1) → w2Rotate((0.9488468565221743, -0.9300559491864081), θ) → R_1Rotate((1.4282856857085702, -1.4), θ) → S_1Segment(R_1, S_1) → w3Rotate((1.0629210847844666, -0.7971908135883498), θ) → T_1Rotate((1.6, -1.2), θ) → U_1Segment(T_1, U_1) → w4Rotate((1.1506458270518263, -0.6643256779902915), θ) → V_1Rotate((1.7320508075688772, -1), θ) → W_1Segment(V_1, W_1) → w5Rotate((1.2177290821973479, -0.5314605423922333), θ) → Z_1Rotate((1.833030277982336, -0.8), θ) → A_2Segment(Z_1, A_2) → w6Rotate((1.2674526134856594, -0.398595406794175), θ) → B_2Rotate((1.9078784028338913, -0.6000000000000001), θ) → C_2Segment(B_2, C_2) → w7Rotate((1.3018071472837596, -0.26573027119611653), θ) → D_2Rotate((1.9595917942265424, -0.3999999999999999), θ) → E_2Segment(D_2, E_2) → w8Rotate((1.3219914074953556, -0.13286513559805826), θ) → F_2Rotate((1.98997487421324, -0.19999999999999996), θ) → G_2Segment(F_2, G_2) → w9Rotate((-0.5791456991917645, 1.1957862203825247), θ) → H_2Rotate((-0.8717797887081344, 1.8), θ) → I_2Rotate((-0.7971908135883496, 1.0629210847844666), θ) → J_2Rotate((-1.1999999999999997, 1.6000000000000003), θ) → K_2Rotate((-0.9488468565221743, 0.9300559491864081), θ) → L_2Rotate((-1.4282856857085702, 1.4), θ) → M_2Rotate((-1.0629210847844666, 0.7971908135883498), θ) → O_2Rotate((-1.1506458270518265, 0.6643256779902914), θ) → Q_2Rotate((-1.7320508075688774, 0.9999999999999999), θ) → R_2Rotate((-1.2177290821973479, 0.5314605423922332), θ) → T_2Rotate((-1.833030277982336, 0.7999999999999999), θ) → U_2Rotate((-1.2674526134856592, 0.3985954067941752), θ) → V_2Rotate((-1.907878402833891, 0.6000000000000004), θ) → W_2Rotate((-1.3018071472837596, 0.26573027119611686), θ) → Z_2Rotate((-1.9595917942265424, 0.4000000000000004), θ) → A_3Rotate((-1.3219914074953556, 0.1328651355980584), θ) → B_3Rotate((-1.98997487421324, 0.20000000000000015), θ) → C_3Rotate((0.5791456991917646, -1.1957862203825247), θ) → D_3Rotate((0.8717797887081347, -1.8), θ) → E_3Segment(D_3, E_3) → e1Rotate((0.7971908135883498, -1.0629210847844666), θ) → F_3Rotate((1.2, -1.6), θ) → G_3Segment(F_3, G_3) → e2Rotate((0.9488468565221743, -0.9300559491864081), θ) → H_3Rotate((1.4282856857085702, -1.4), θ) → I_3Segment(H_3, I_3) → e3Rotate((1.0629210847844666, -0.7971908135883498), θ) → J_3Rotate((1.6, -1.2), θ) → K_3Segment(J_3, K_3) → e4Rotate((1.1506458270518263, -0.6643256779902915), θ) → L_3Rotate((1.7320508075688772, -1), θ) → M_3Segment(L_3, M_3) → e5Rotate((1.2177290821973479, -0.5314605423922333), θ) → O_3Rotate((1.833030277982336, -0.8), θ) → P_3Segment(O_3, P_3) → e6Rotate((1.2674526134856594, -0.398595406794175), θ) → Q_3Rotate((1.9078784028338913, -0.6000000000000001), θ) → R_3Segment(Q_3, R_3) → e7Rotate((1.3018071472837596, -0.26573027119611653), θ) → T_3Rotate((1.9595917942265424, -0.3999999999999999), θ) → U_3Segment(T_3, U_3) → e8Rotate((1.3219914074953556, -0.13286513559805826), θ) → V_3Rotate((1.98997487421324, -0.19999999999999996), θ) → W_3Segment(V_3, W_3) → e9Rotate((-0.5791456991917645, -1.1957862203825247), θ) → Z_3Rotate((-0.8717797887081344, -1.8), θ) → A_4Rotate((-0.7971908135883496, -1.0629210847844666), θ) → B_4Rotate((-1.1999999999999997, -1.6000000000000003), θ) → C_4Rotate((-0.9488468565221743, -0.9300559491864081), θ) → D_4Rotate((-1.4282856857085702, -1.4), θ) → E_4Rotate((-1.0629210847844666, -0.7971908135883498), θ) → F_4Rotate((-1.6, -1.2), θ) → G_4Rotate((-1.1506458270518265, -0.6643256779902914), θ) → H_4Rotate((-1.7320508075688774, -0.9999999999999999), θ) → I_4Rotate((-1.2177290821973479, -0.5314605423922332), θ) → J_4Rotate((-1.833030277982336, -0.7999999999999999), θ) → K_4Rotate((-1.2674526134856592, -0.3985954067941752), θ) → L_4Rotate((-1.907878402833891, -0.6000000000000004), θ) → M_4Rotate((-1.3018071472837596, -0.26573027119611686), θ) → O_4Rotate((-1.9595917942265424, -0.4000000000000004), θ) → P_4Rotate((-1.3219914074953556, -0.1328651355980584), θ) → Q_4Rotate((-1.98997487421324, -0.20000000000000015), θ) → R_4Segment(L_2, E_1) → gSegment(D_4, H_3) → hSegment(I_2, H_2) → l1Rotate(L, θ) → L'Rotate(M, θ) → M'Segment(L', M') → u1Segment(R_2, Q_2) → d5Segment(K_2, J_2) → d2Segment(M_2, L_2) → d3Segment(U_2, T_2) → d6Segment(W_2, V_2) → d7Segment(A_3, Z_2) → d8Segment(C_3, B_3) → d9Segment(R_4, Q_4) → g9Segment(P_4, O_4) → g8Segment(M_4, L_4) → g7Segment(K_4, J_4) → g6Segment(I_4, H_4) → g5Segment(G_4, F_4) → g4Segment(E_4, D_4) → g3Segment(C_4, B_4) → g2Segment(A_4, Z_3) → g1Rotate(L9, θ) → L99Rotate(L8, θ) → L88Segment(L88, L99) → iRotate(L7, θ) → L77Point(Circle[L77, O2]) → P_2Segment(L77, P_2) → d11Segment(L77, O_2) → kPoint(w) → T_4Point(xAxis) → U_4Vector(T_4, U_4) → zRotate(L22, θ) → L2Segment(L2, M_2) → lRotate(L11, θ) → L1Segment(F_1, L1) → nPoint(d) → V_4CircleArc(V_4, L1, L2) → pRotate(L33, θ) → L3Segment(L3, E_4) → qRotate(L44, θ) → L4Segment(I_3, L4) → rCircleArc(V_4, L3, L4) → sPoint(p) → W_4Point(s) → W_55Polygon(D_5, E_5, F_5, G_5) → poly2, d_5, e_5, f_5, g_5Polygon(H_5, I_5, J_5, K_5) → poly1, h_5, i_5, j_5, k_5