
旋转圆柱体
几何画板及绘图内容加载中,请稍等……
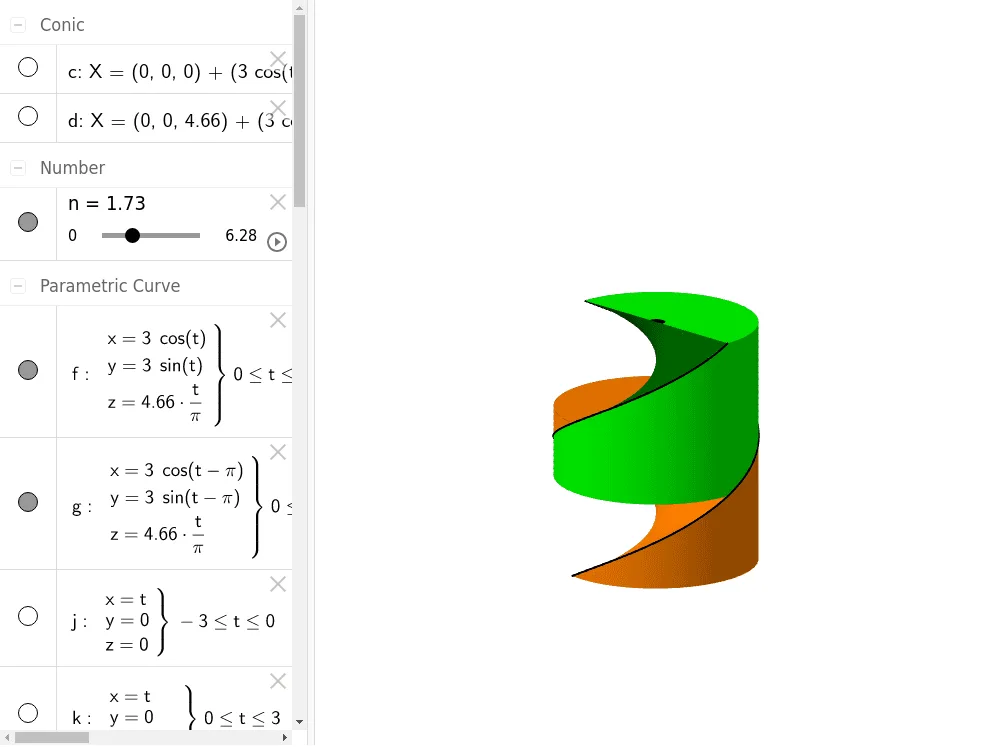
①本范例演示了如何通过旋转二维曲线生成三维圆柱体的过程;②涉及的核心数学概念包括旋转体、参数方程、三维几何;③作图要点——从下方『构造摘要』提炼用到了Intersect(交集)、Point(点)、Circle(圆)、Cylinder(圆柱体)、Surface(曲面)、CurveCartesian(笛卡尔曲线)、Translate(平移)等GeoGebra命令/对象;④适合高中及以上学生学习立体几何和参数方程的应用。
GeoGebra 命令及参数
Intersect(zAxis, xOyPlane) → APoint(zAxis) → BCircle(A, 3, zAxis) → cCylinder(c, z(B)) → a, d, bSurface((u * cos(t)), (u * sin(t)), (z(B) * t / π), t, 0, π, u, -3, 3) → eCurveCartesian((3 * cos(t)), (3 * sin(t)), (z(B) * t / π), t, 0, π) → fCurveCartesian((3 * cos(t - π)), (3 * sin(t - π)), (z(B) * t / π), t, 0, π) → gSurface(f, π, zAxis) → hSurface(g, π, zAxis) → iCurveCartesian(t, 0, z(B), t, 0, 3) → kSurface(k, π, zAxis) → lCurveCartesian(t, 0, 0, t, -3, 0) → jSurface(j, π, zAxis) → mTranslate(Rotate[l, n, zAxis], Vector[(0, 0, (z(B) * n / π))]) → oTranslate(Rotate[i, n, zAxis], Vector[(0, 0, (z(B) * n / π))]) → pTranslate(Rotate[m, n, zAxis], Vector[(0, 0, (z(B) * n / π))]) → qTranslate(Rotate[e, n, zAxis], Vector[(0, 0, (z(B) * n / π))]) → rTranslate(Rotate[f, n, zAxis], Vector[(0, 0, (z(B) * n / π))]) → sTranslate(Rotate[g, n, zAxis], Vector[(0, 0, (z(B) * n / π))]) → tSurface(CurveCartesian[t, 0, z(B), t, -3, 0], π, zAxis) → uSurface(CurveCartesian[t, 0, 0, t, 0, 3], π, zAxis) → v